Chapters
- linuxcncMulti: Multi-Channel Control - Overview
- Multi-Channel Configuration *(new)*
- Multi-Channel G-code Extensions *(new)*
- Siemens Program Language: R Parameters, Expressions, Variables, Jumps *(new)*
- Synchronized Actions *(new)*
- Kinematic Transformations TRAORI, TRANSMIT, TRACYL *(new)*
- mchmi: the Multi-Channel Operator Interface *(new)*
- Machine Builder: Kinematic Models and Configurations *(new)*
- mcplc: HAL Programming in FUP/KOP/SCL *(new)*
- Path Planner: Jerk Limit, Look-ahead and the Planner Benchmark
- mcwatch: Process Monitoring (Tool Break, Overload, Wear) *(new)*
- Example: Deckel FP4 with a Tool Changer Channel *(new)*
- Auto Servo Tuning *(new)*
Screenshots from the simulation
Pictures taken automatically from the sim configurations by the test suite, so they show the current software.
Auto Servo Tuning
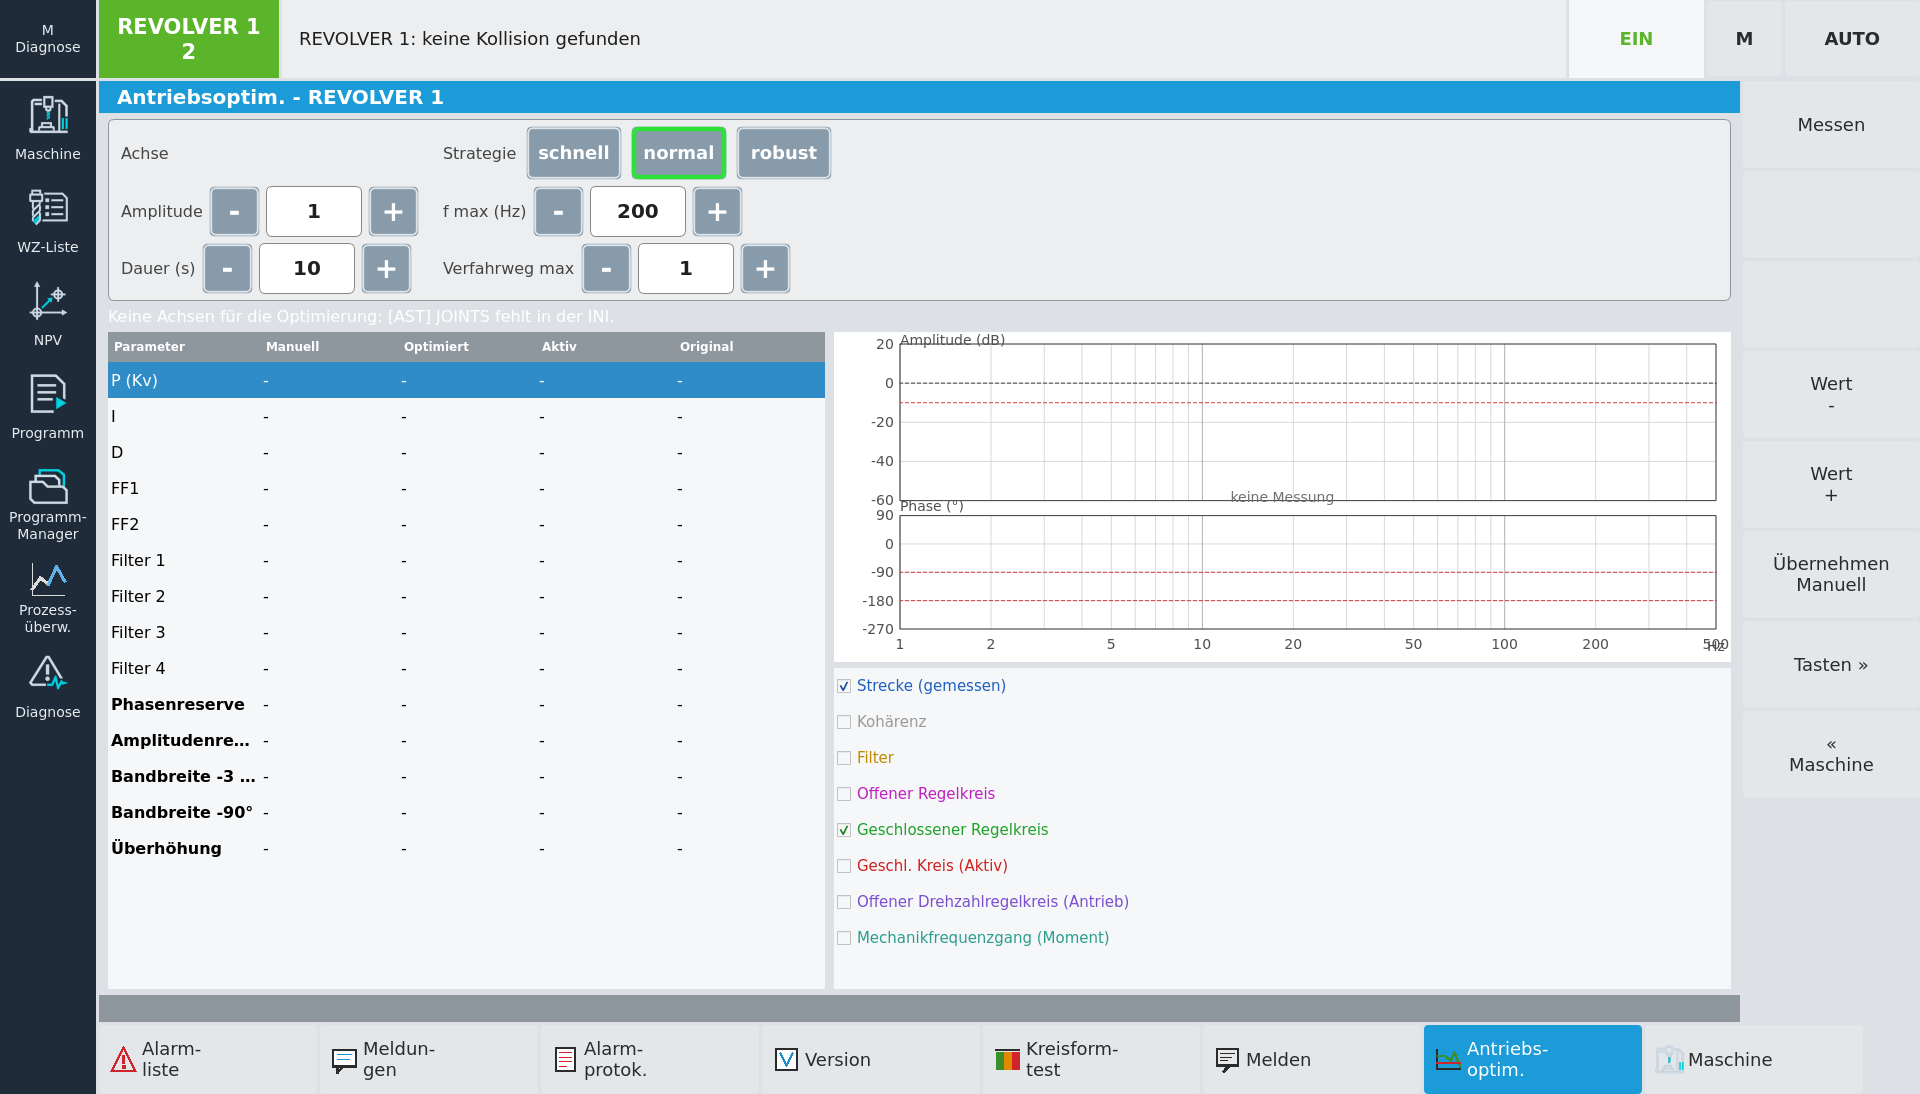
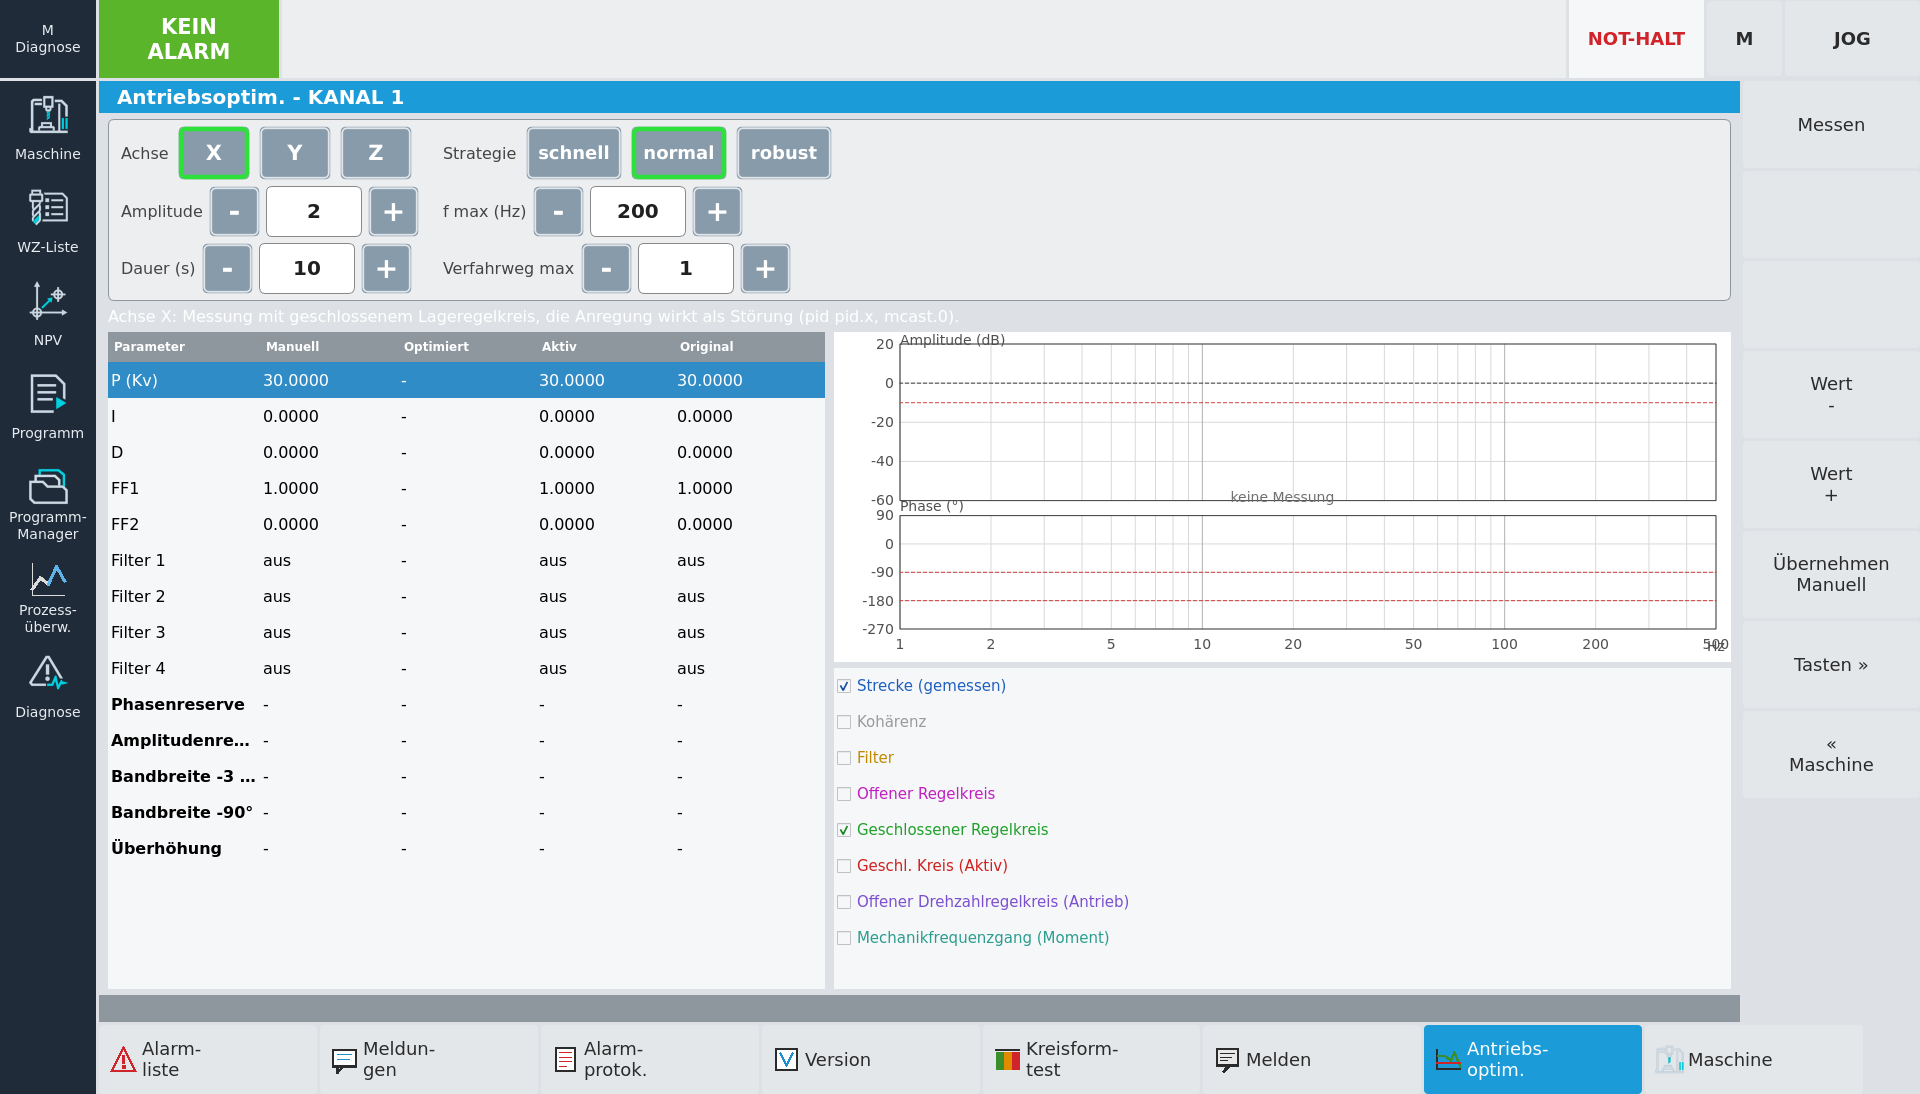 Auto Servo Tuning page
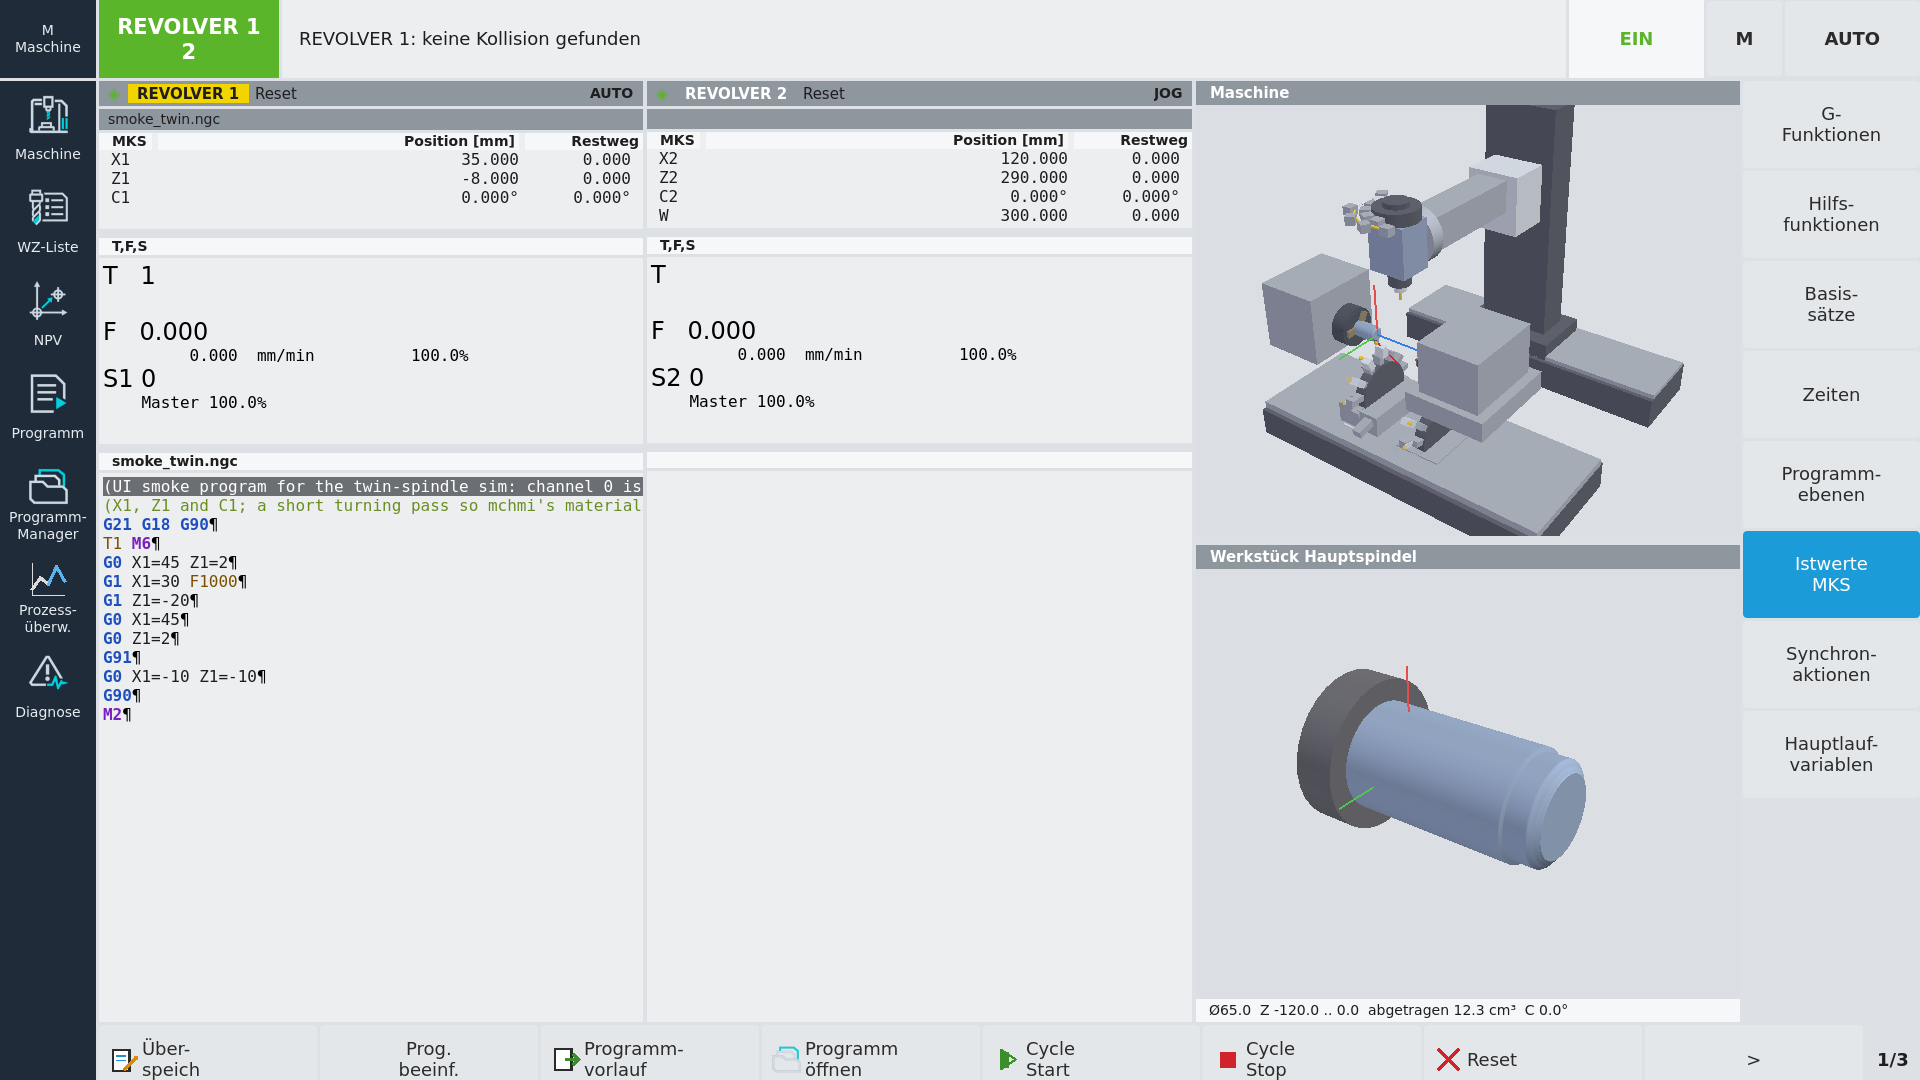
 After the smoke program: the result
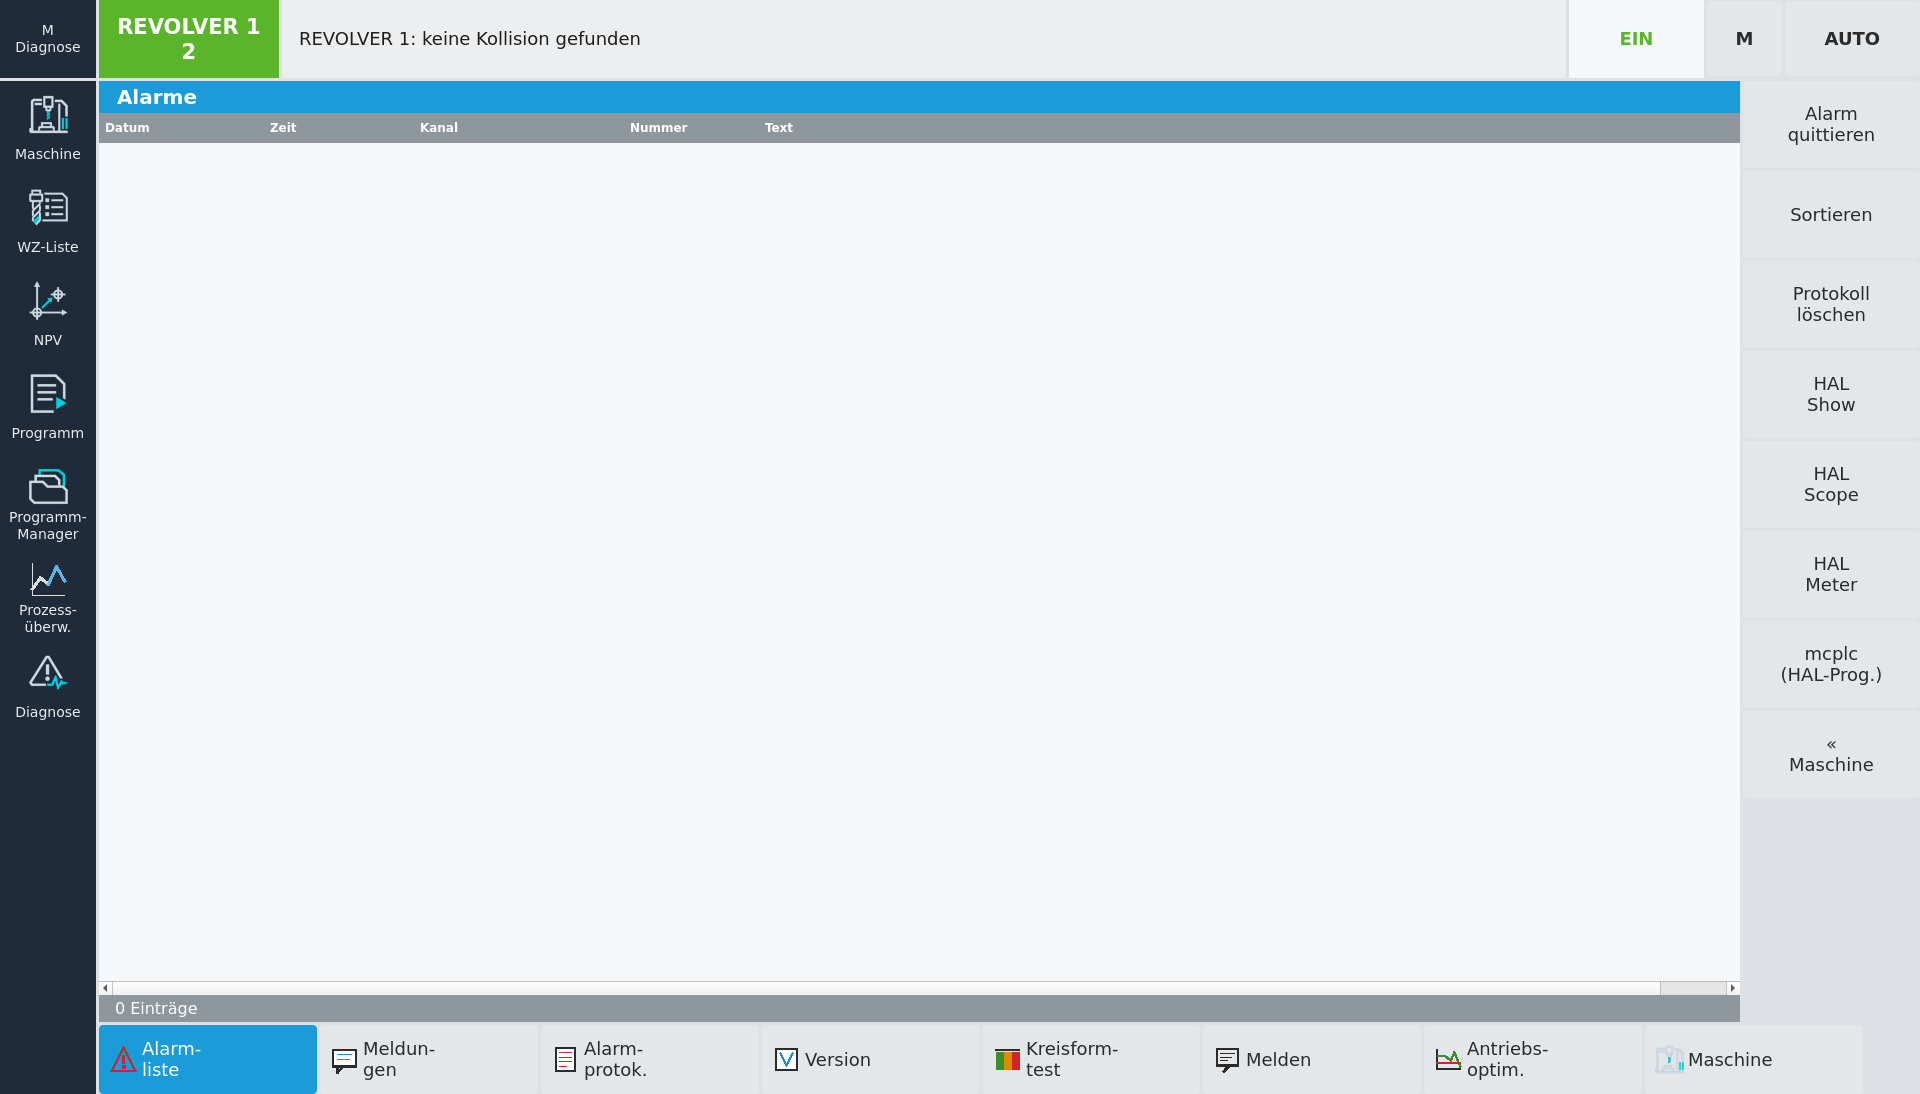
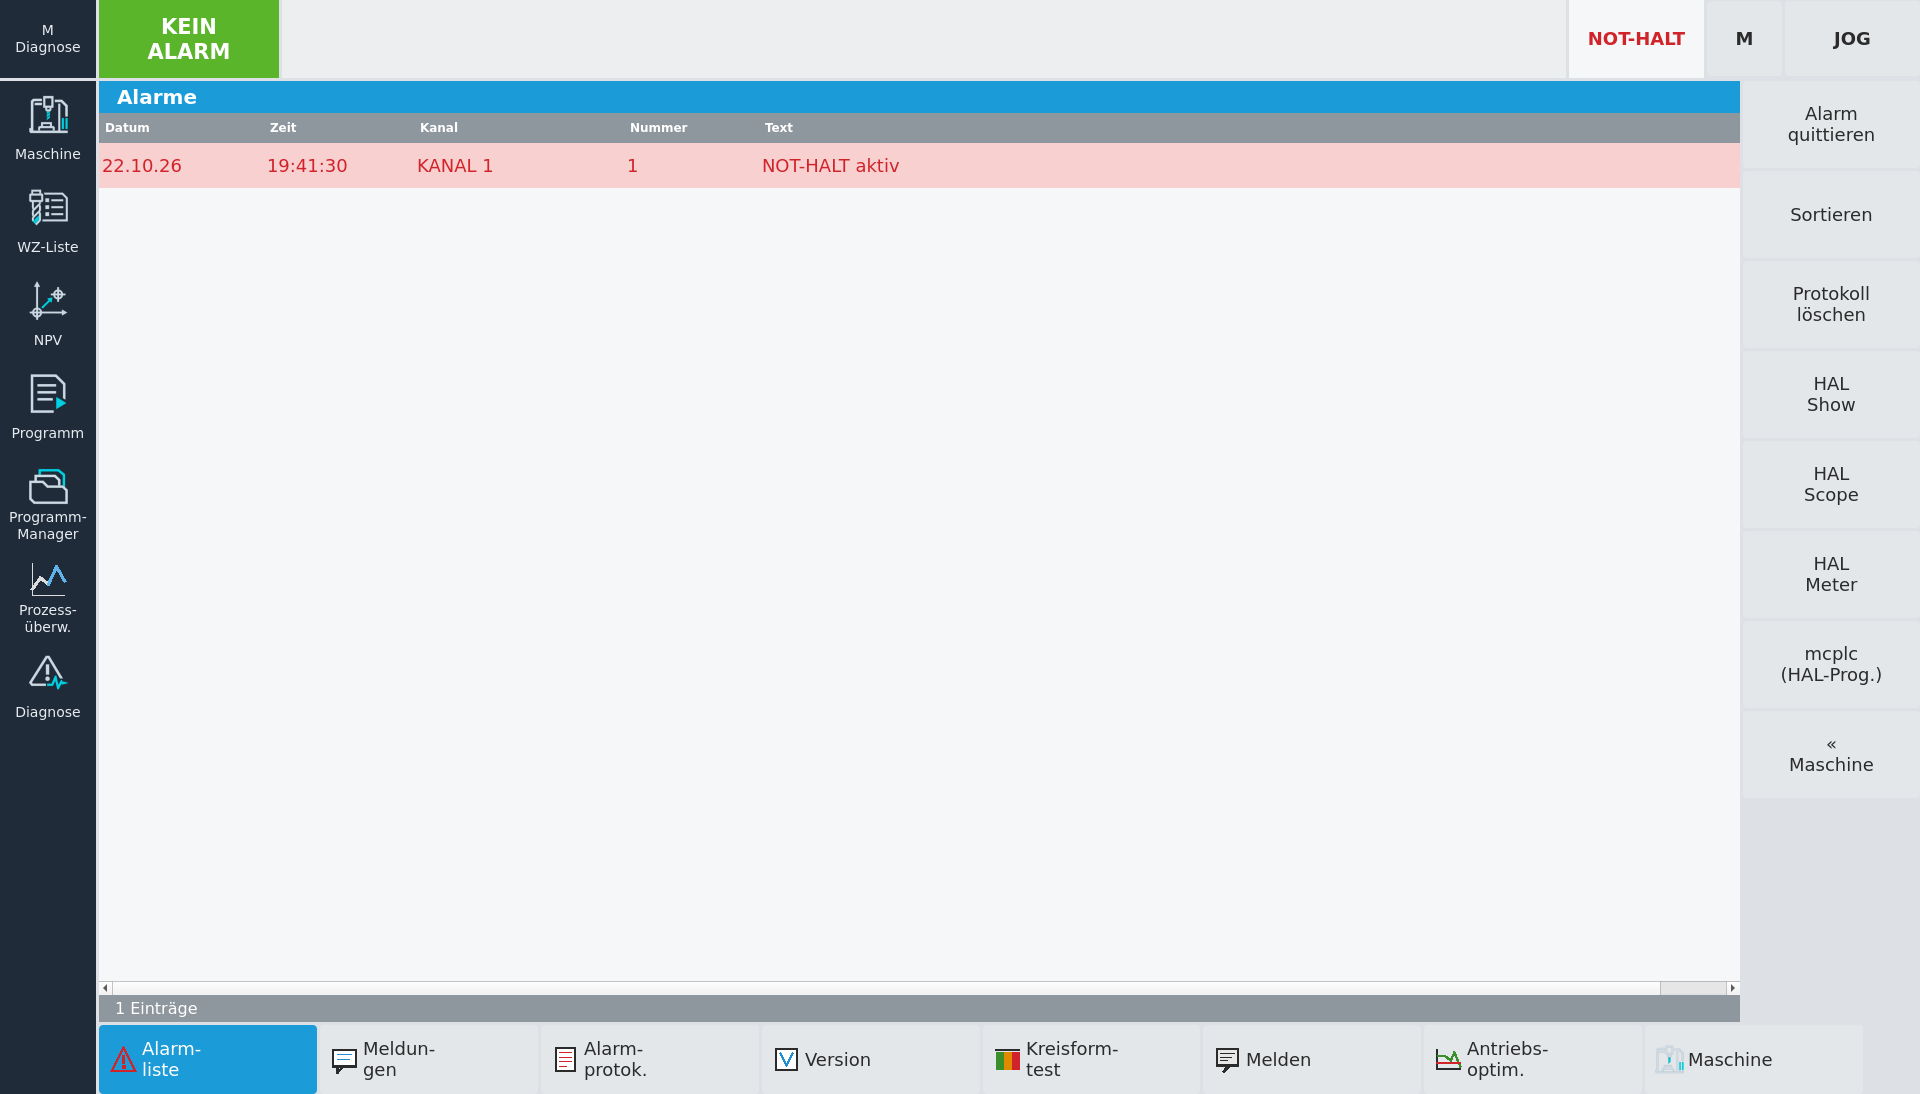 Diagnosis: alarms and log
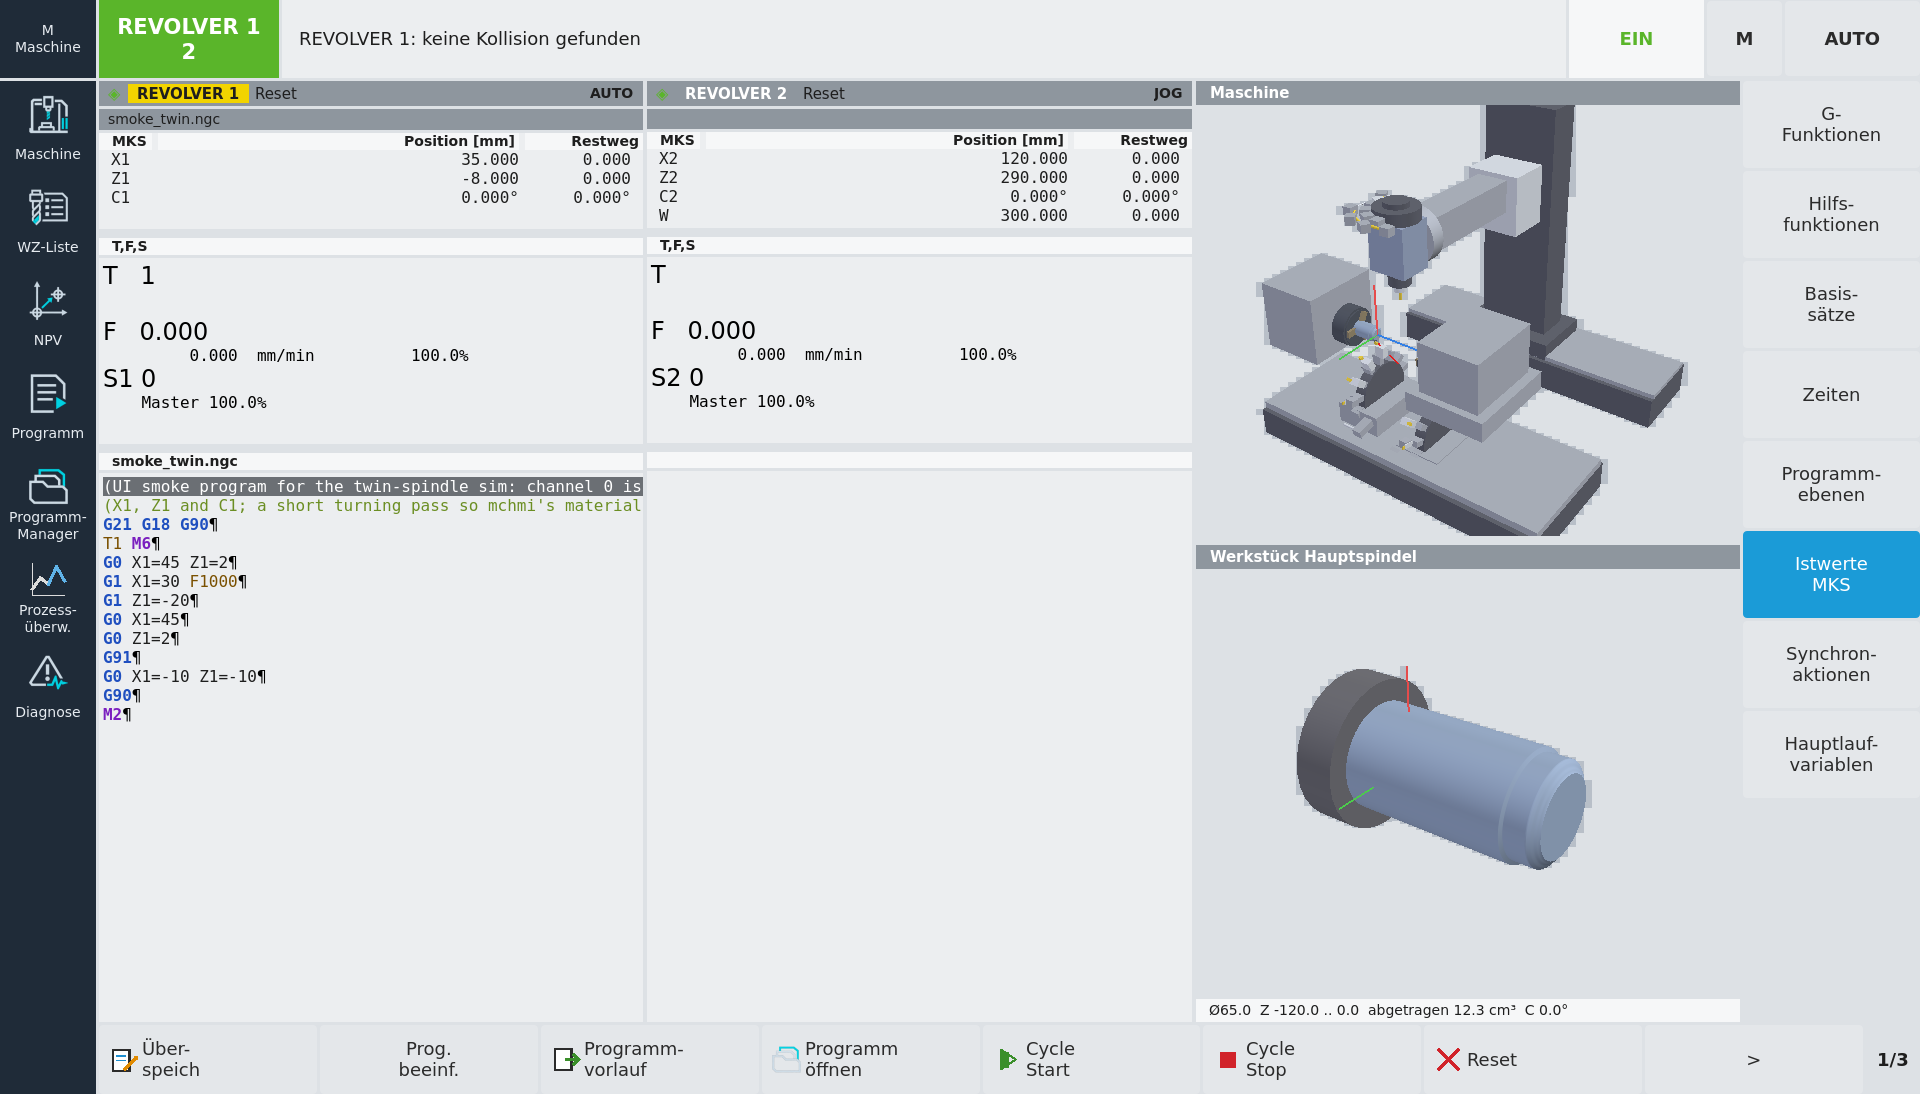
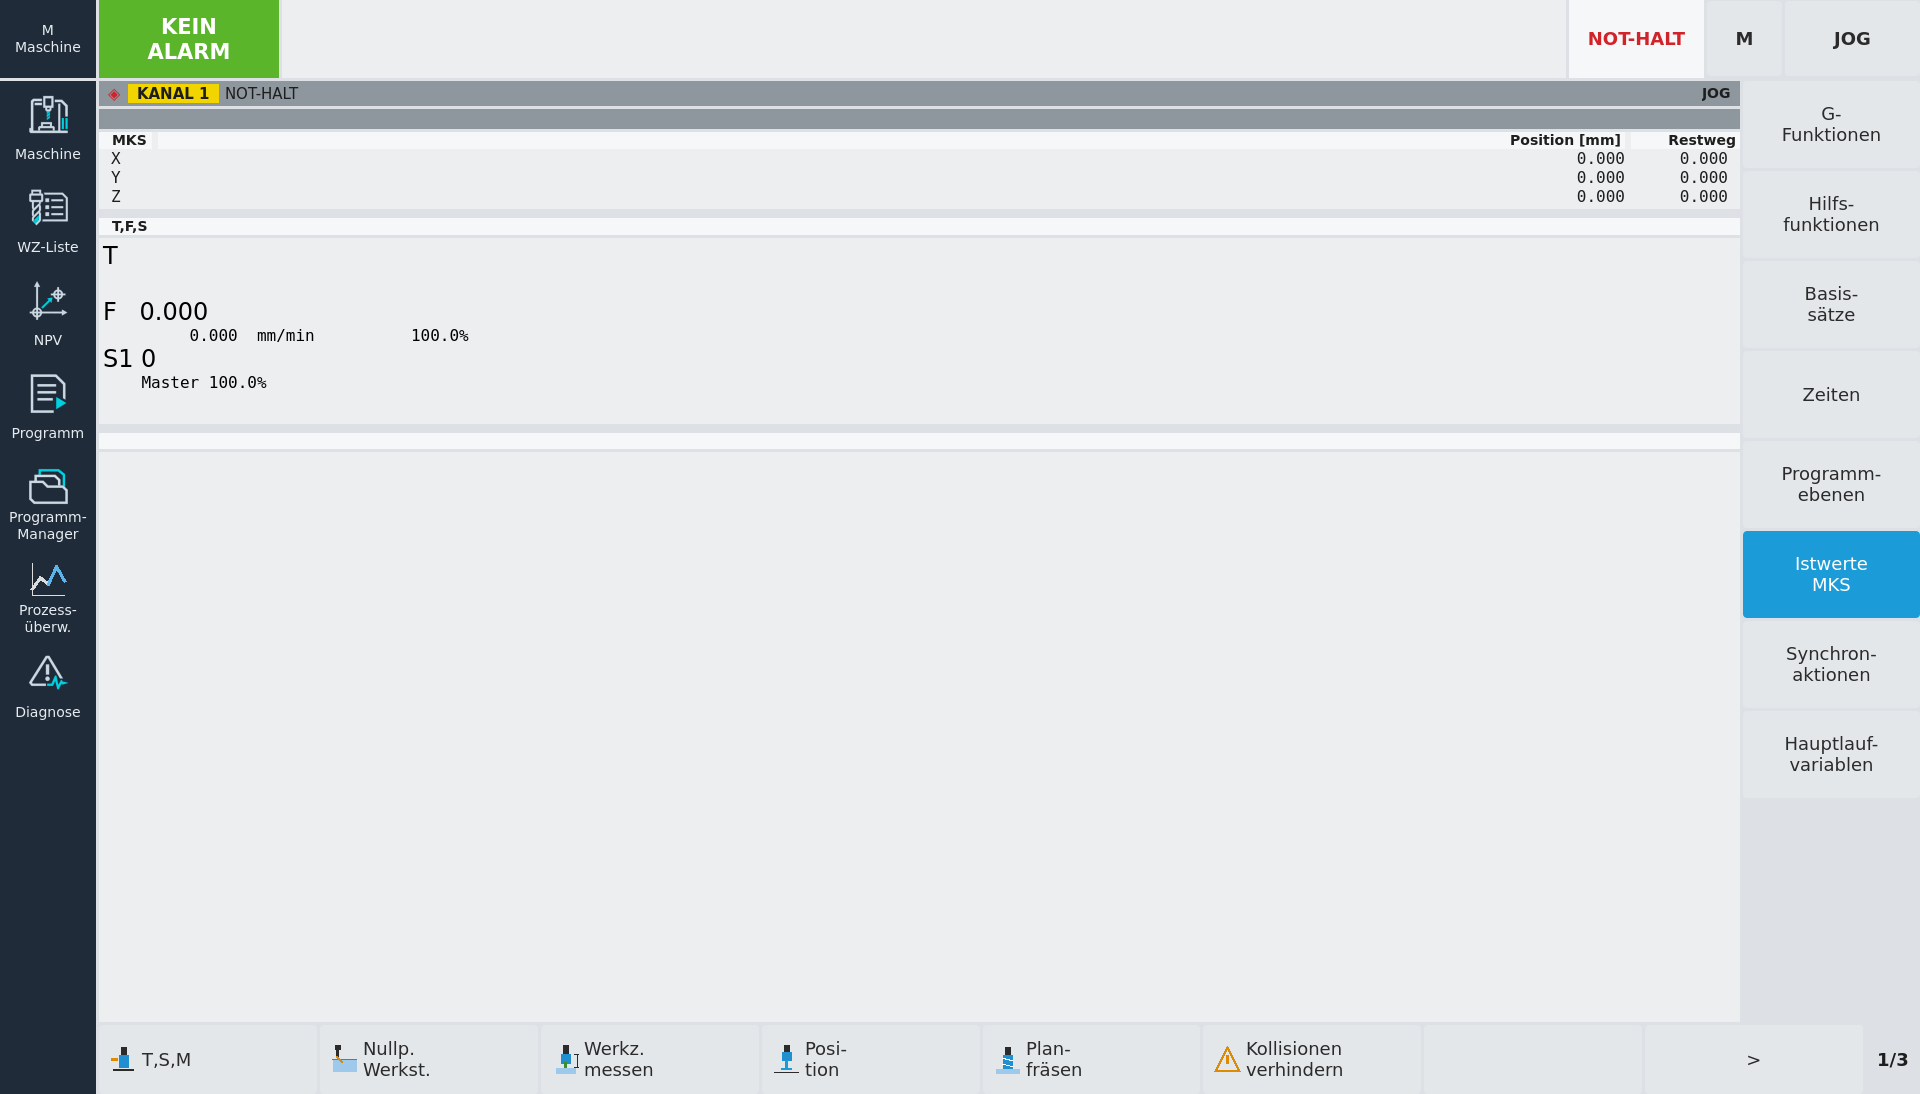 Machine area: channels, positions, program, 3D model
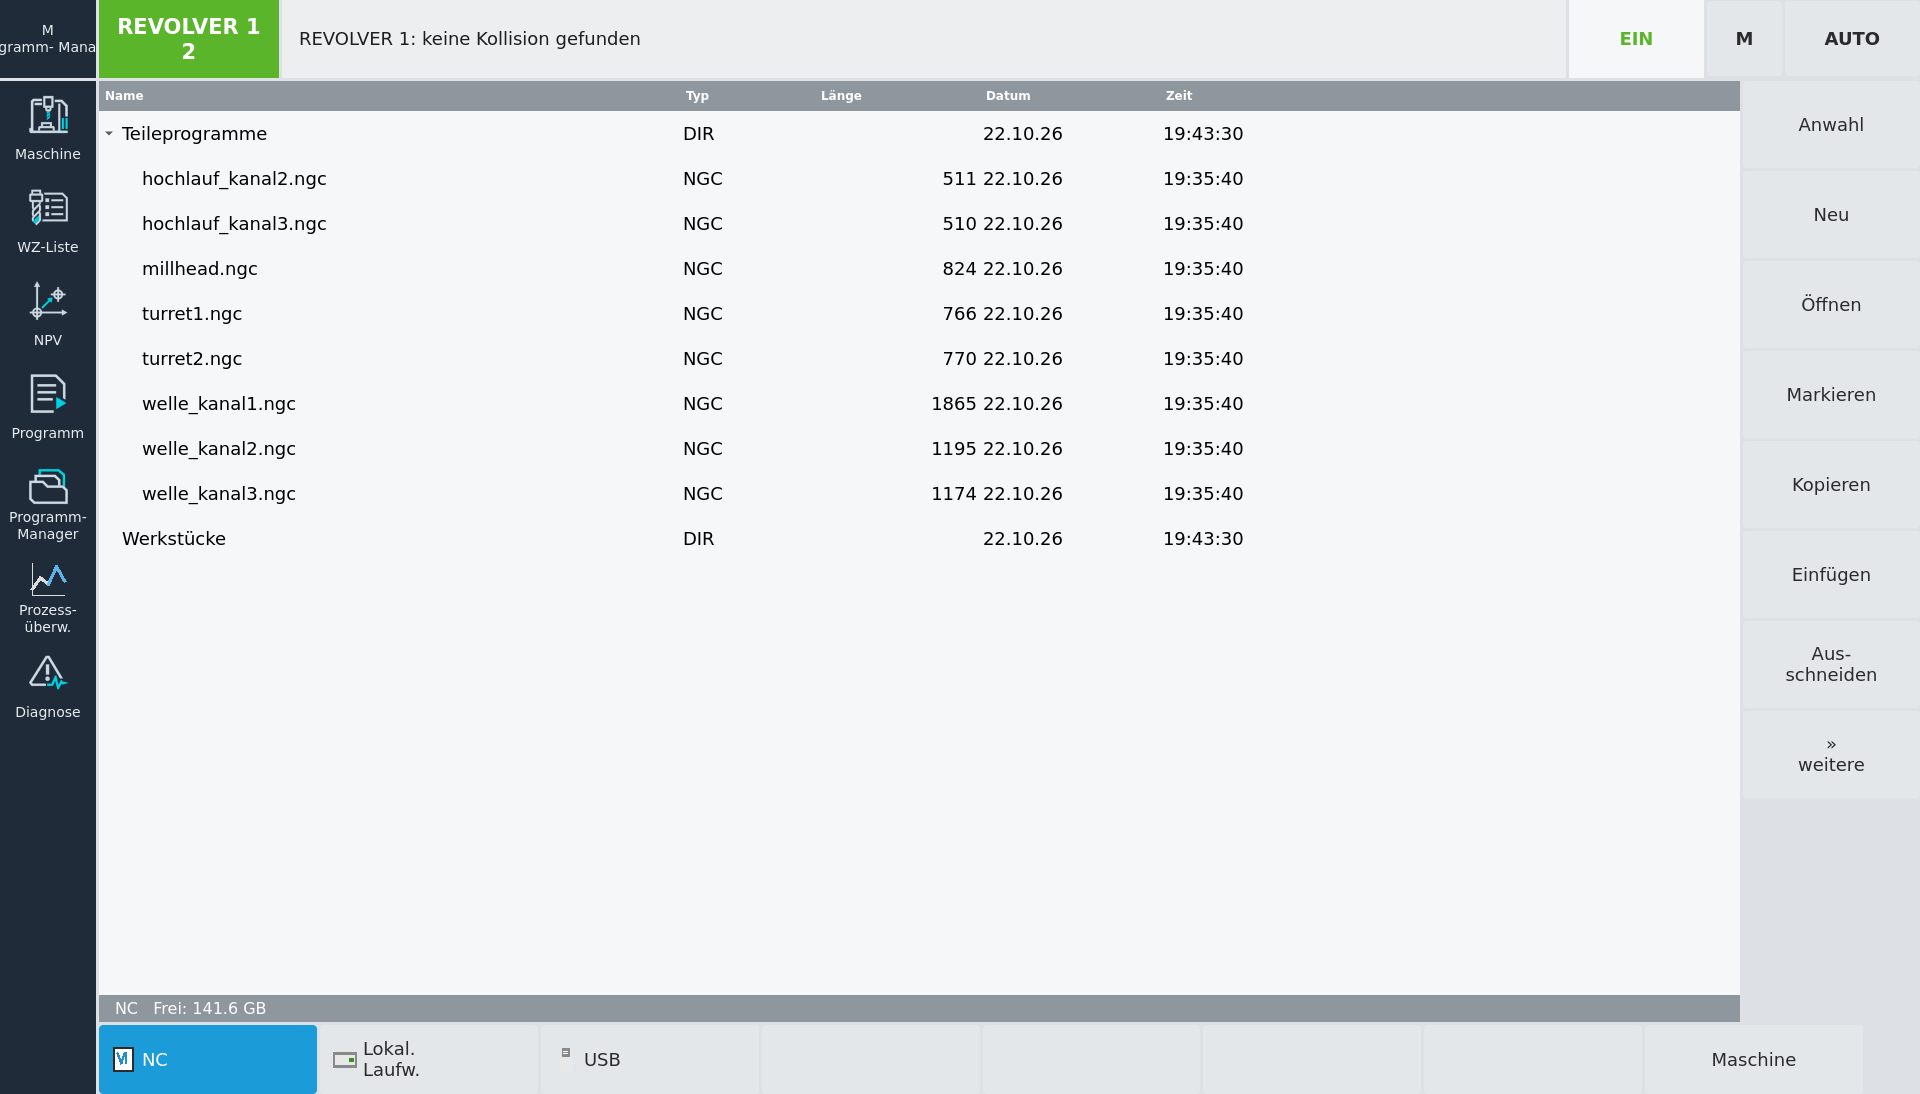
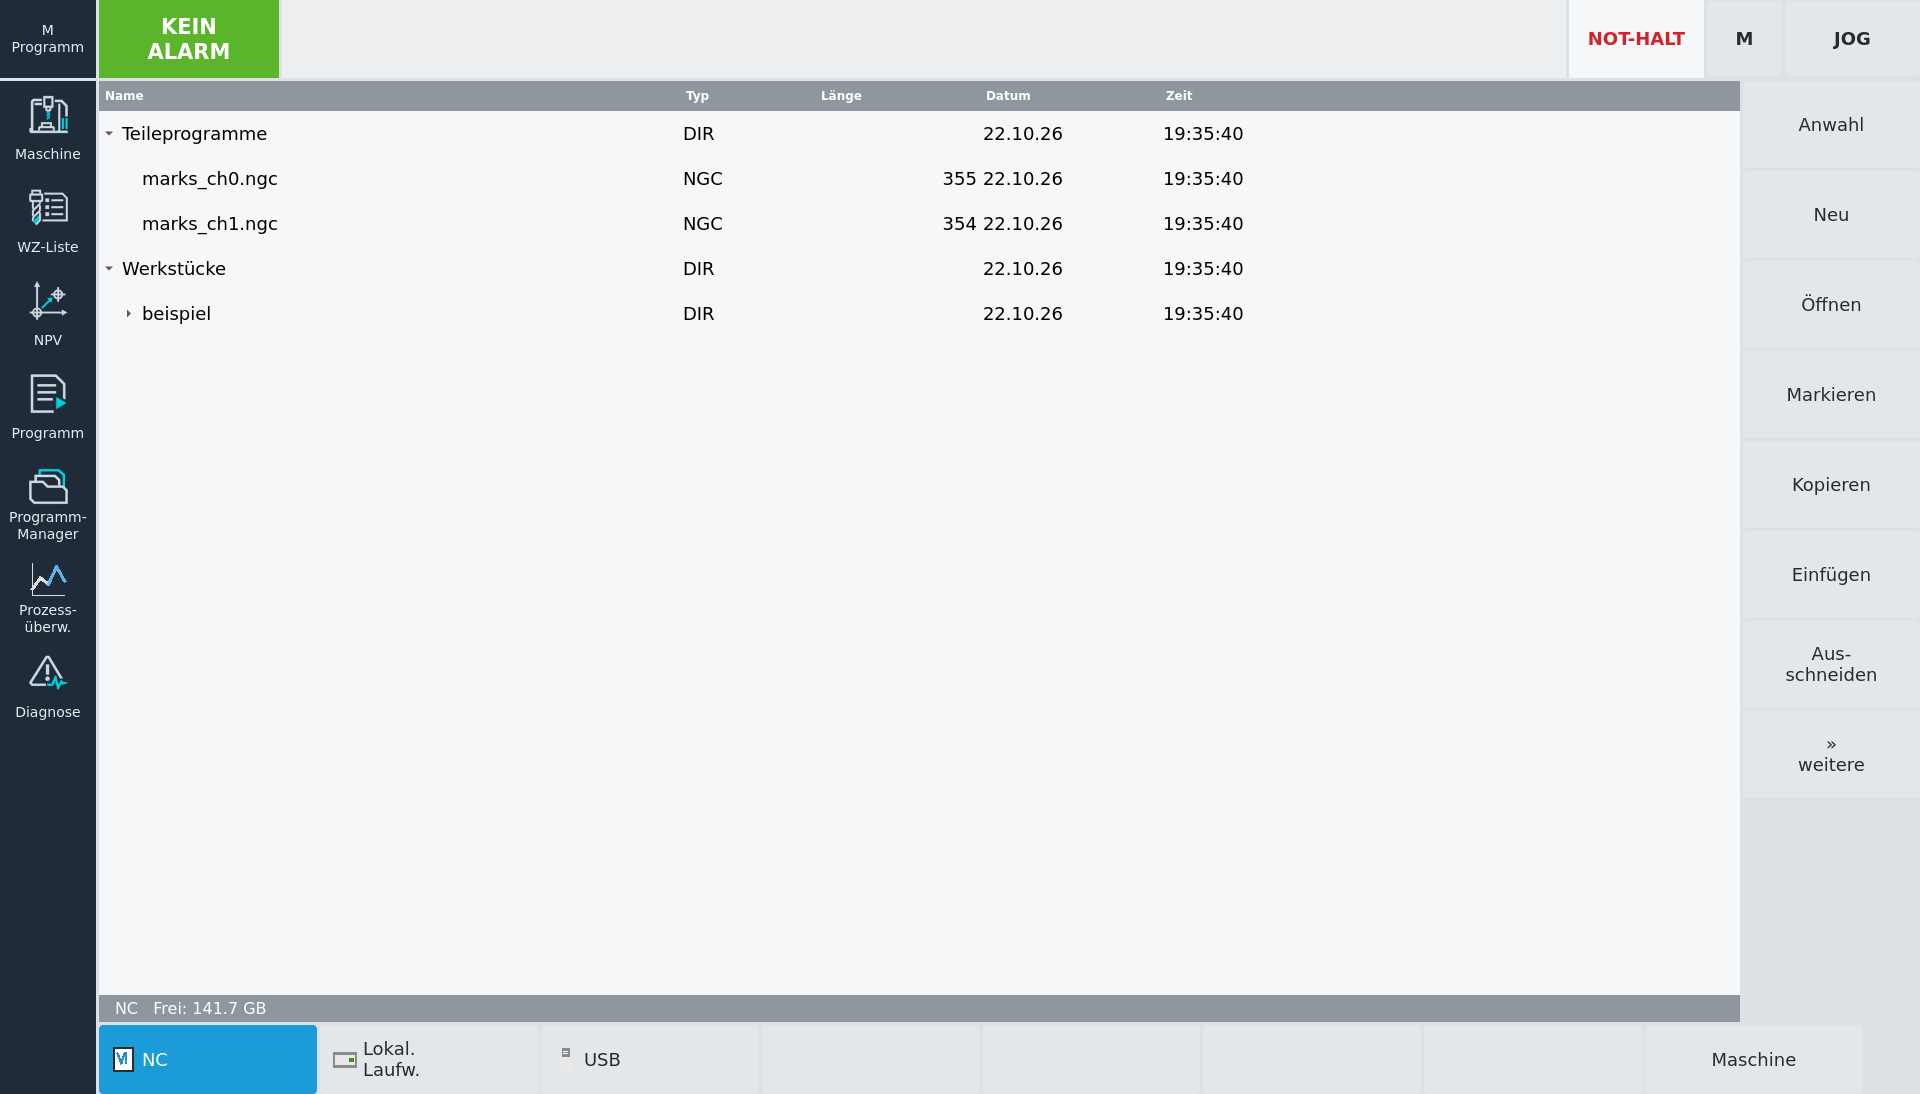
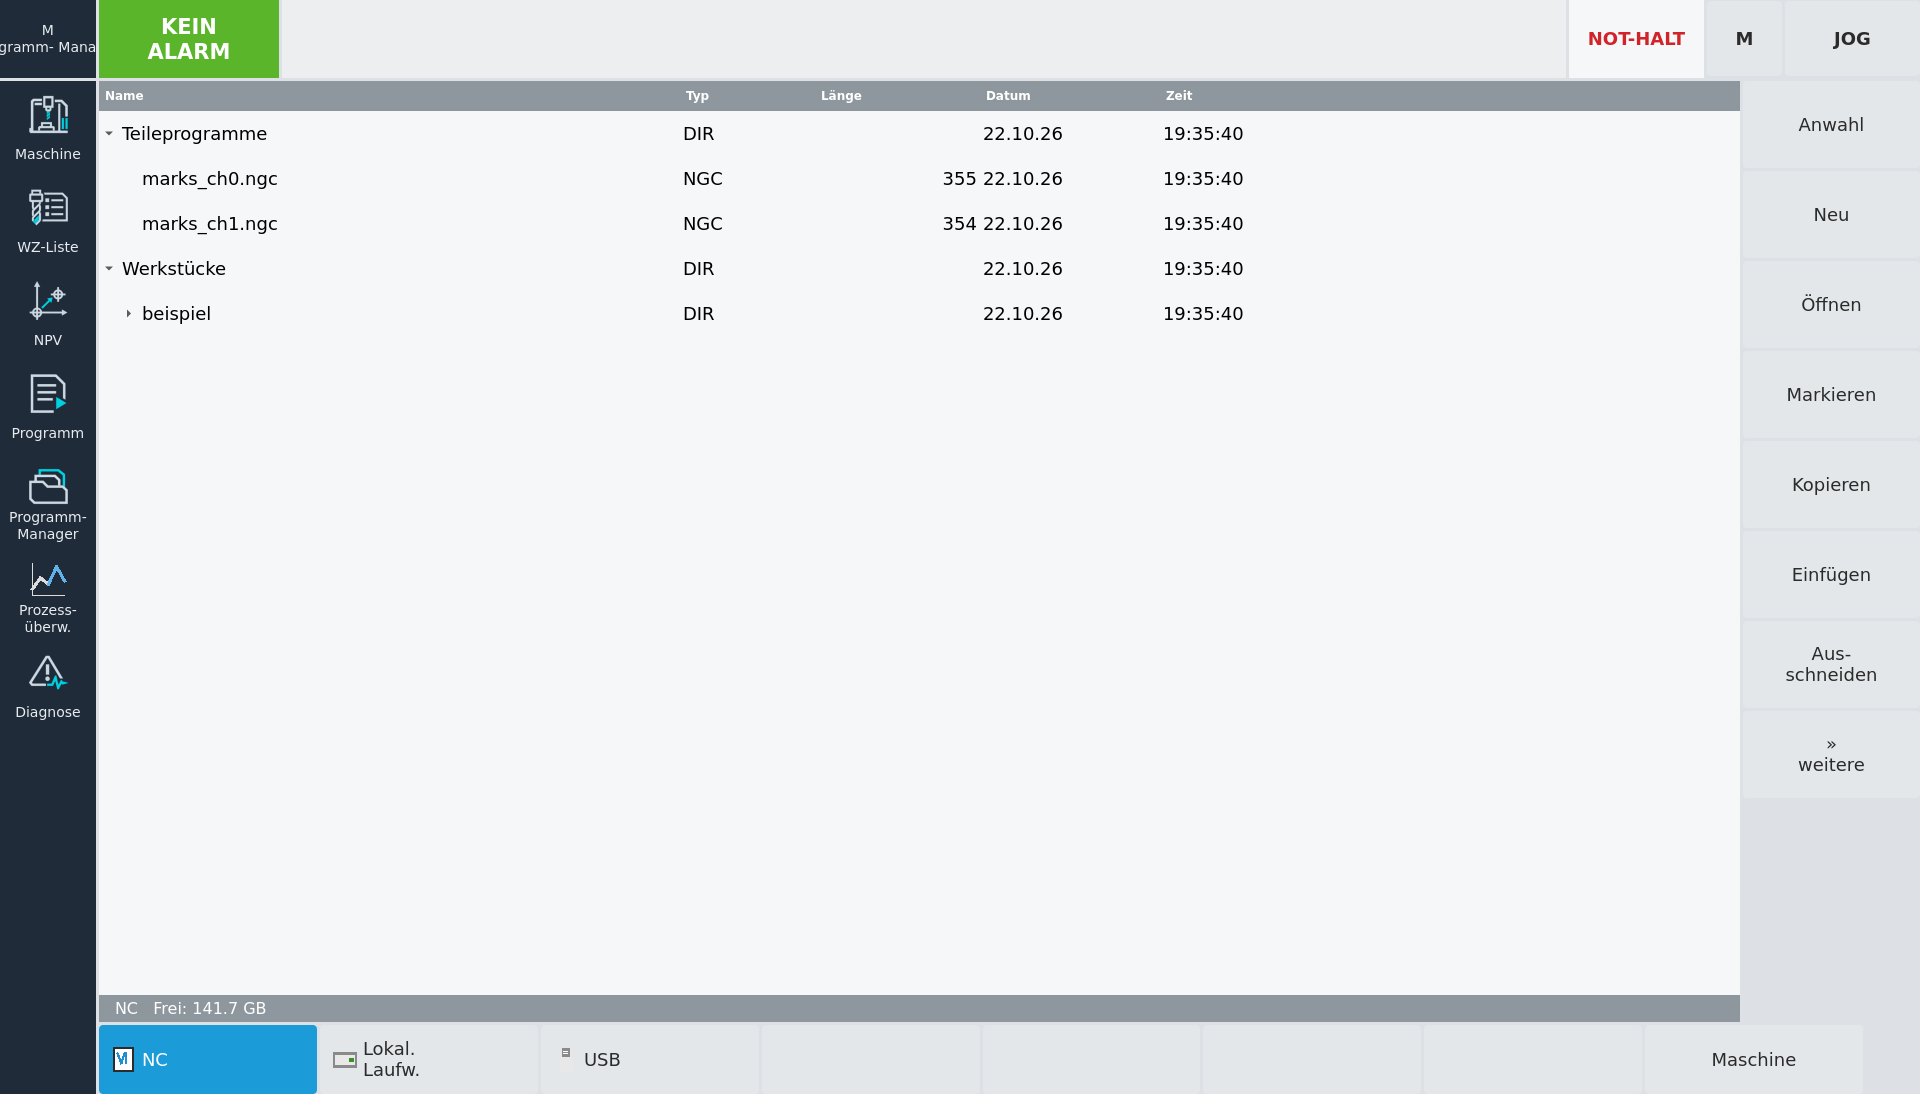 Program manager
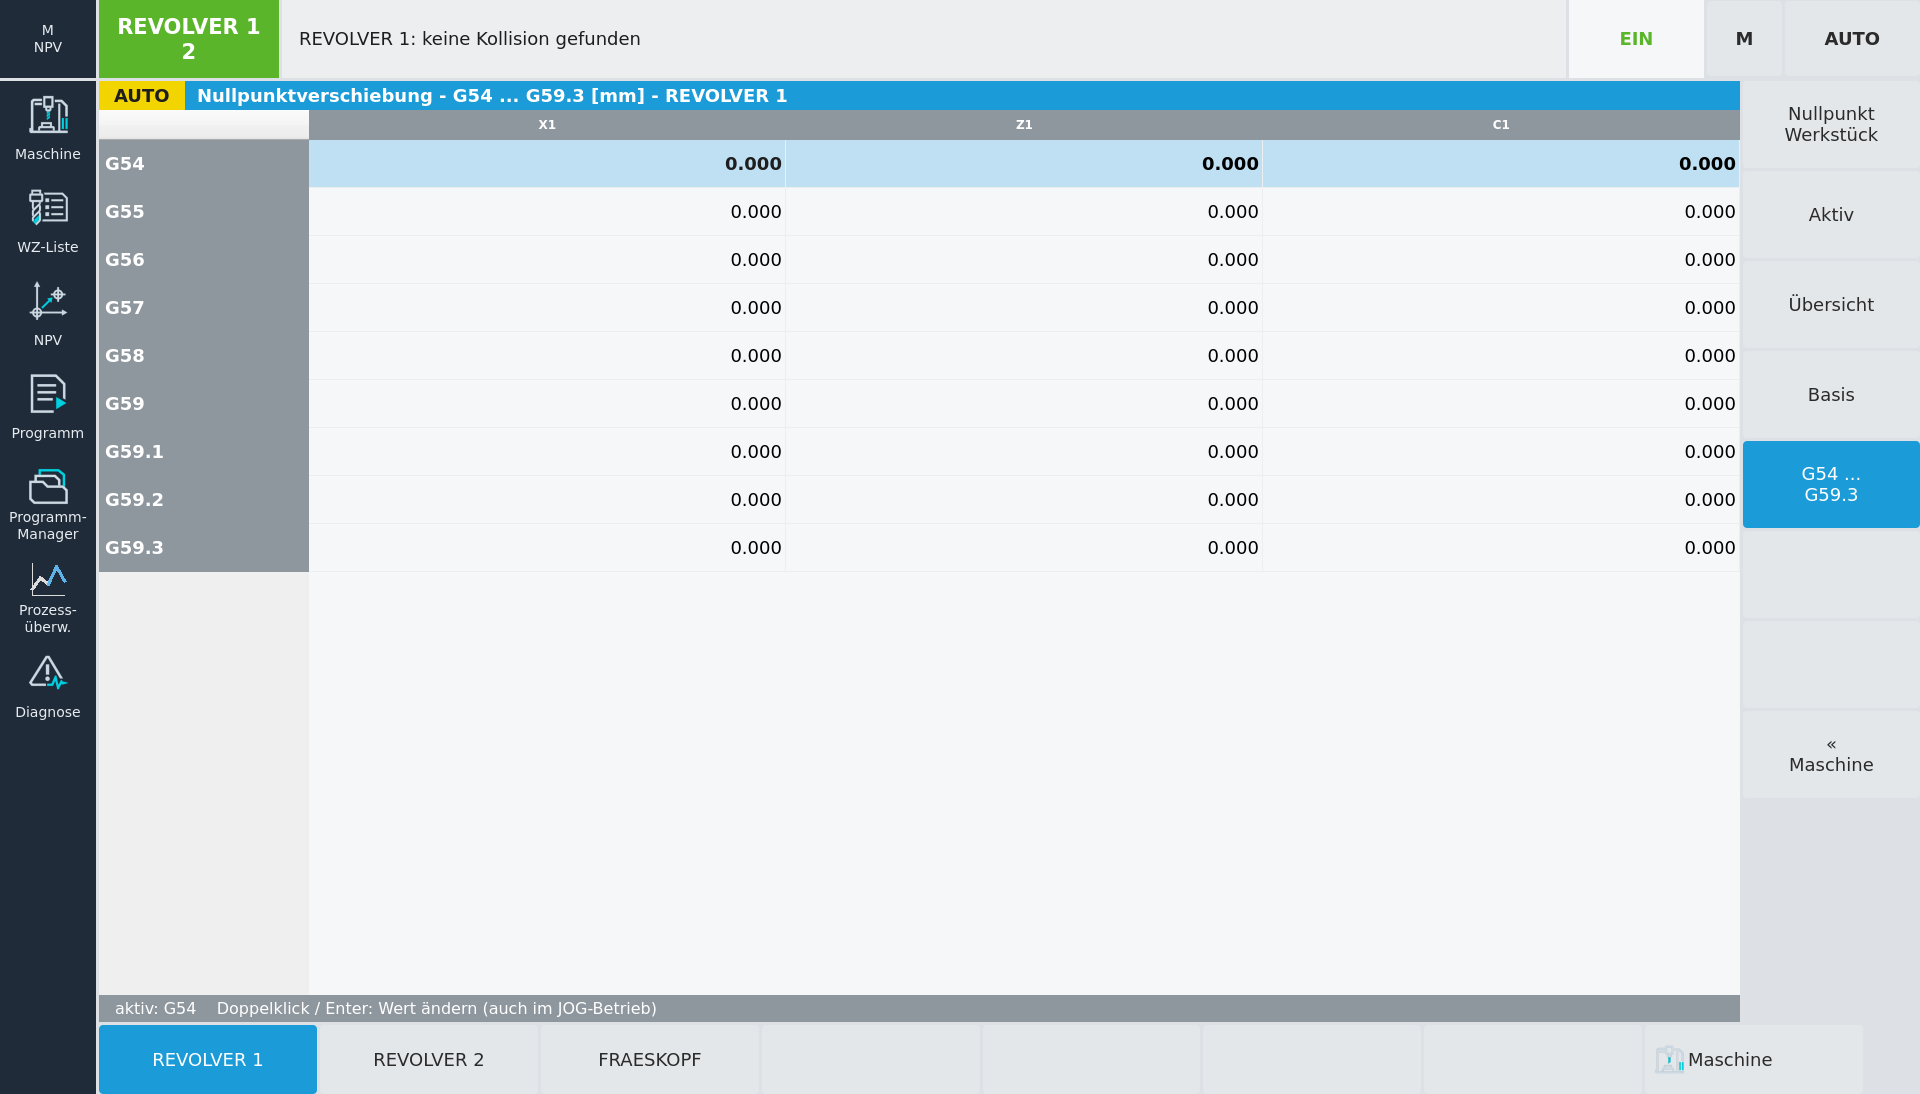
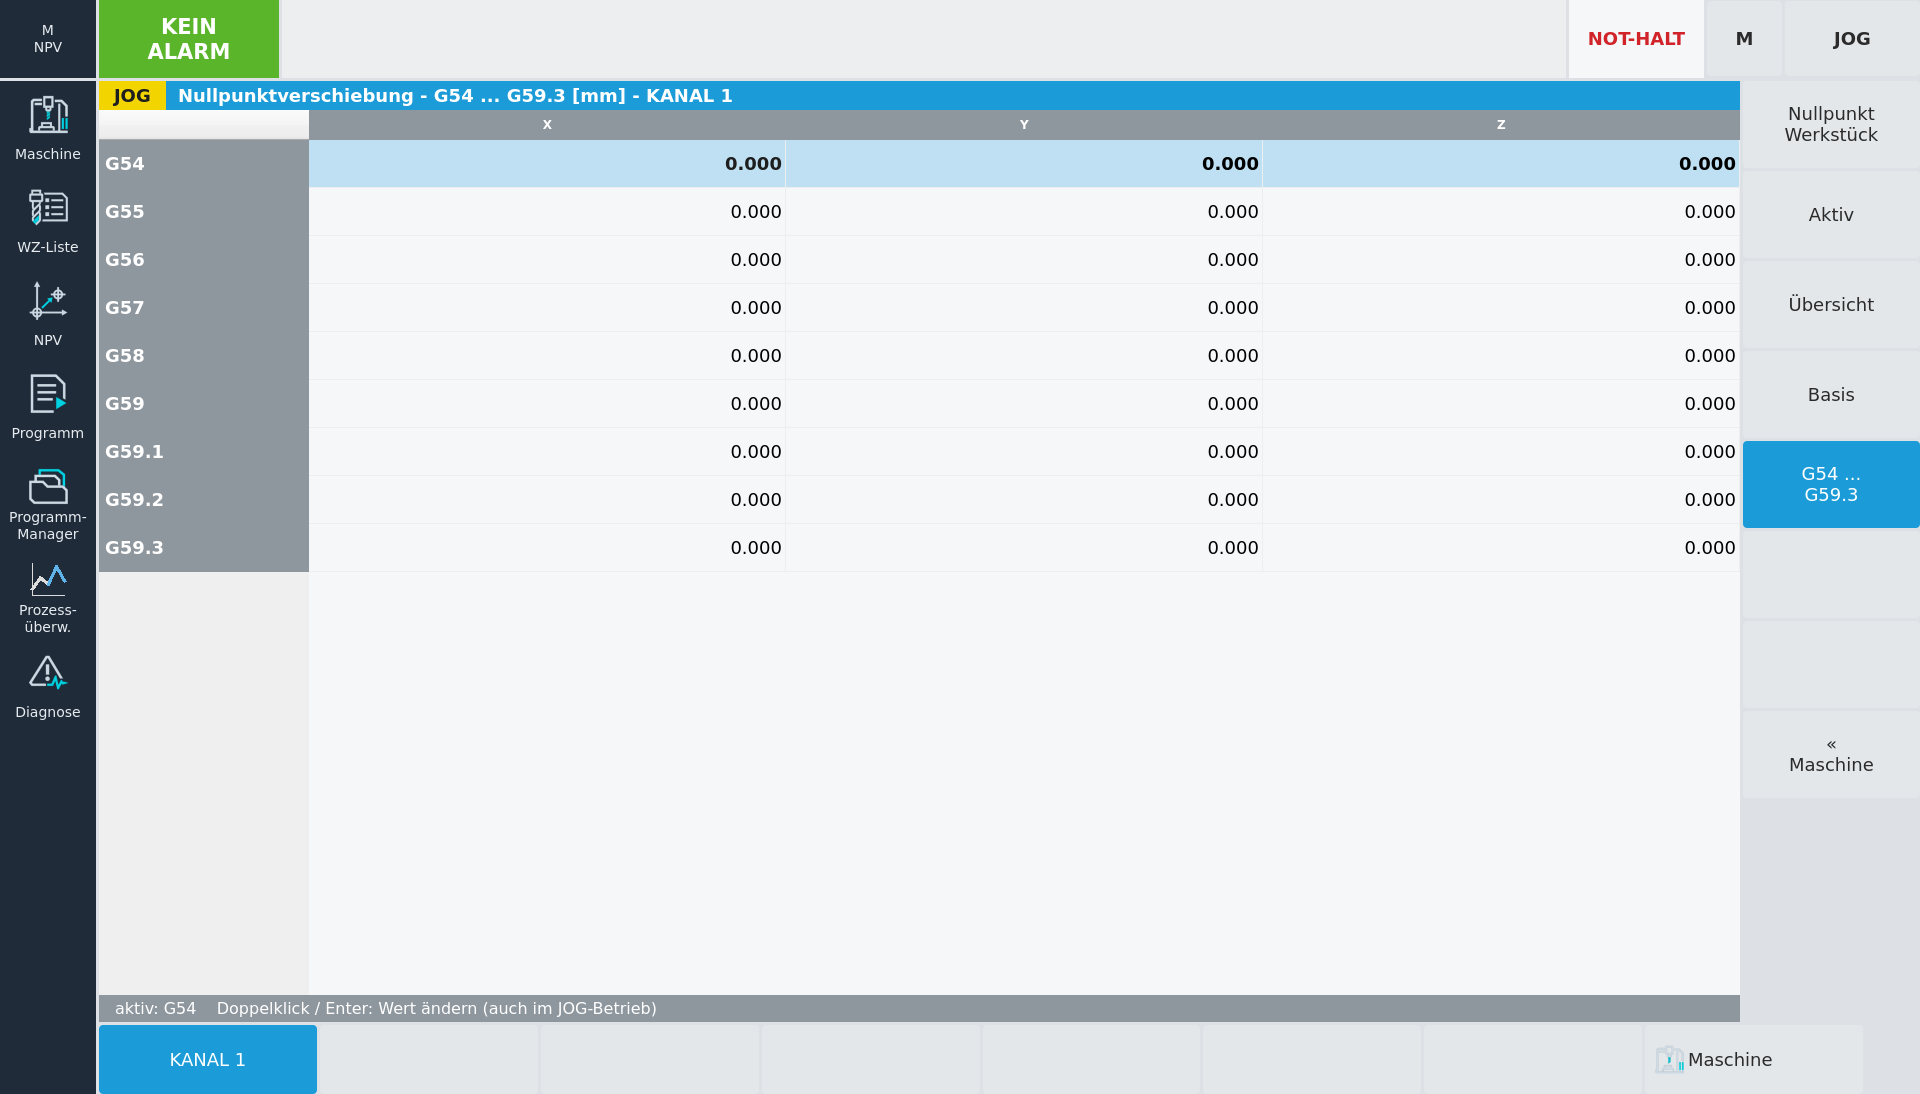 Work offsets
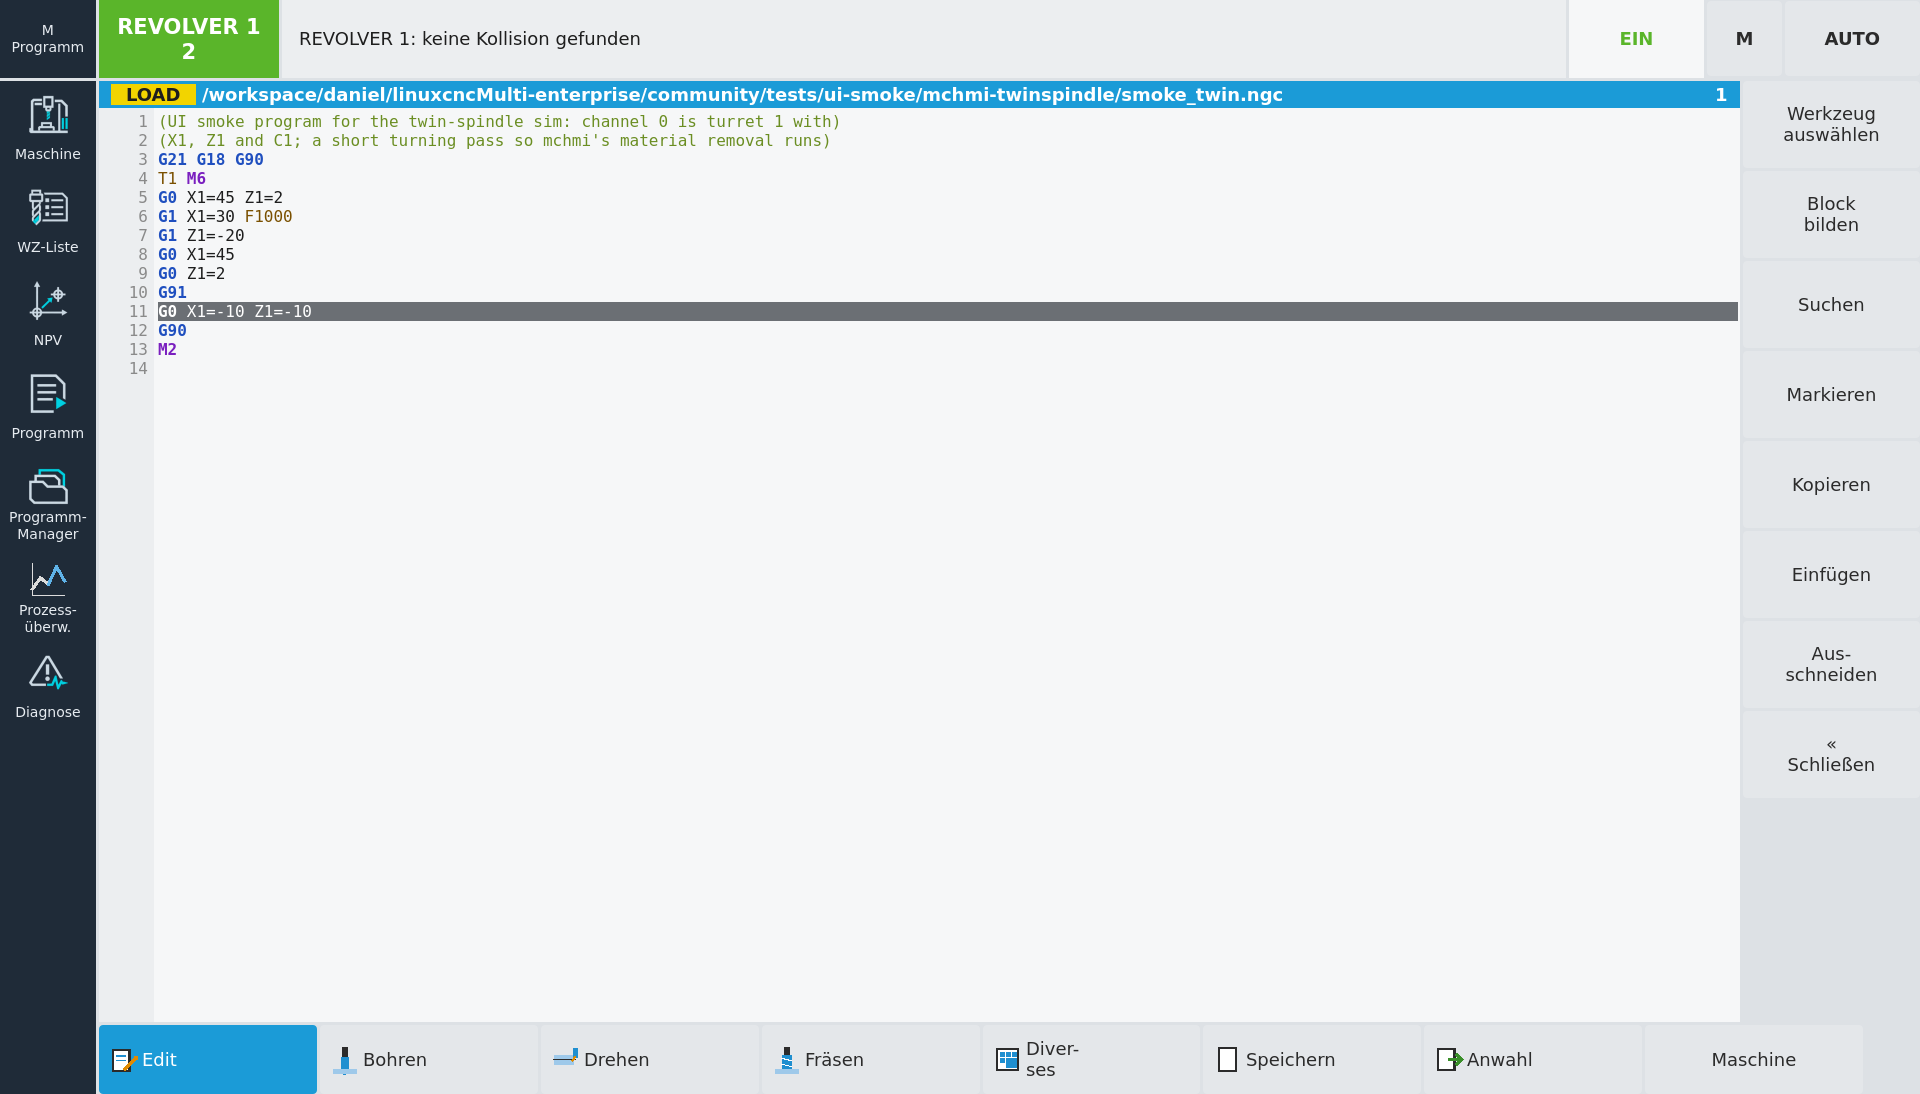
 Program editor
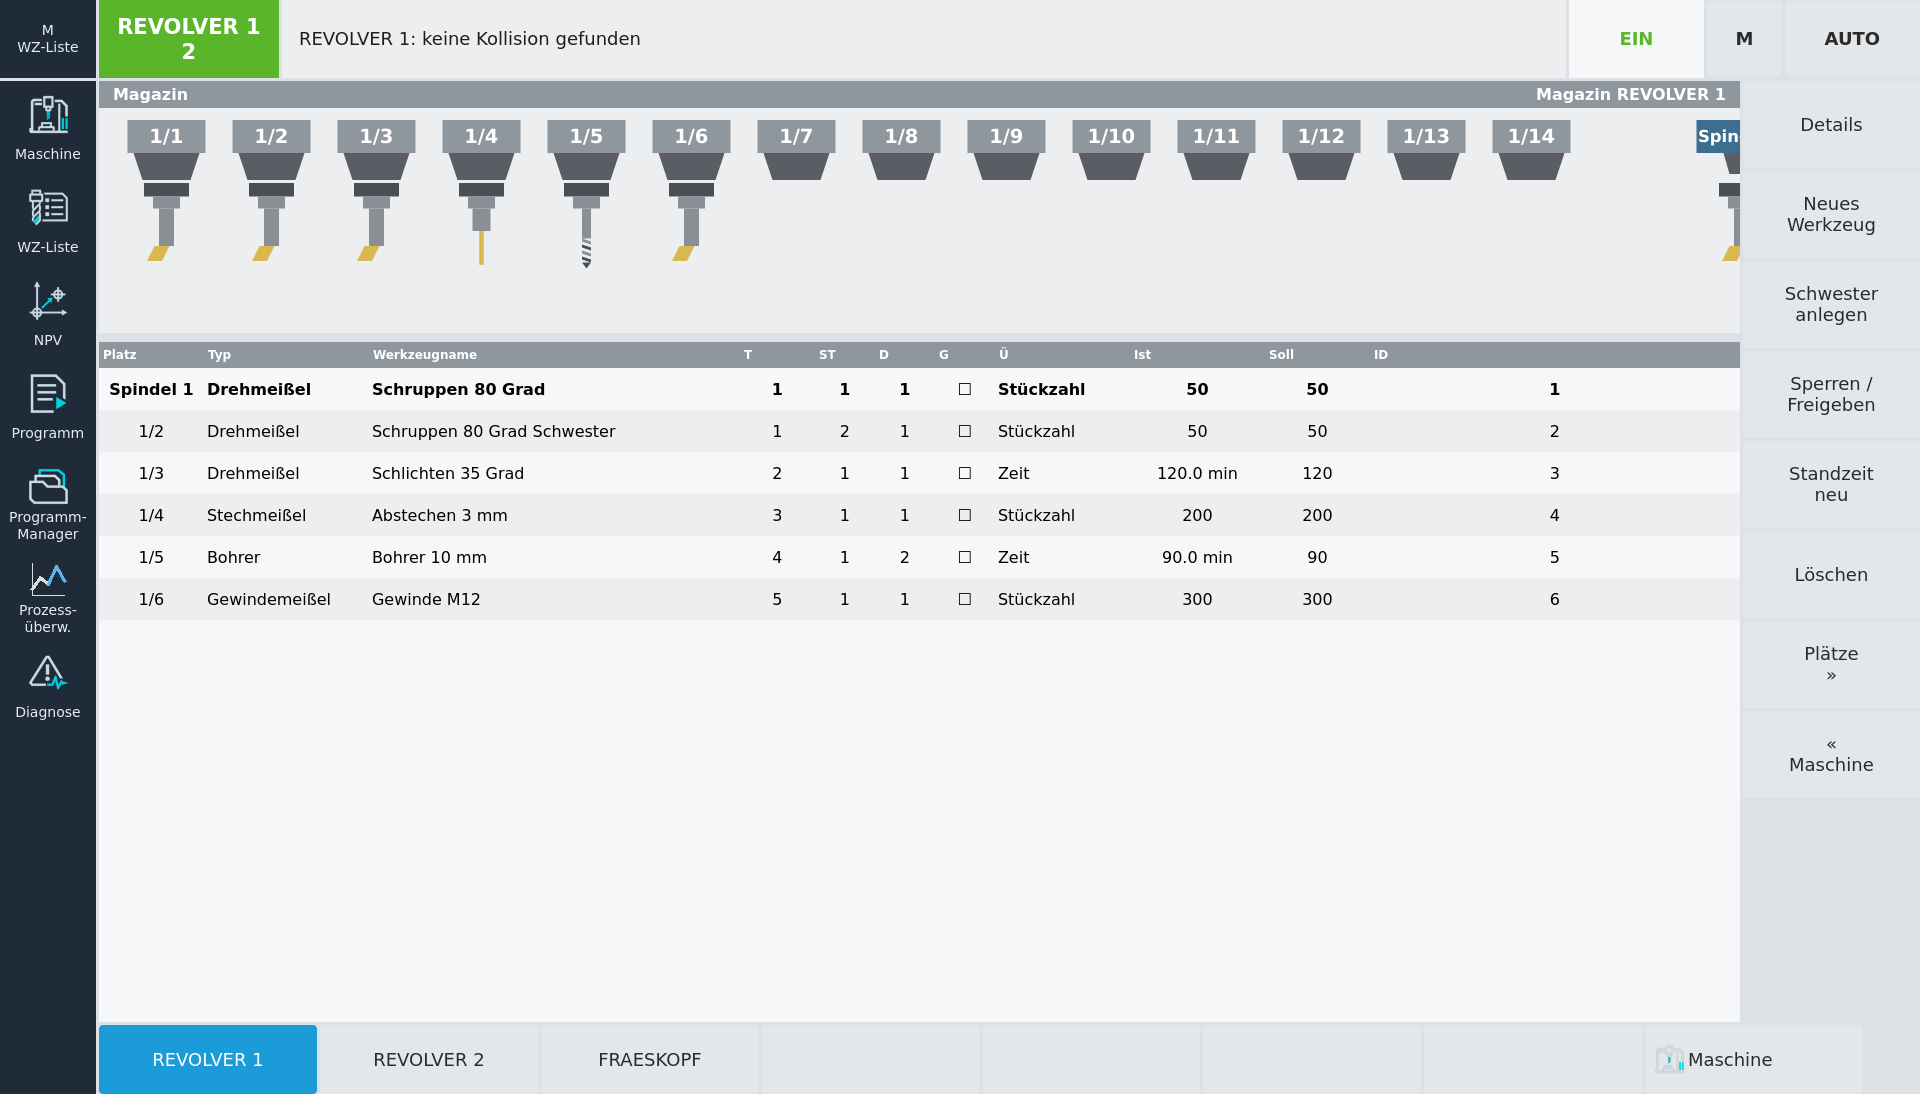
 Tool list
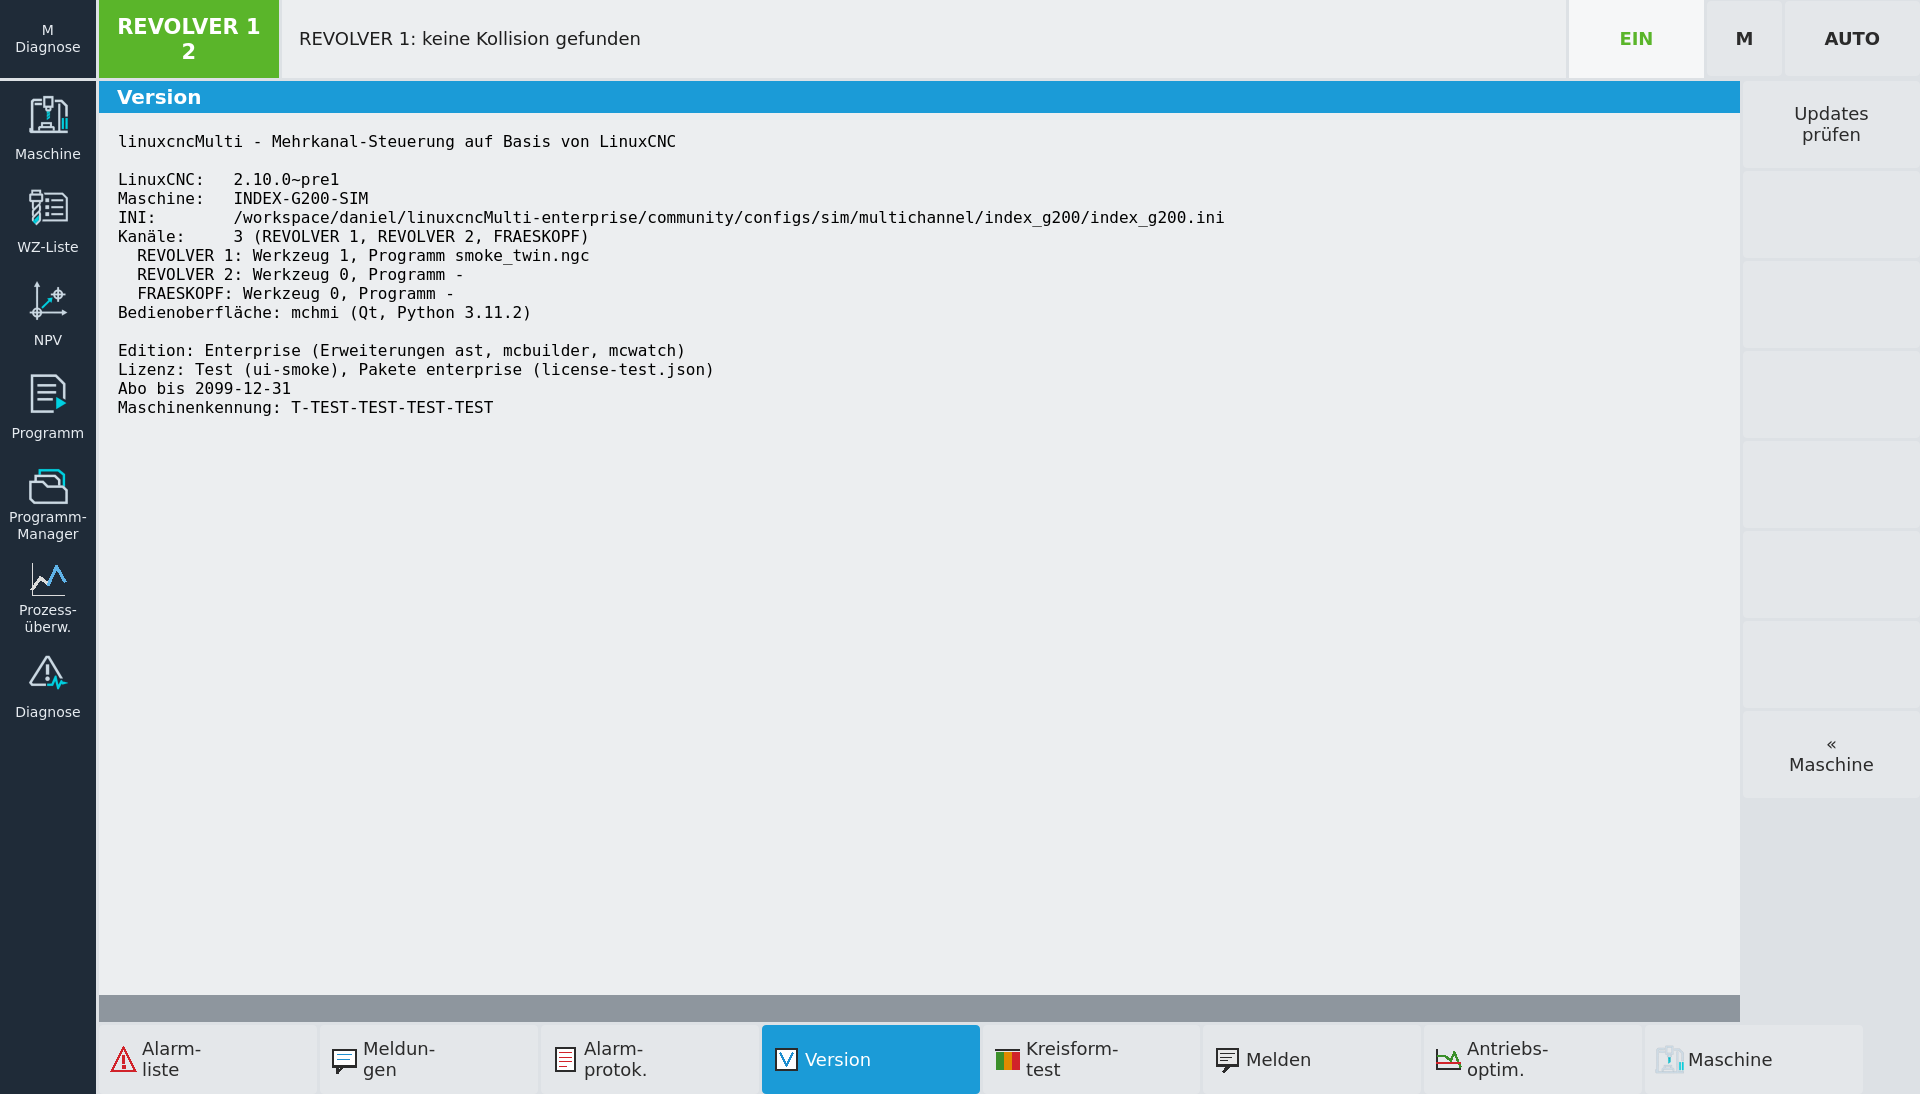
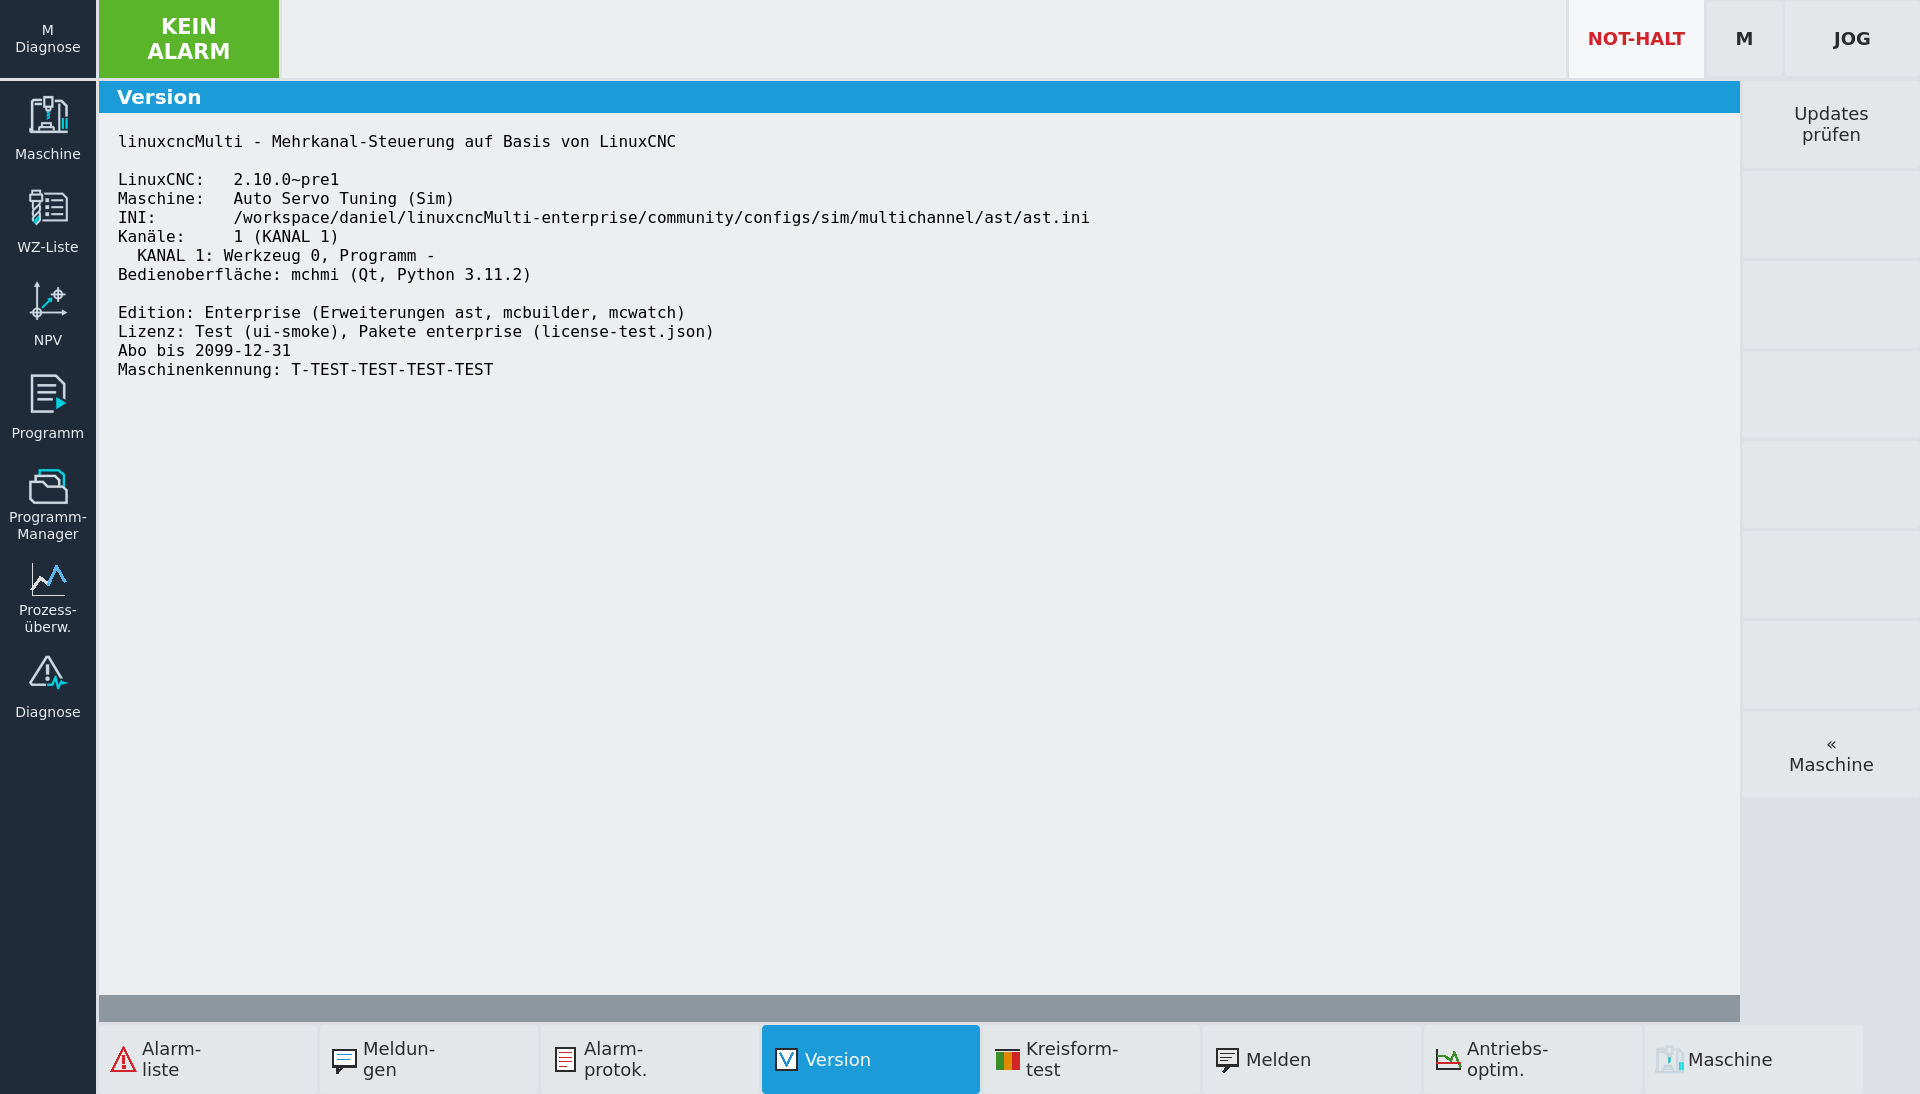 Version page: edition, licence, updates
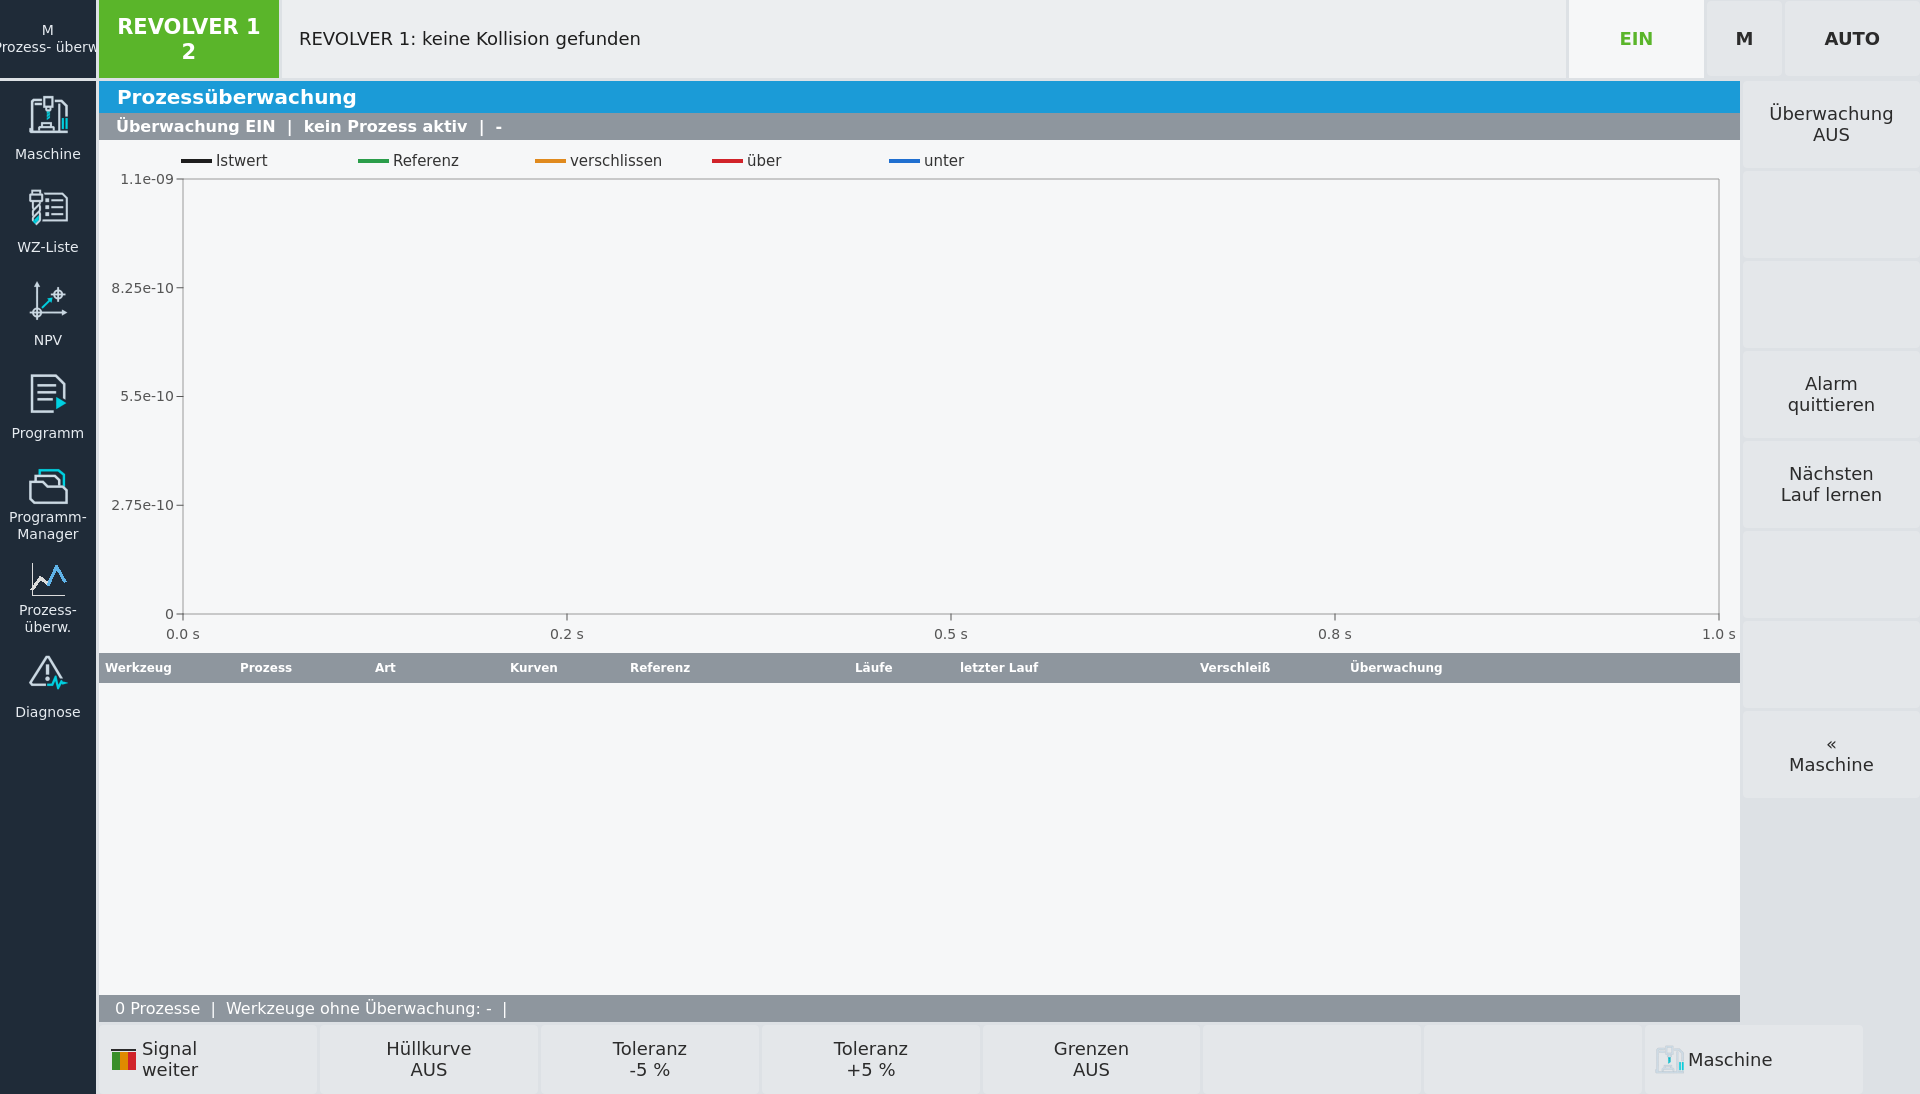
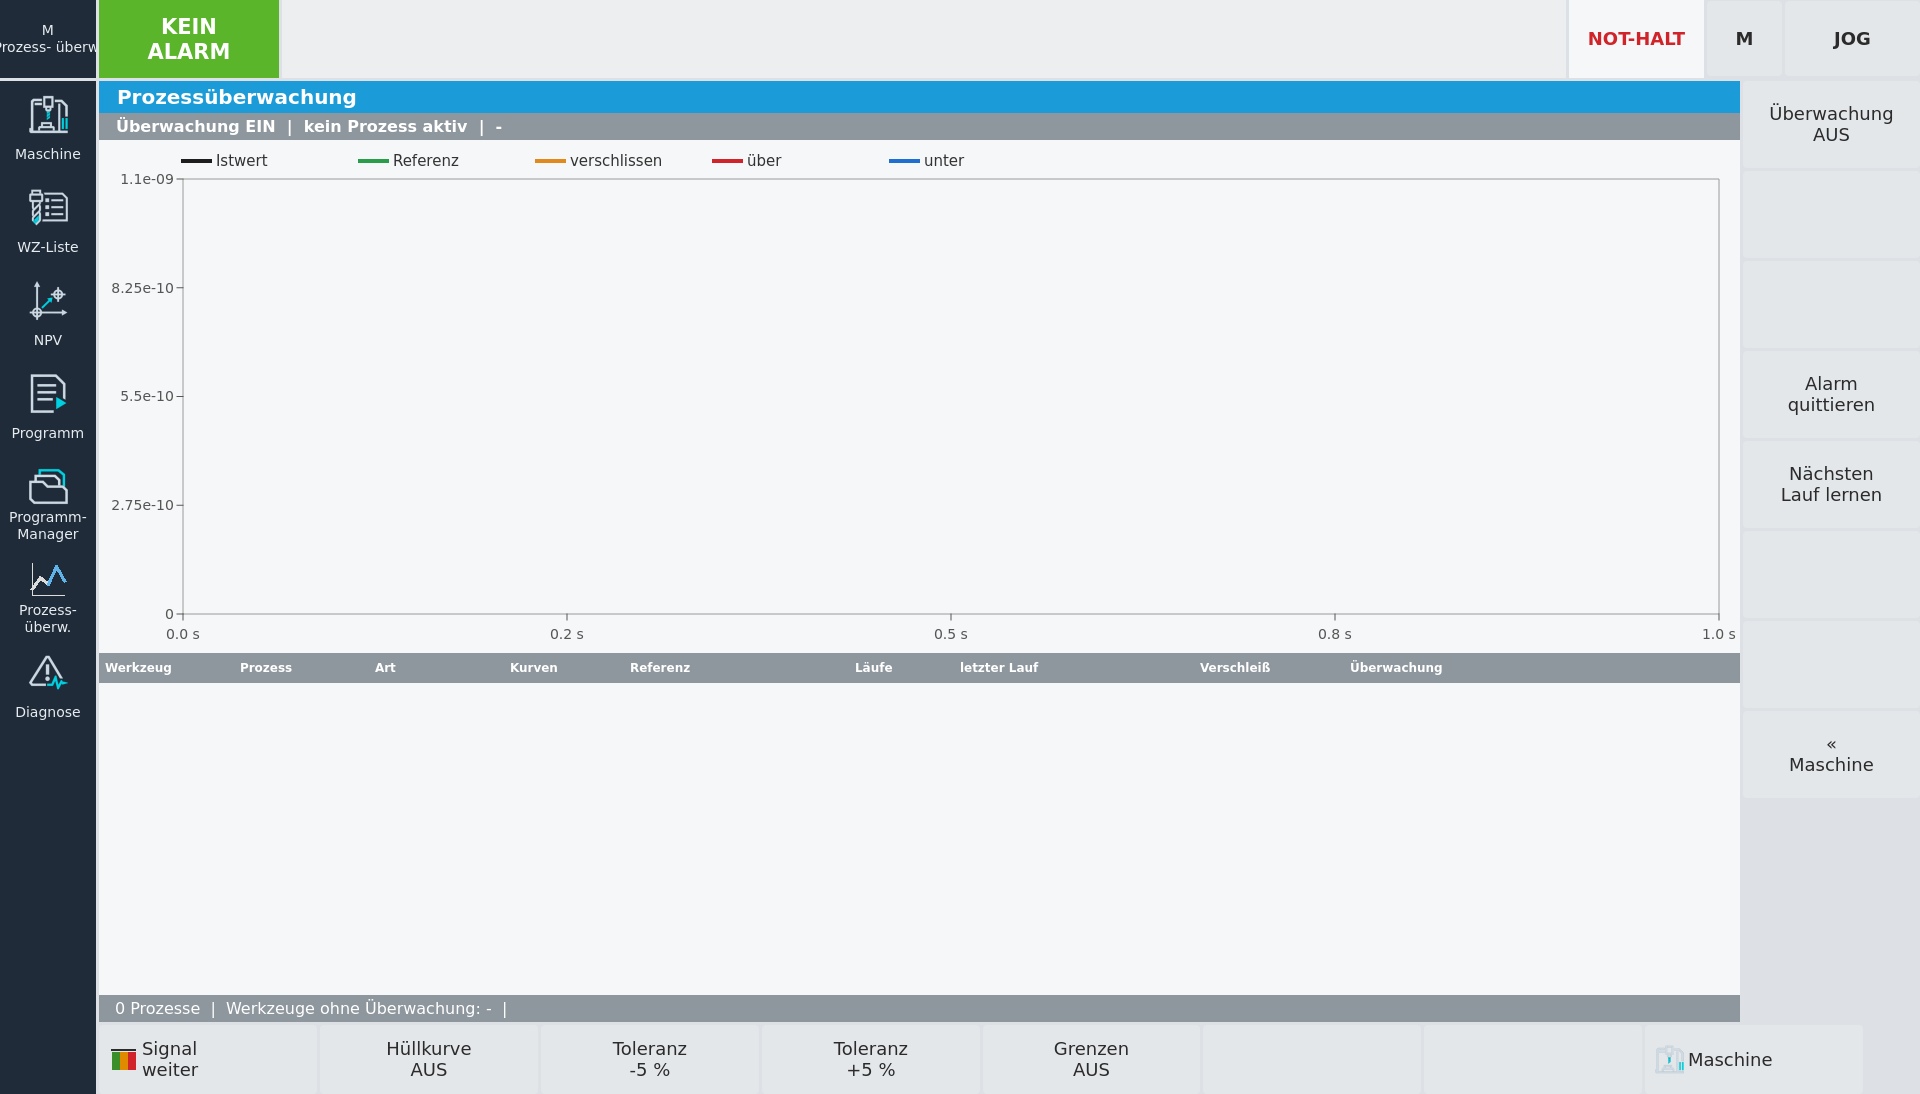 Process monitoring (mcwatch)
DMU 60: 5-axis table-table, tool changer channel, process monitoring
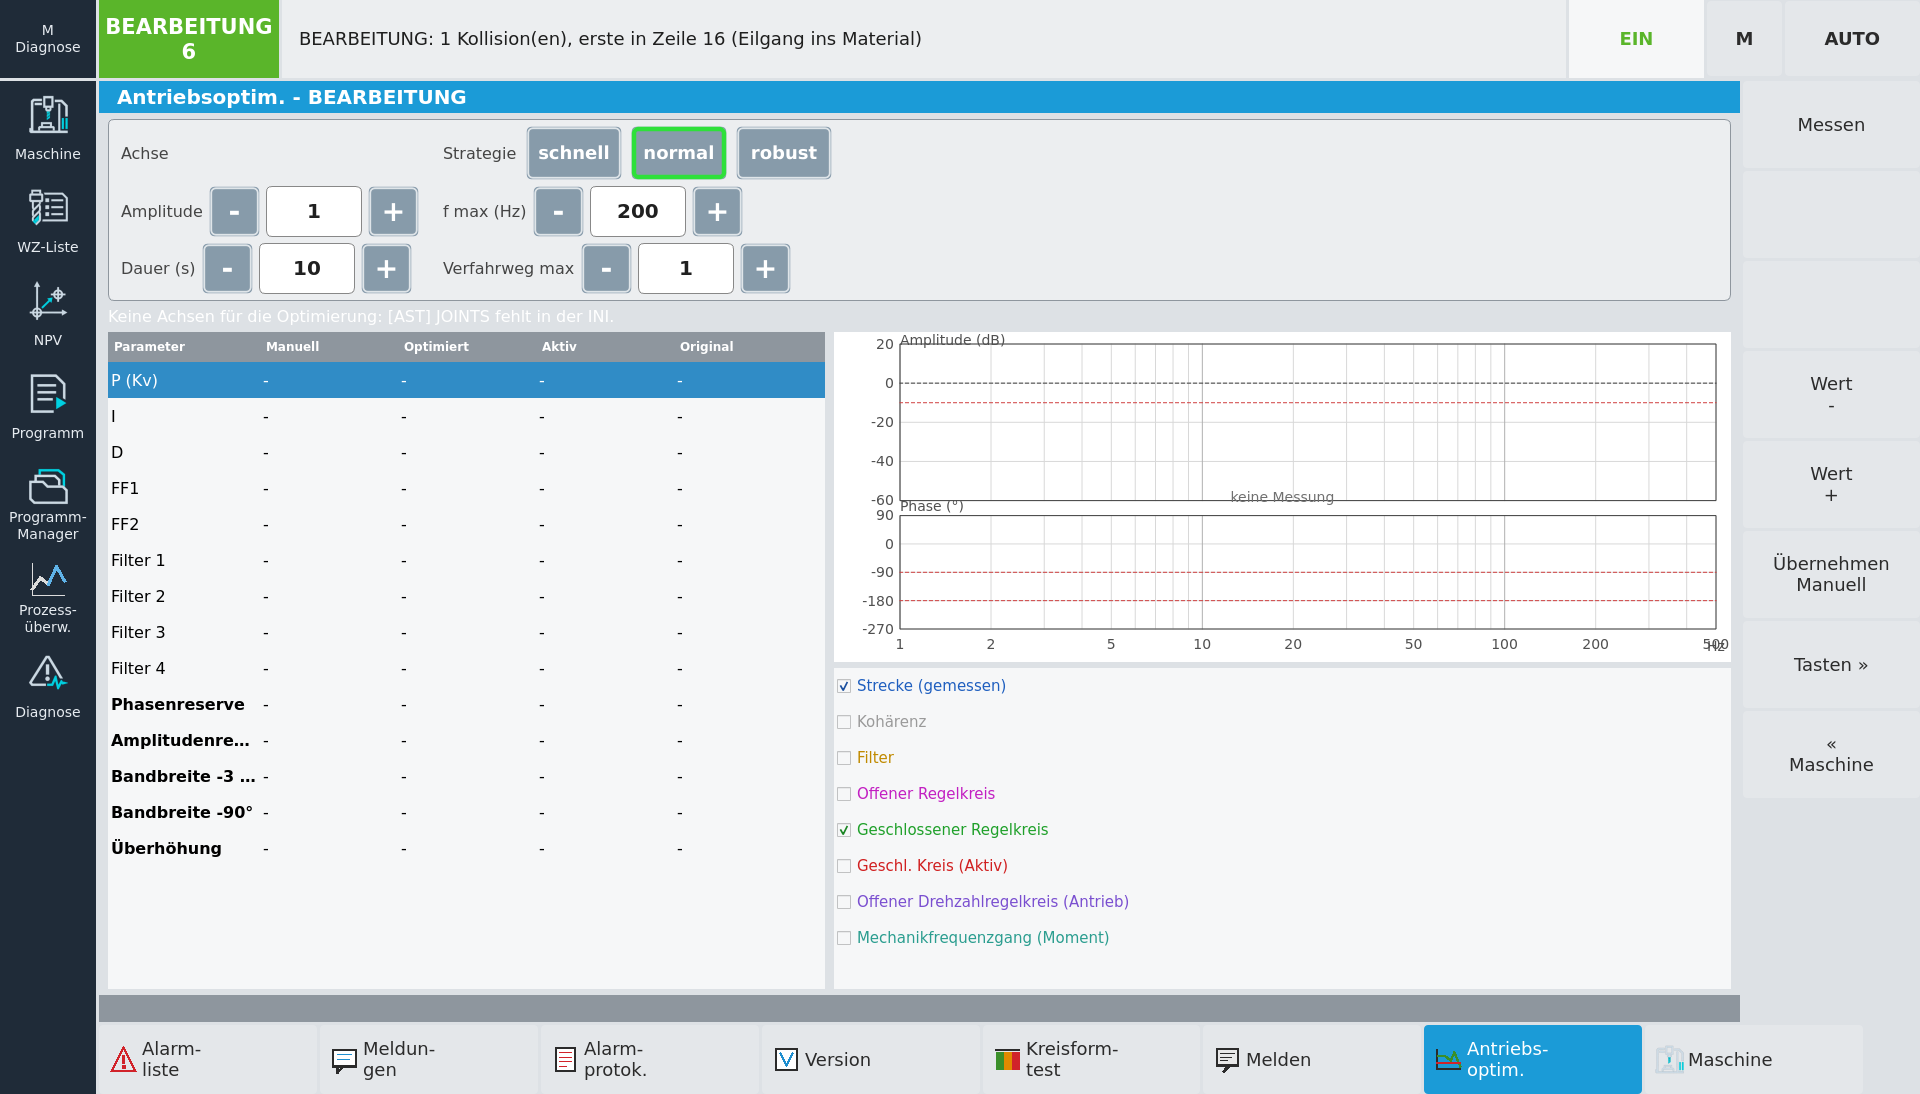 Auto Servo Tuning page
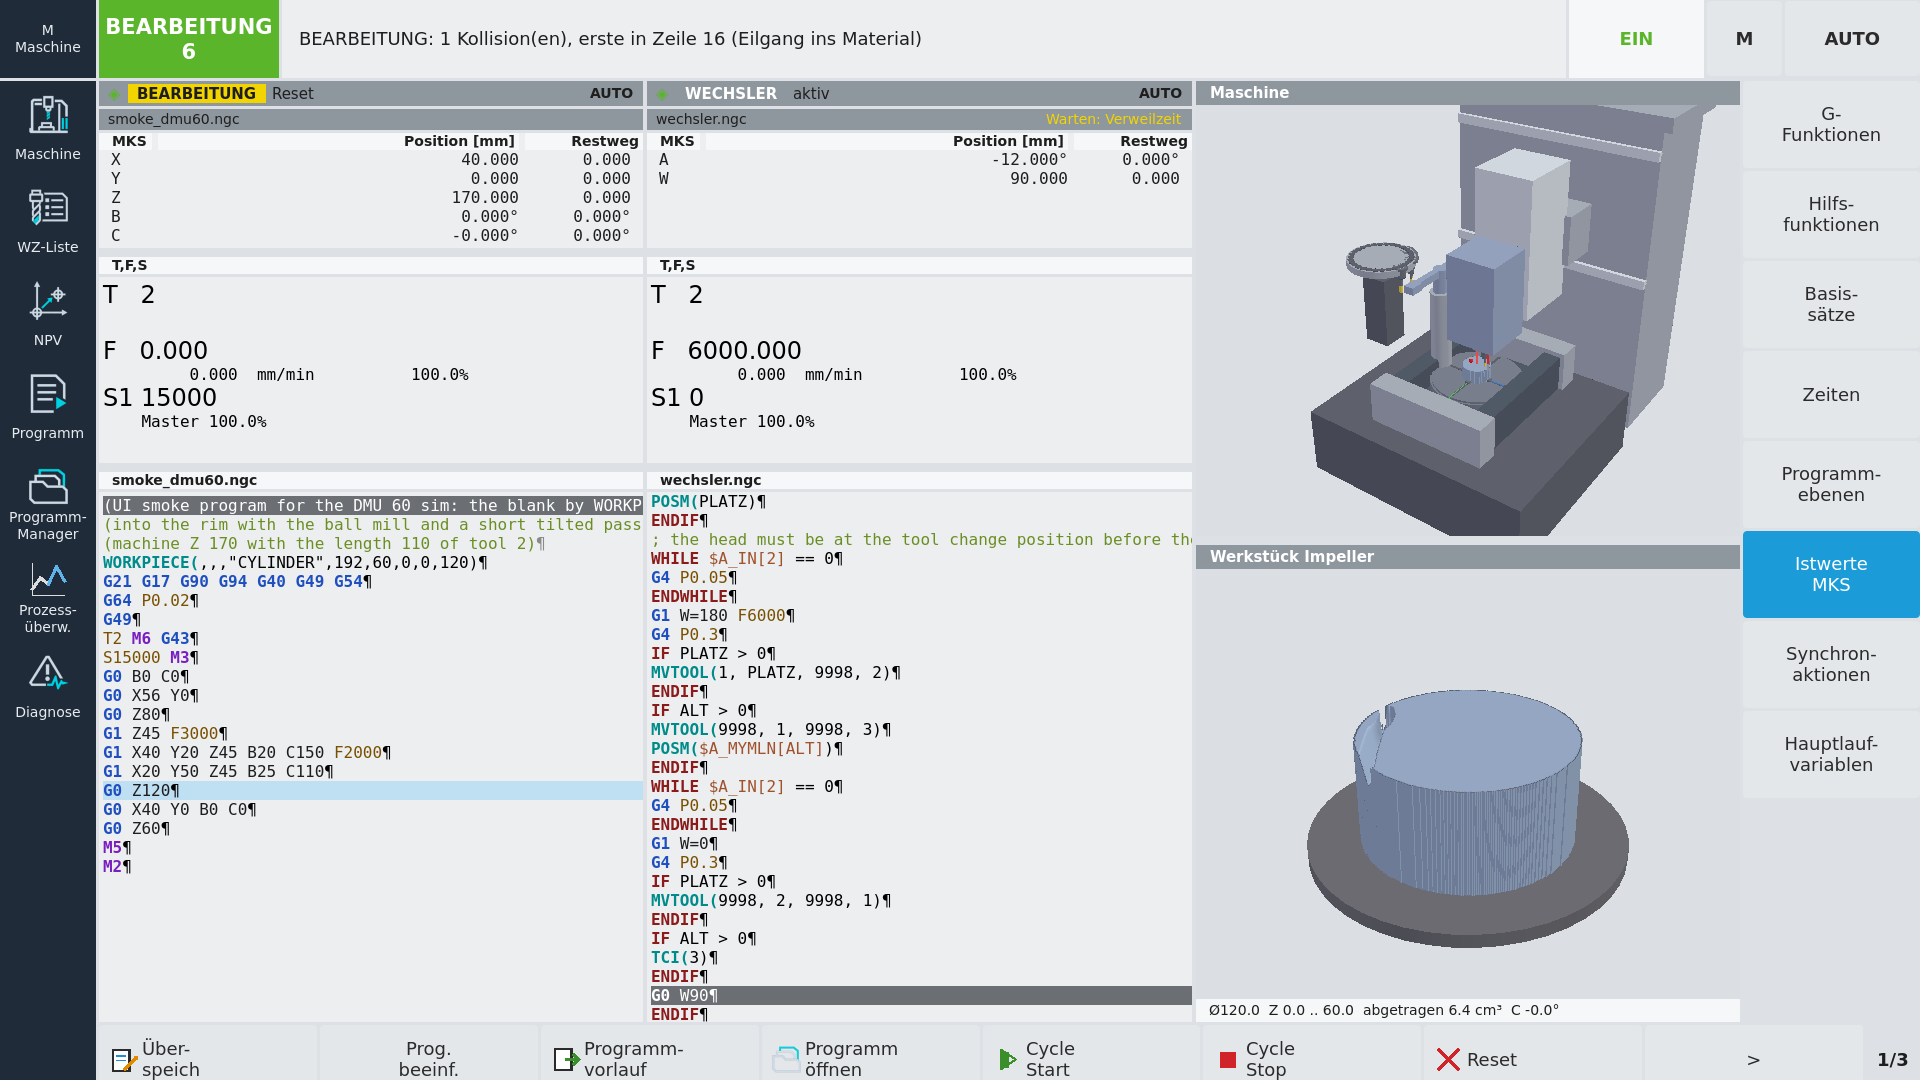 After the smoke program: the result
 Diagnosis: alarms and log
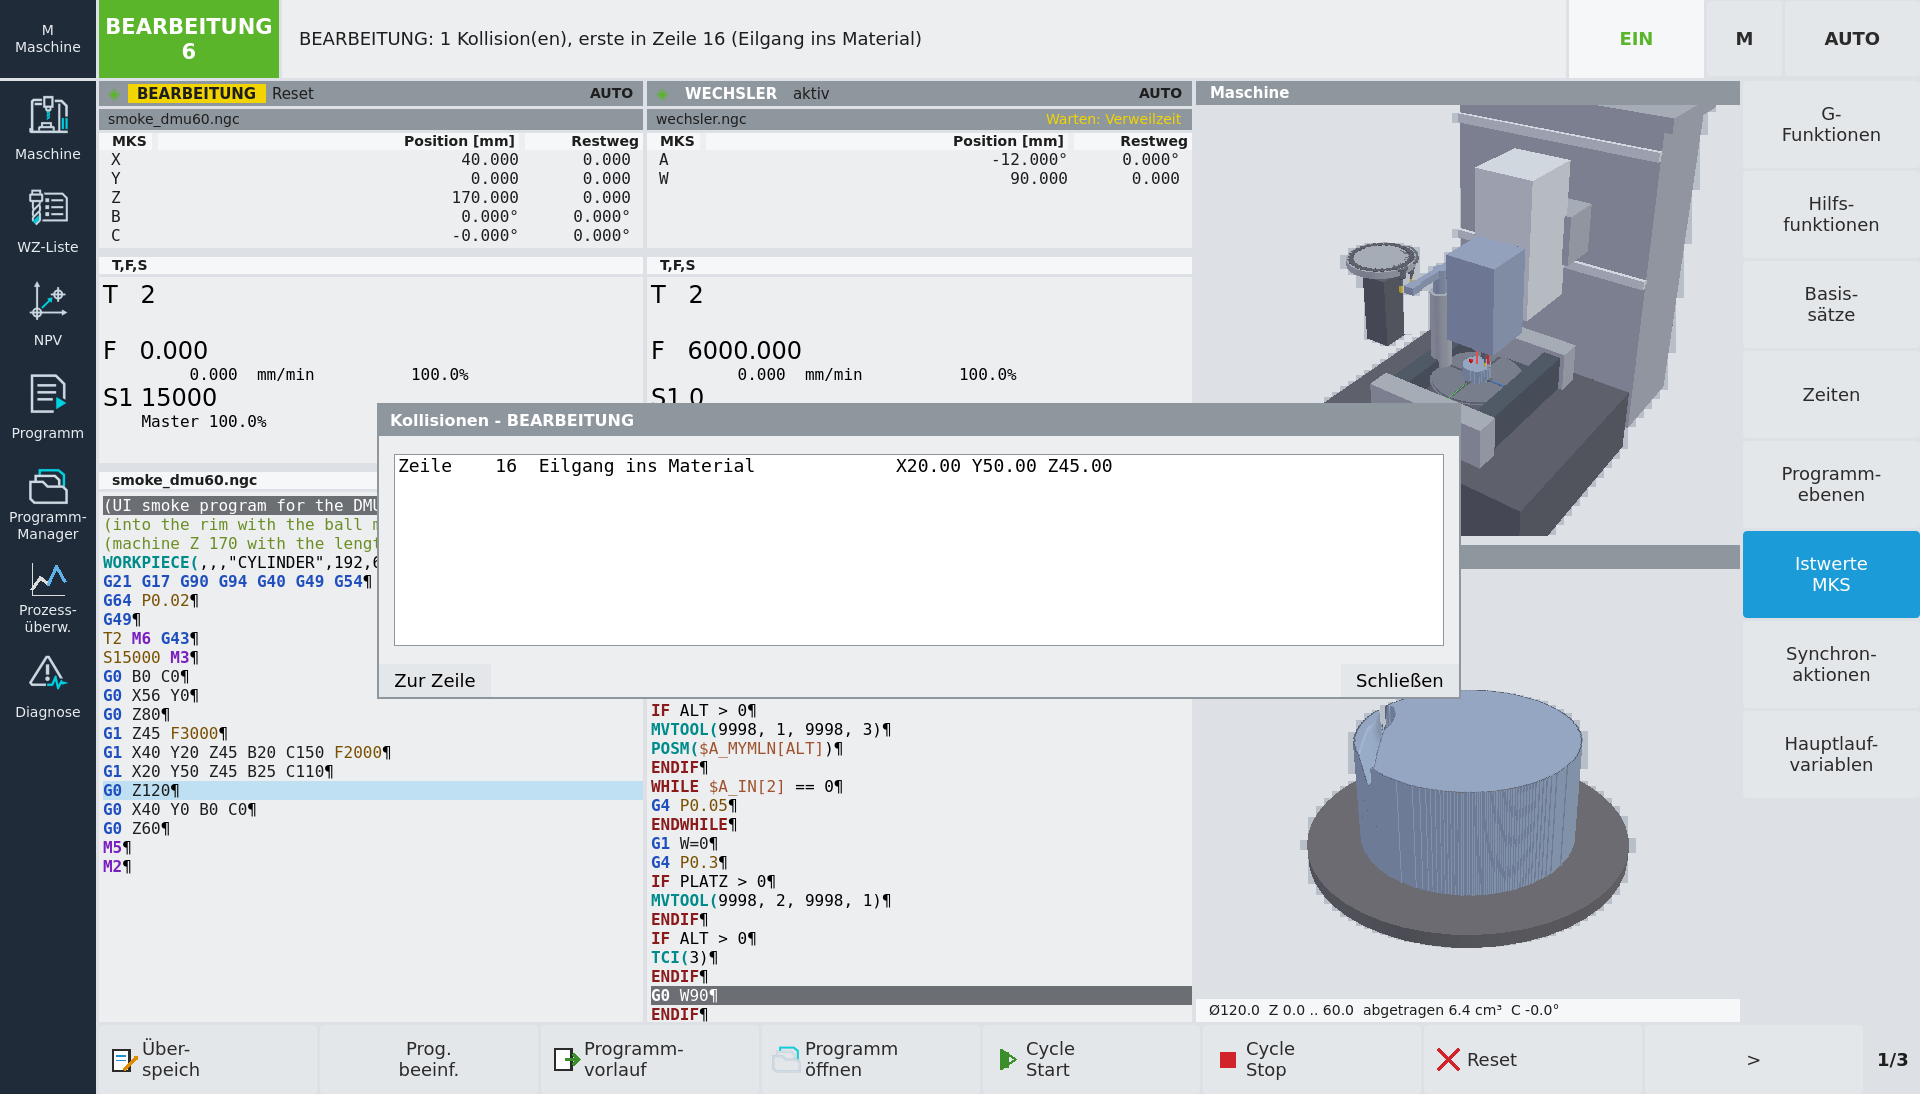 Machine area: channels, positions, program, 3D model
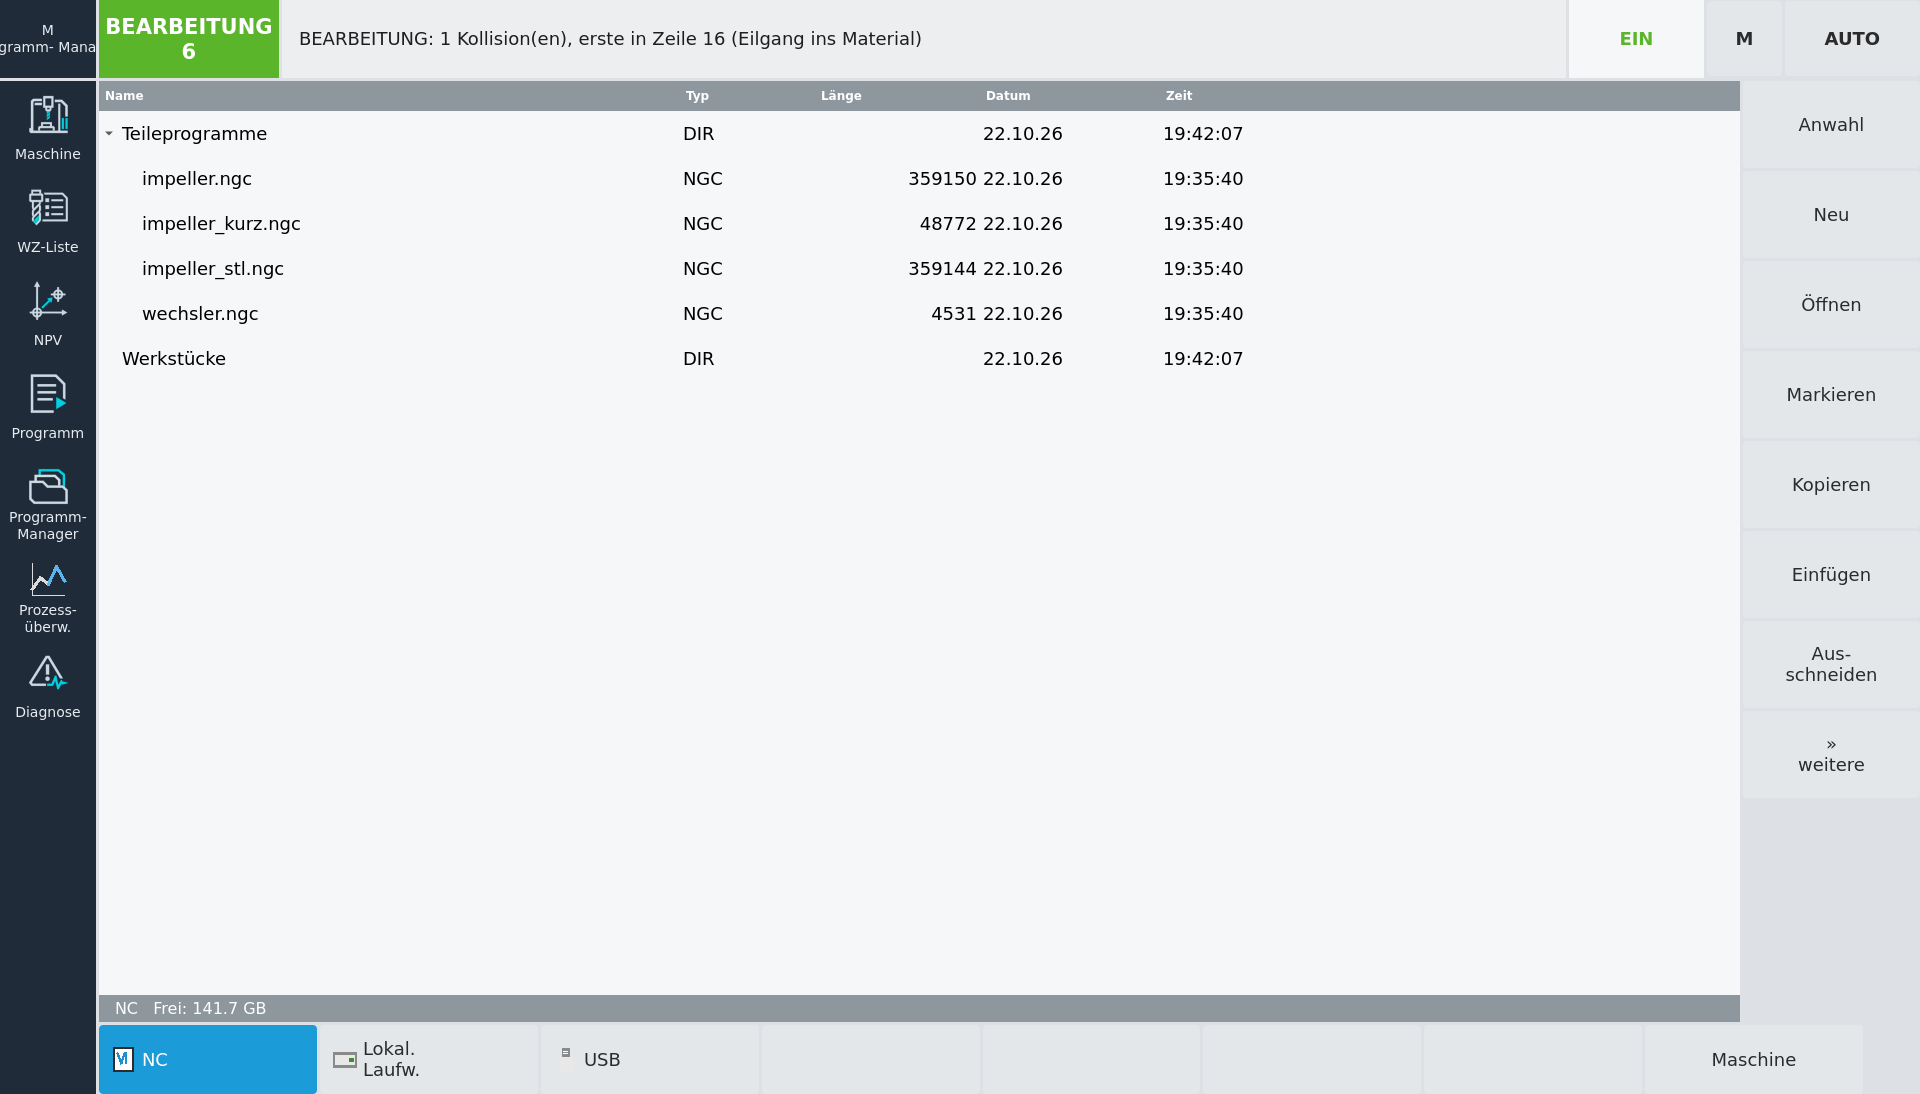 Program manager
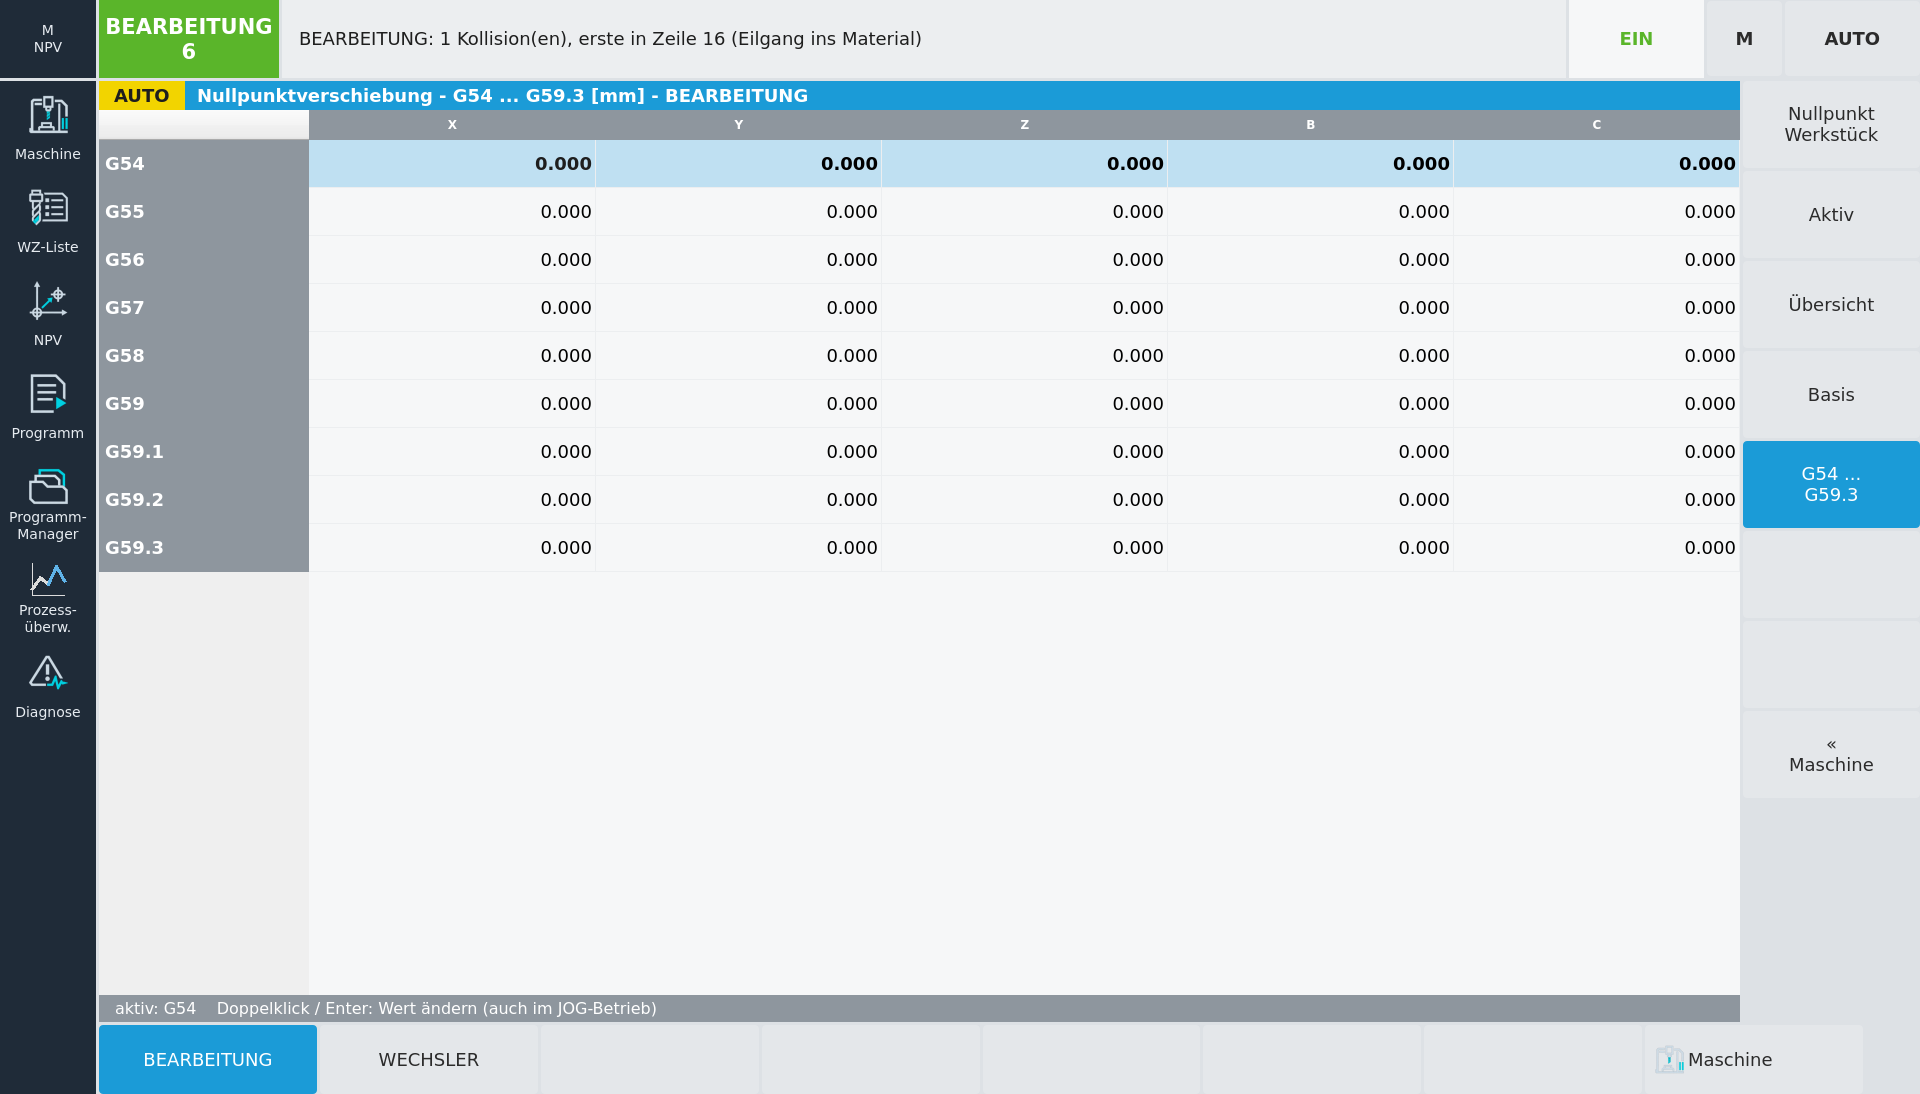 Work offsets
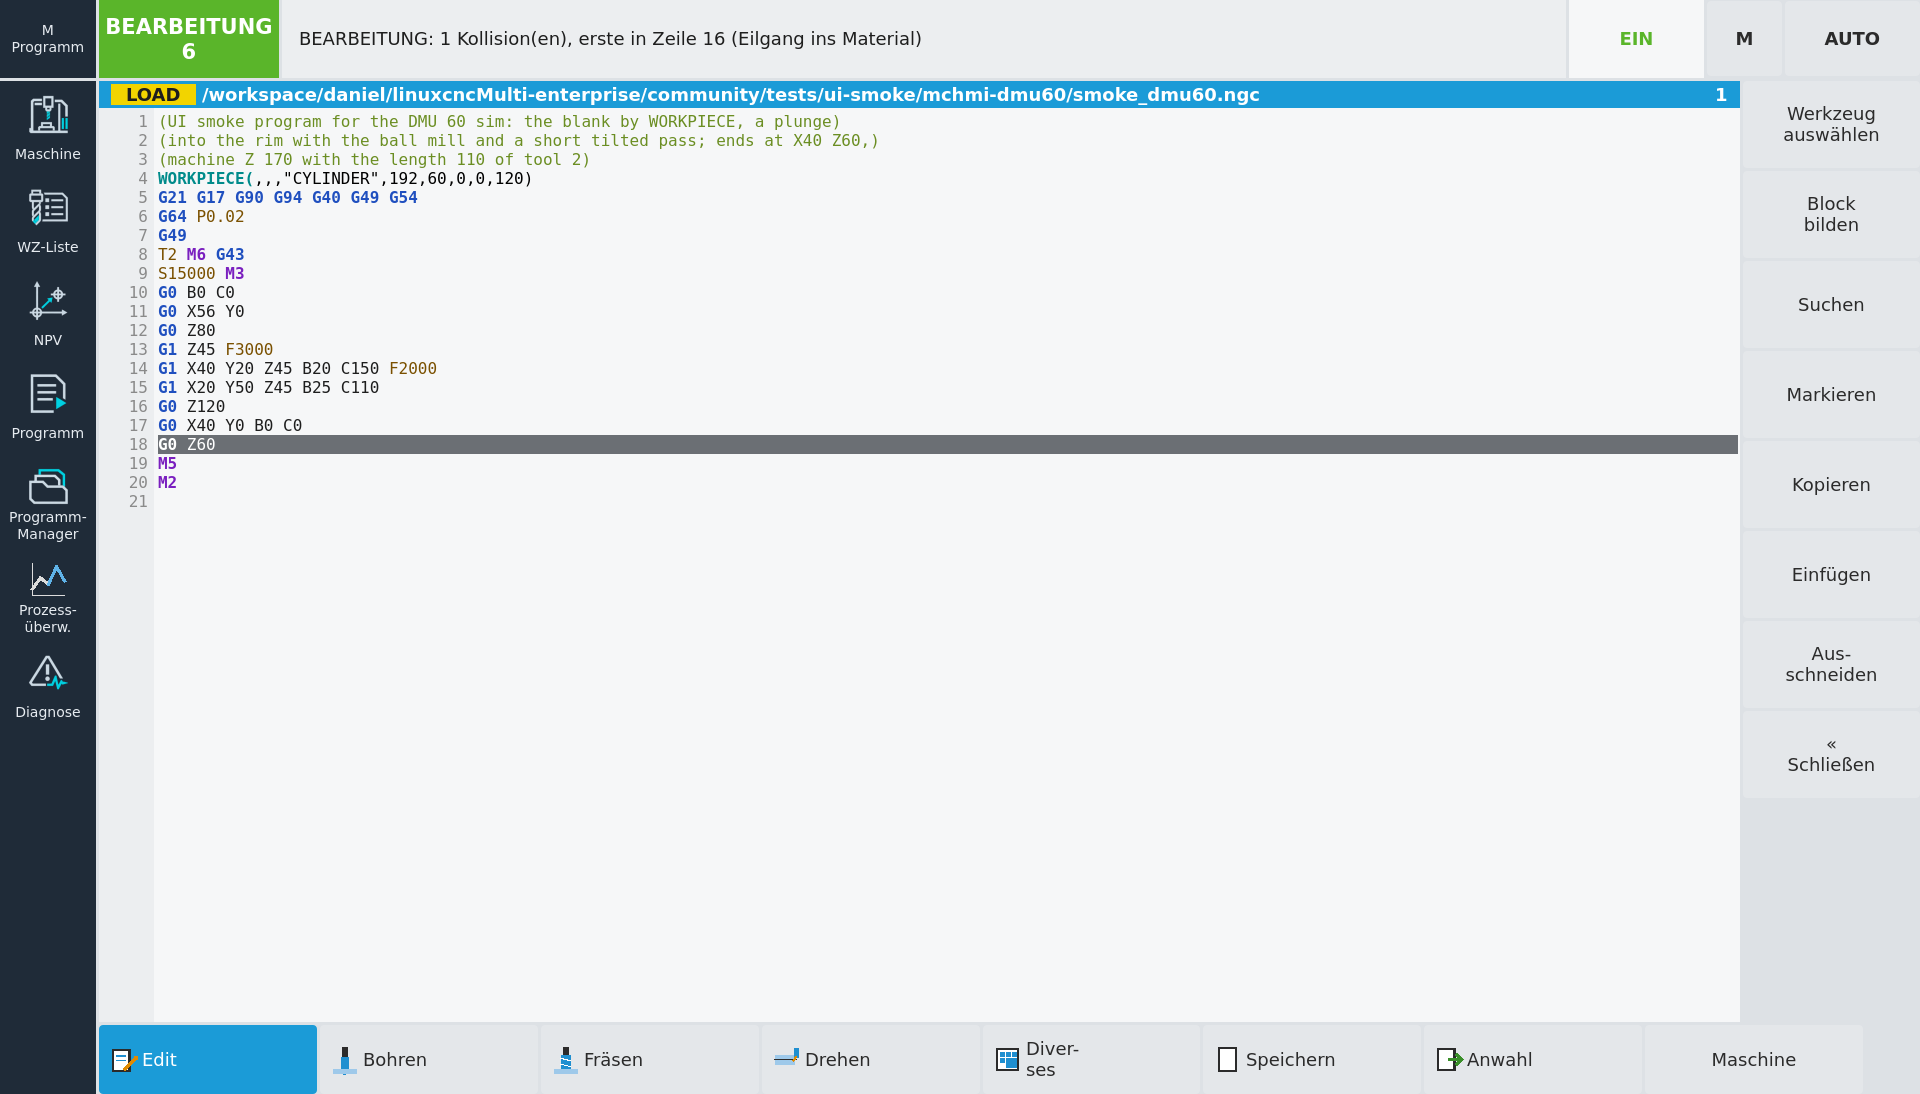 Program editor
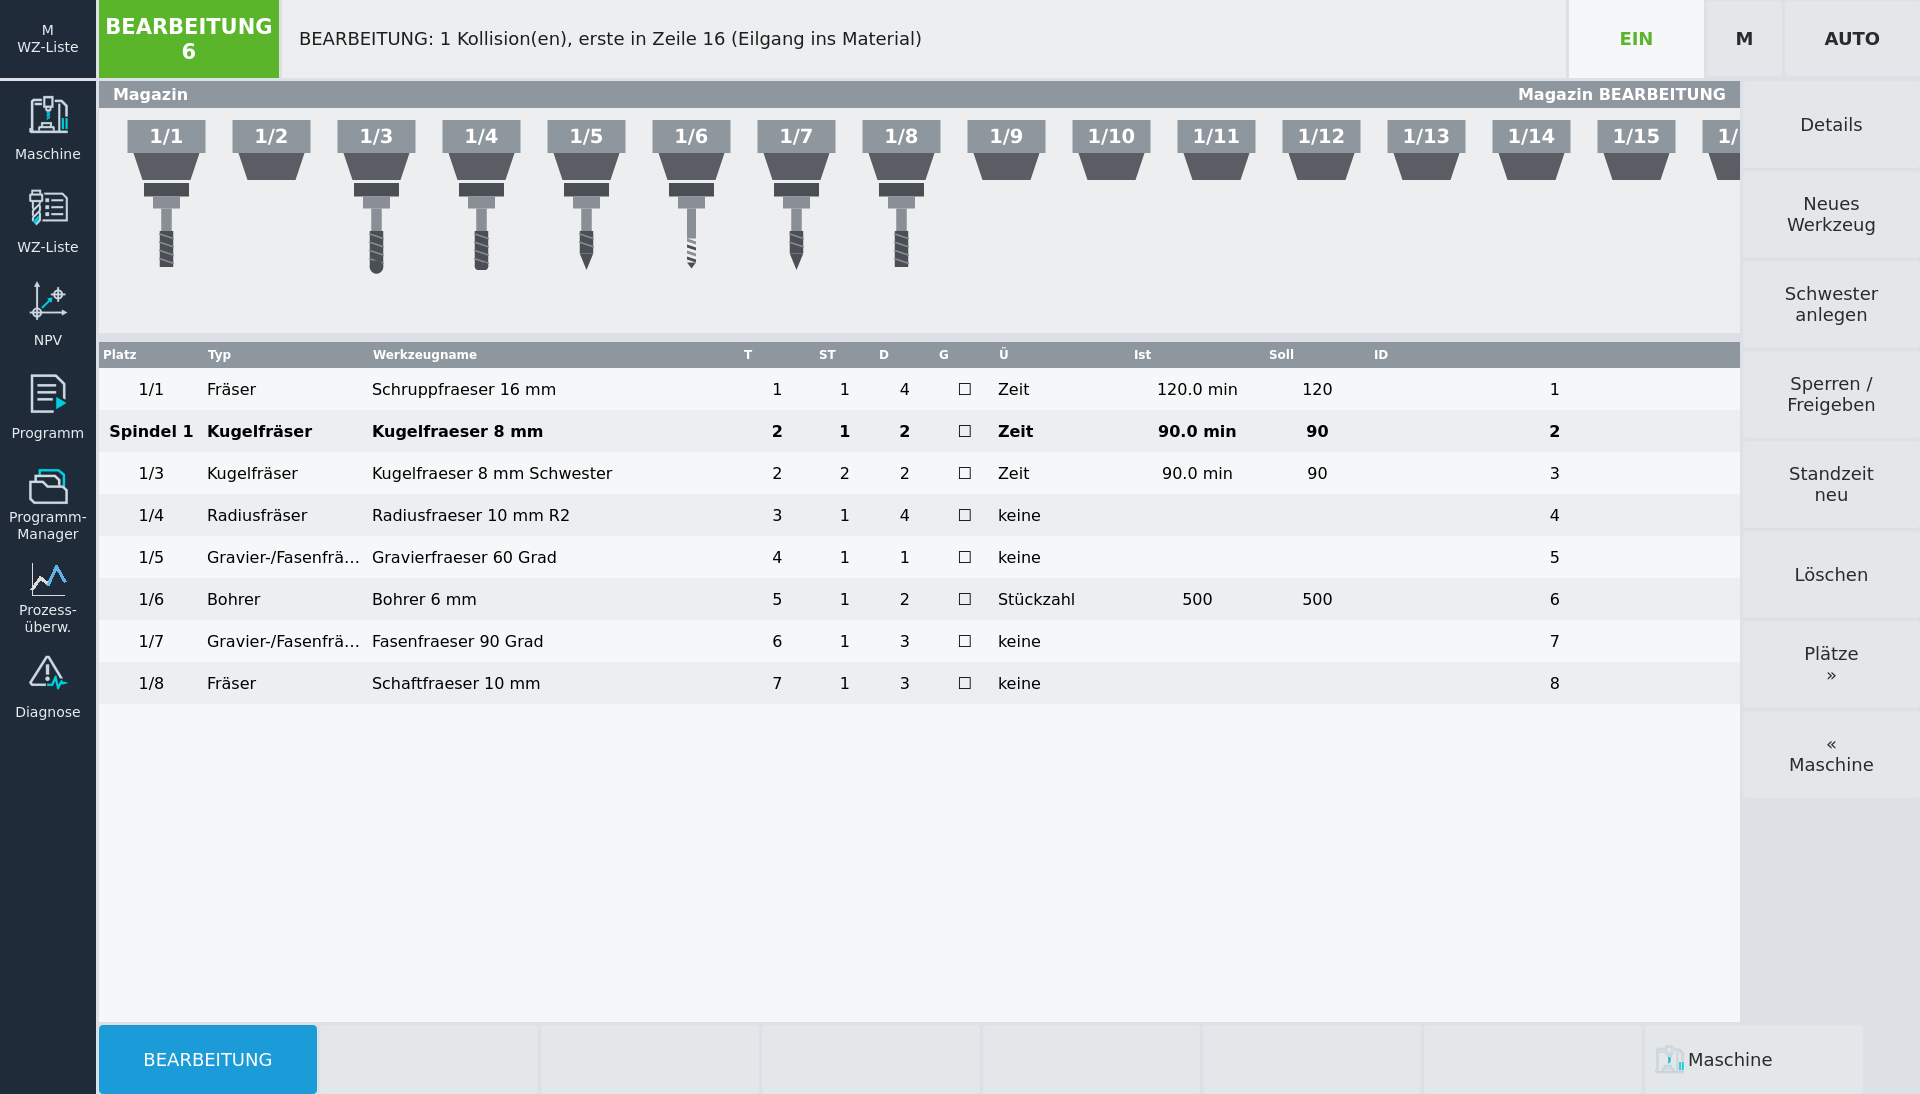 Tool list
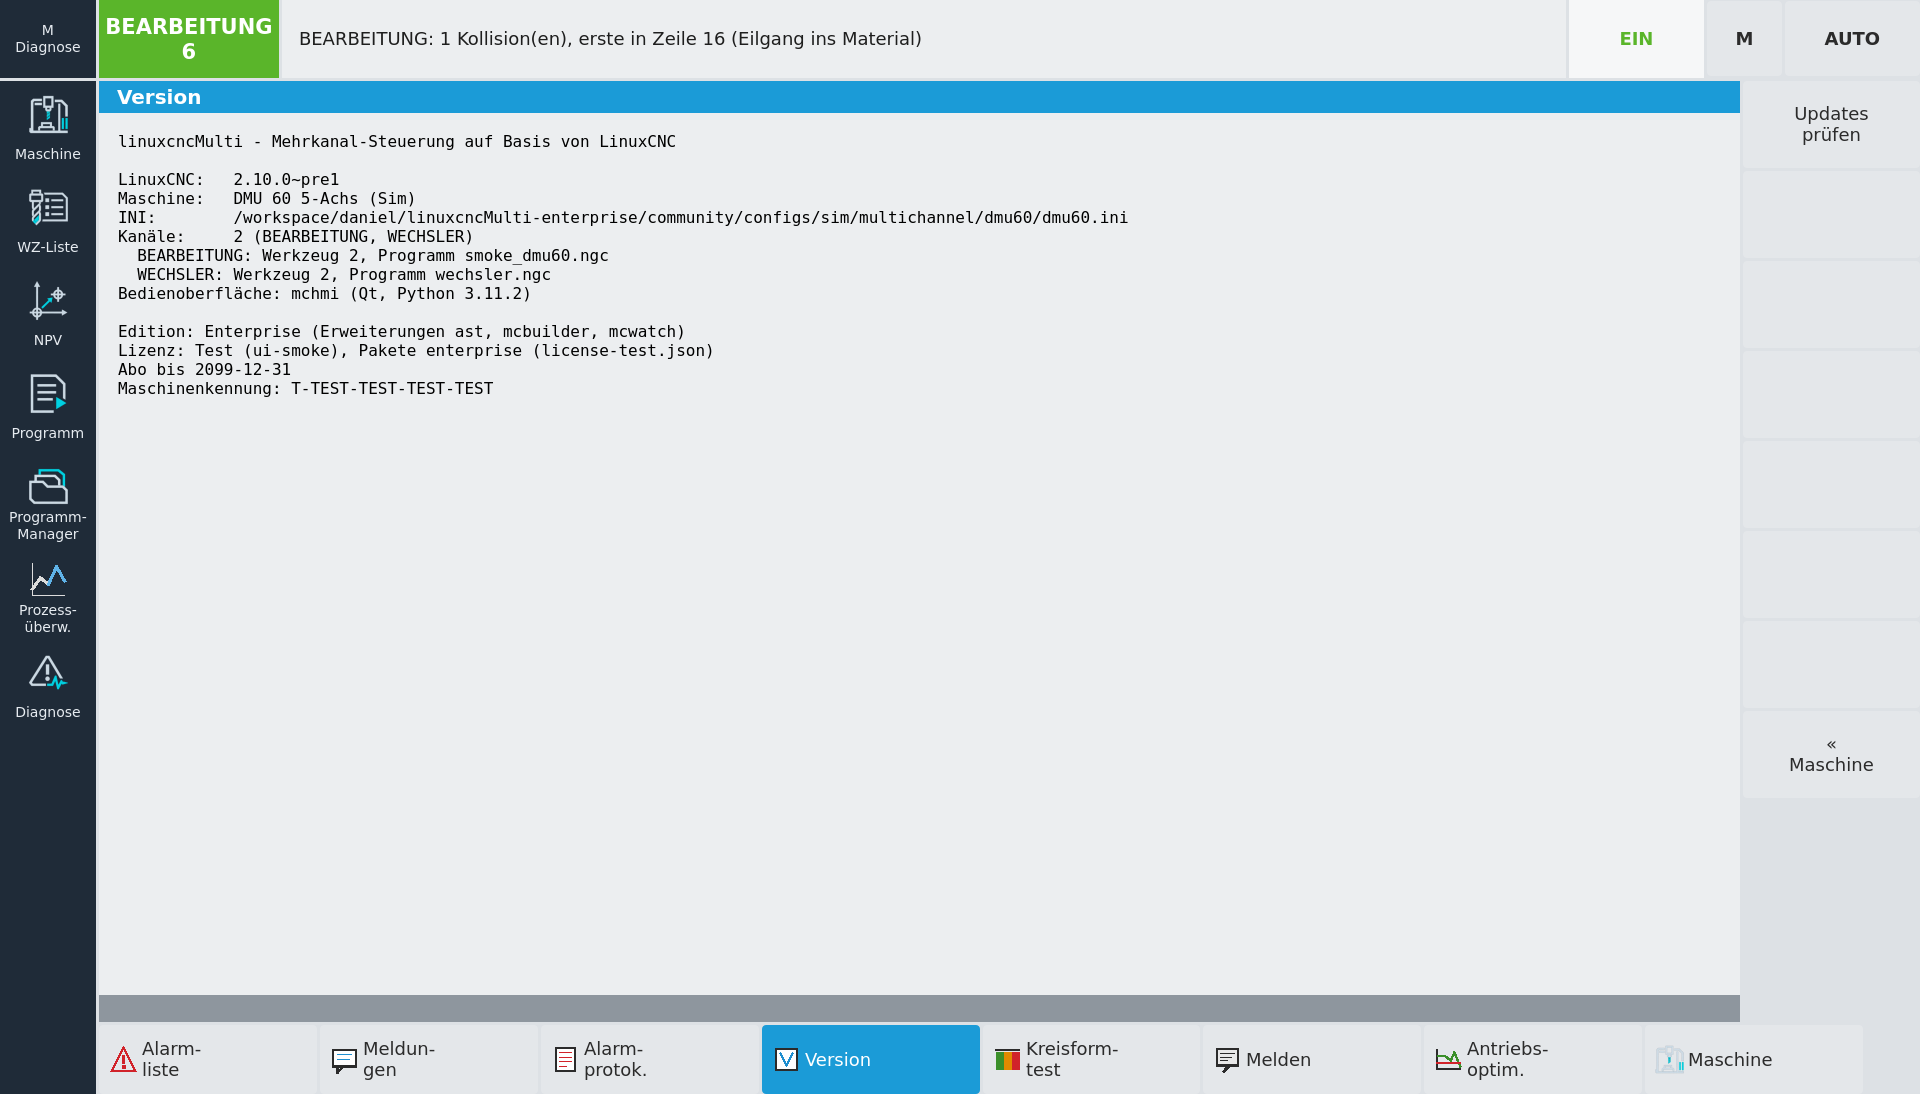 Version page: edition, licence, updates
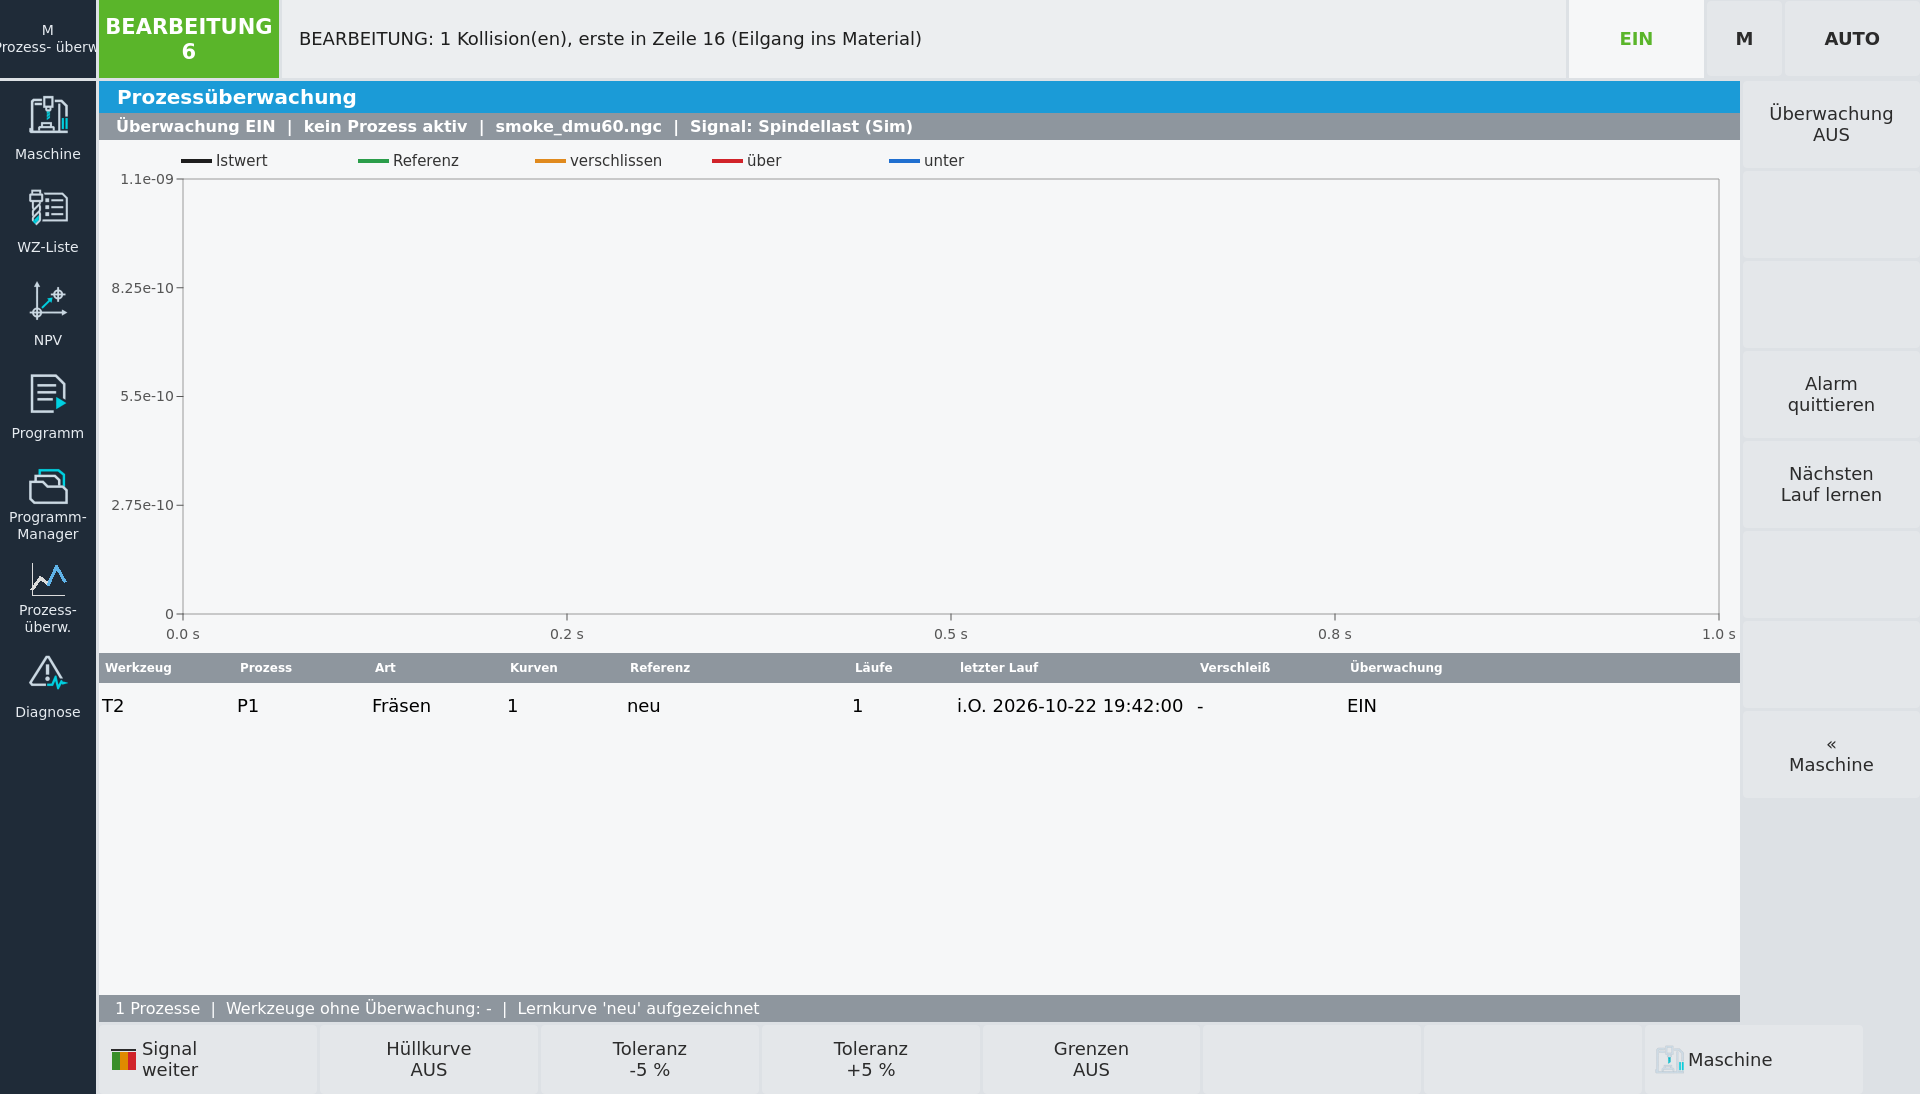 Process monitoring (mcwatch)
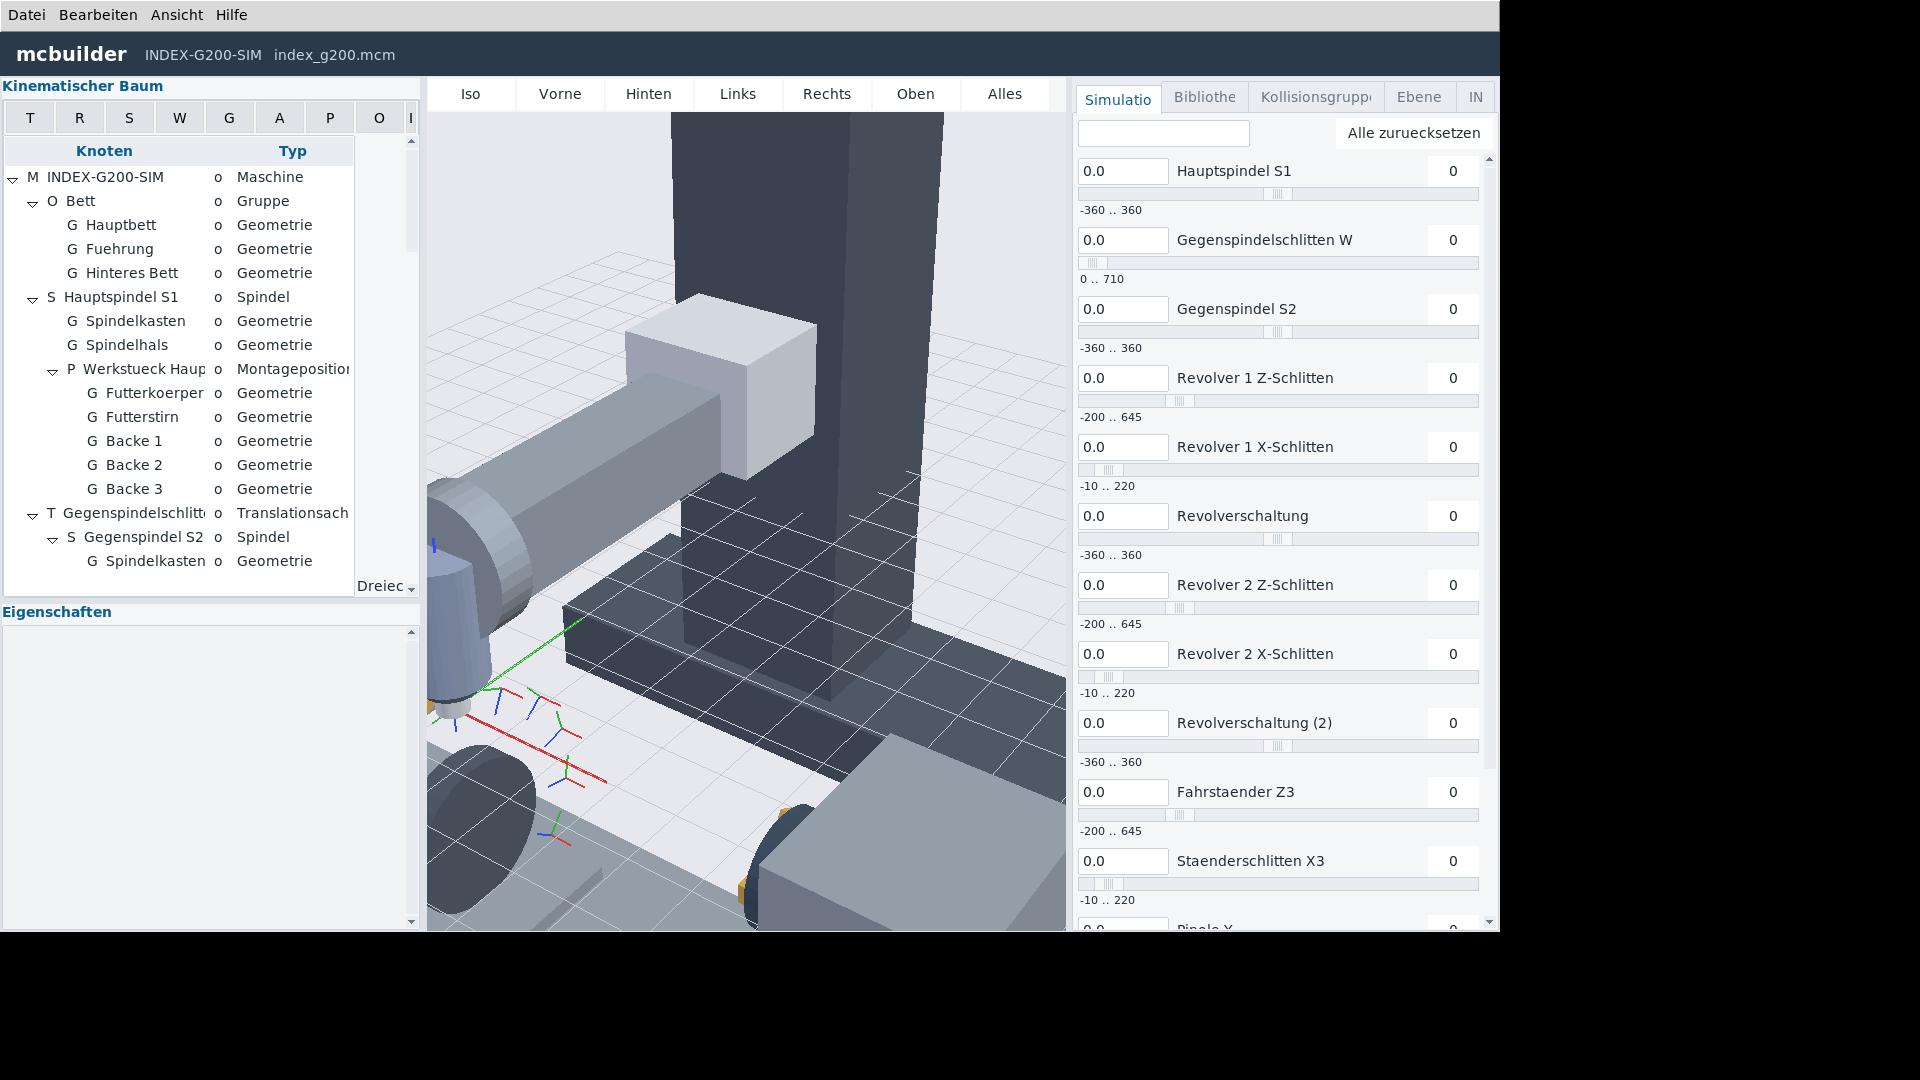
Machine Builder
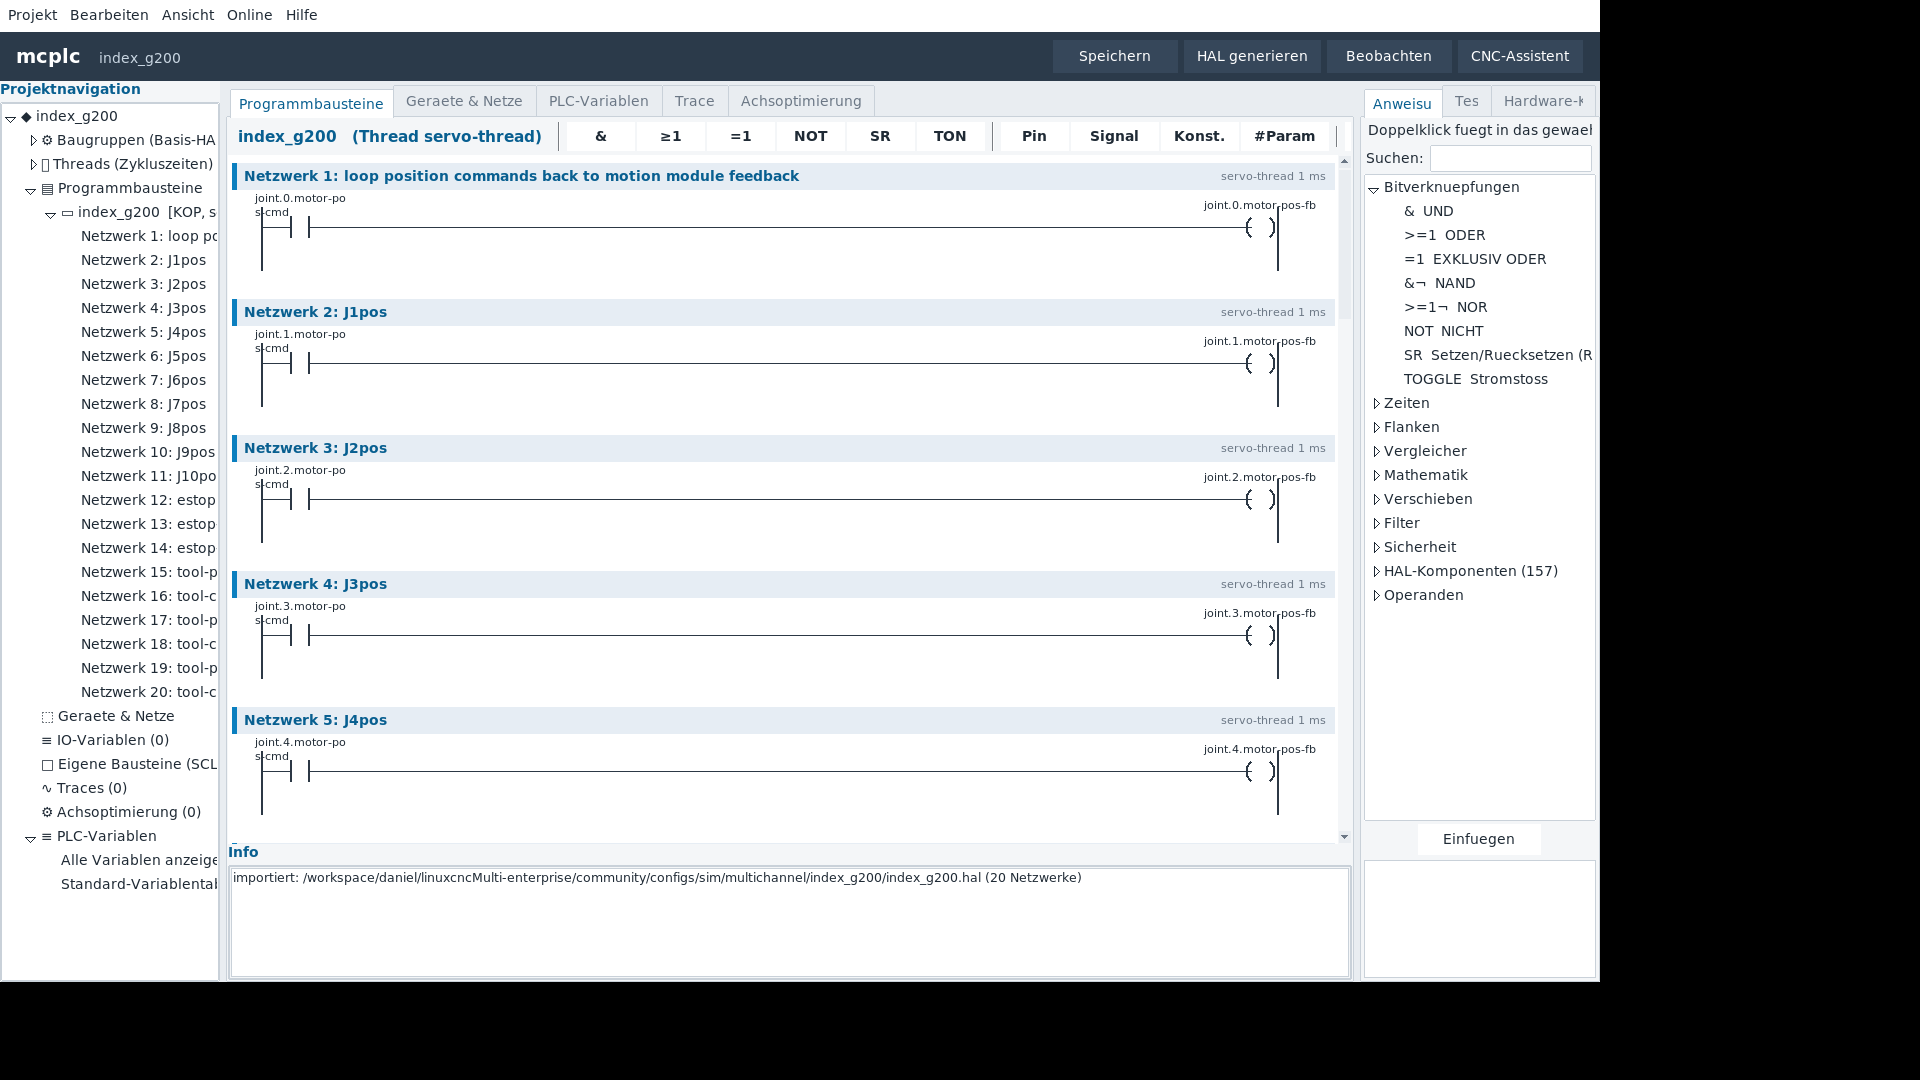
mcplc: HAL programming (KOP/FUP/SCL)
Two-channel simulation (mchmi)
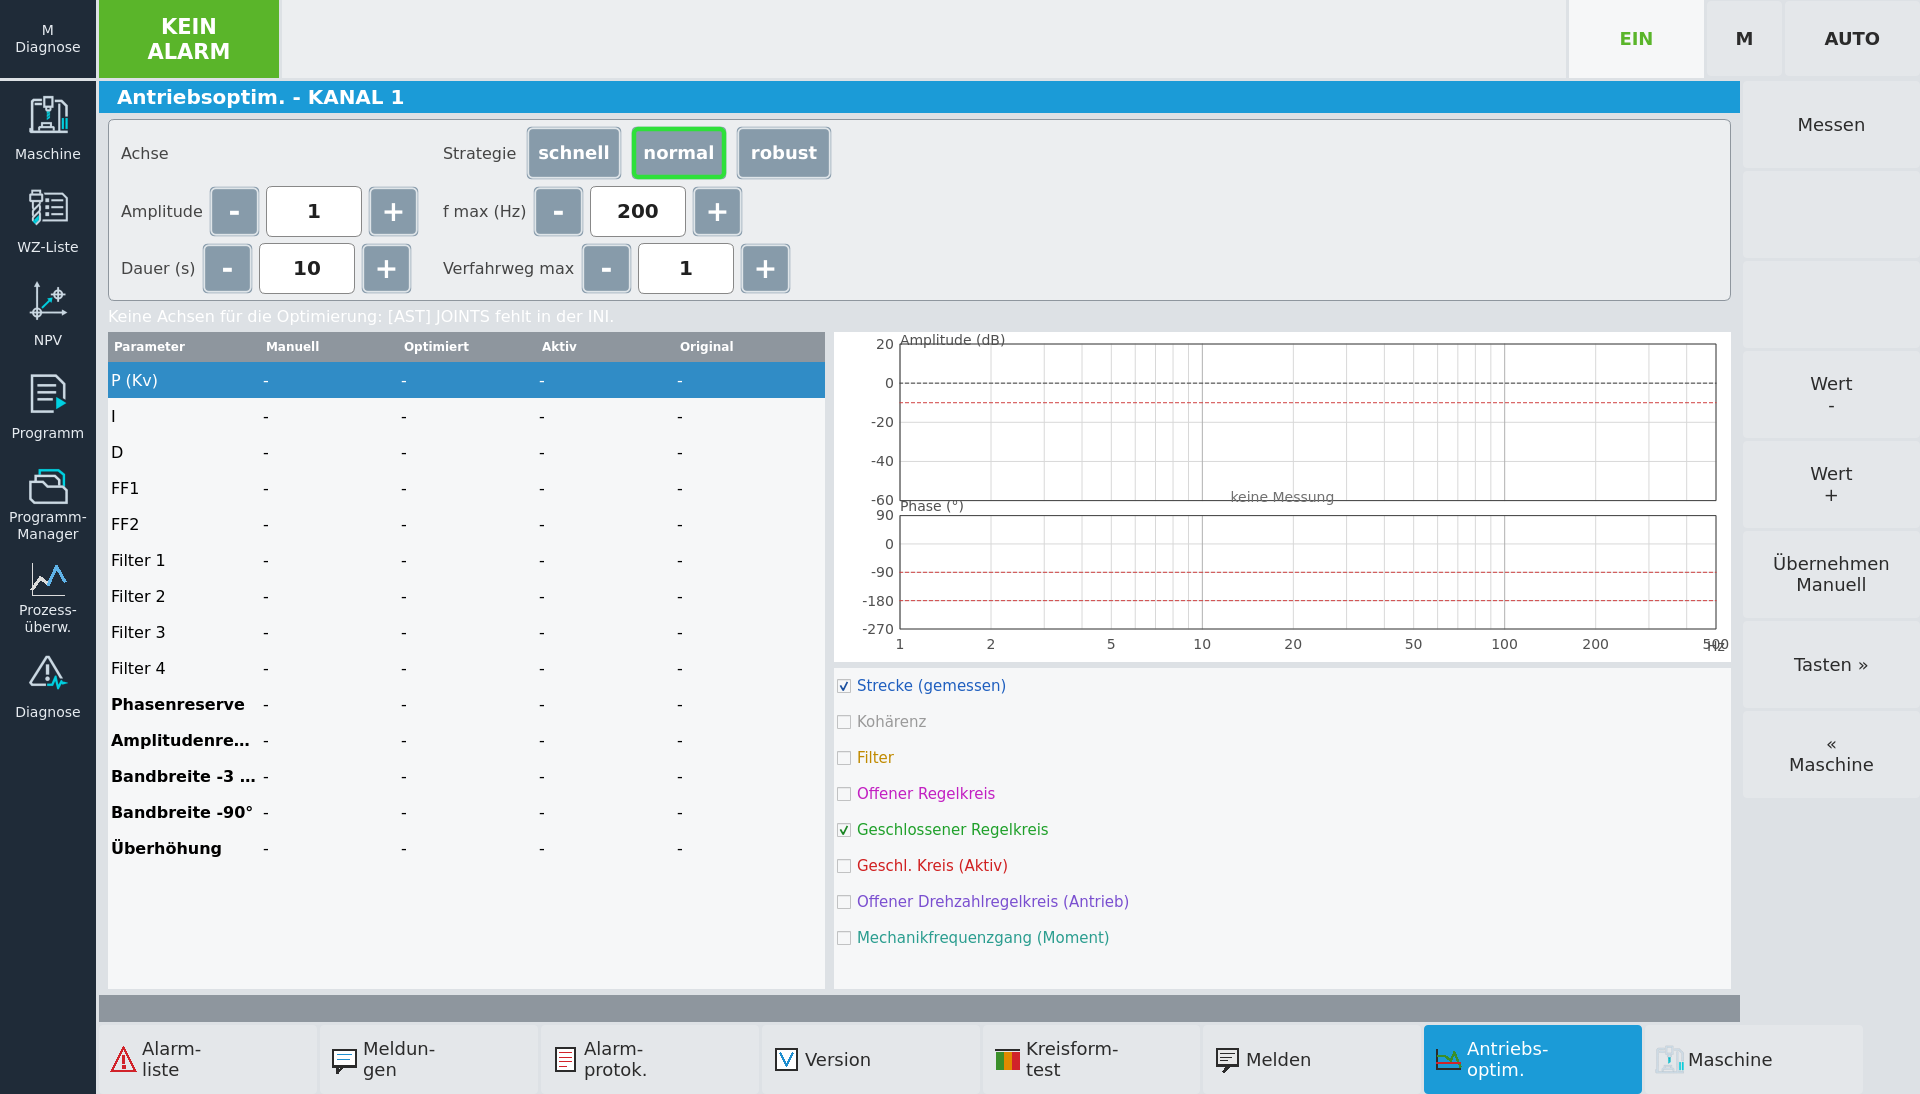 Auto Servo Tuning page
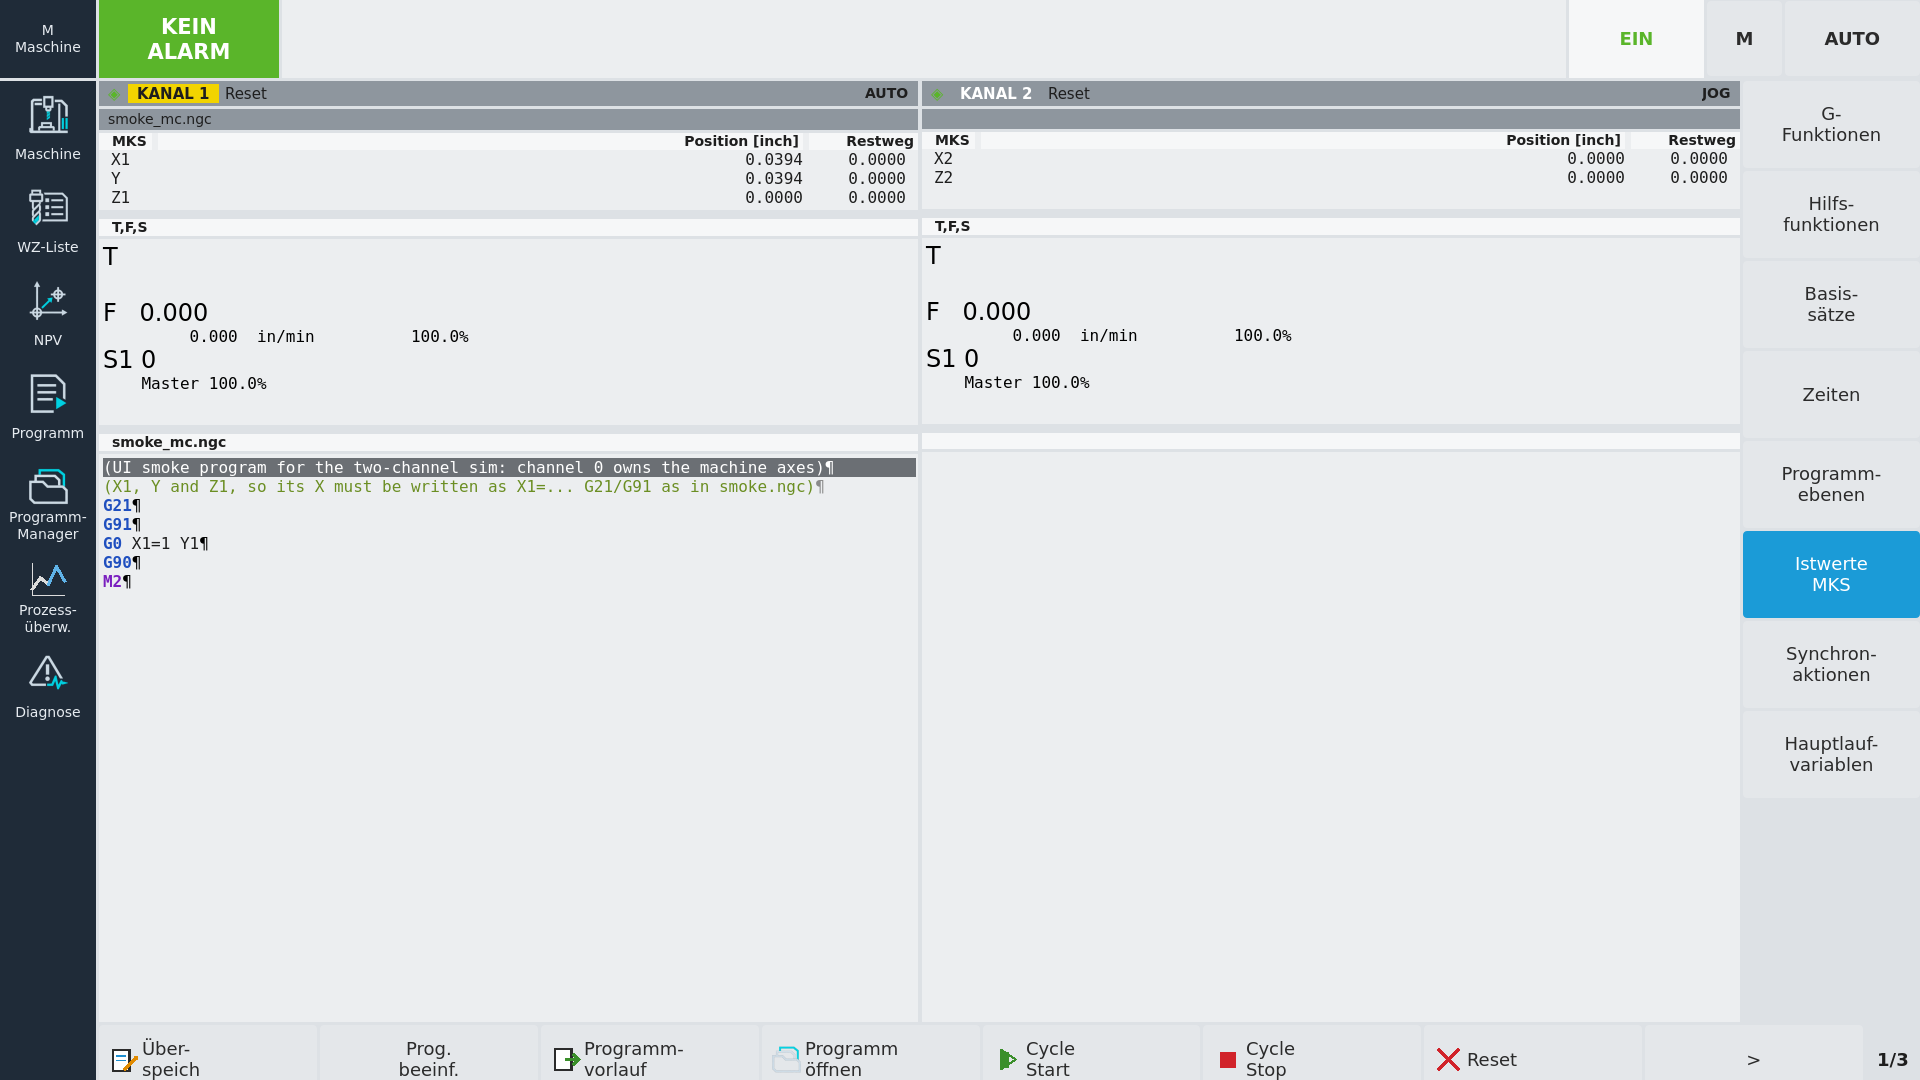 After the smoke program: the result
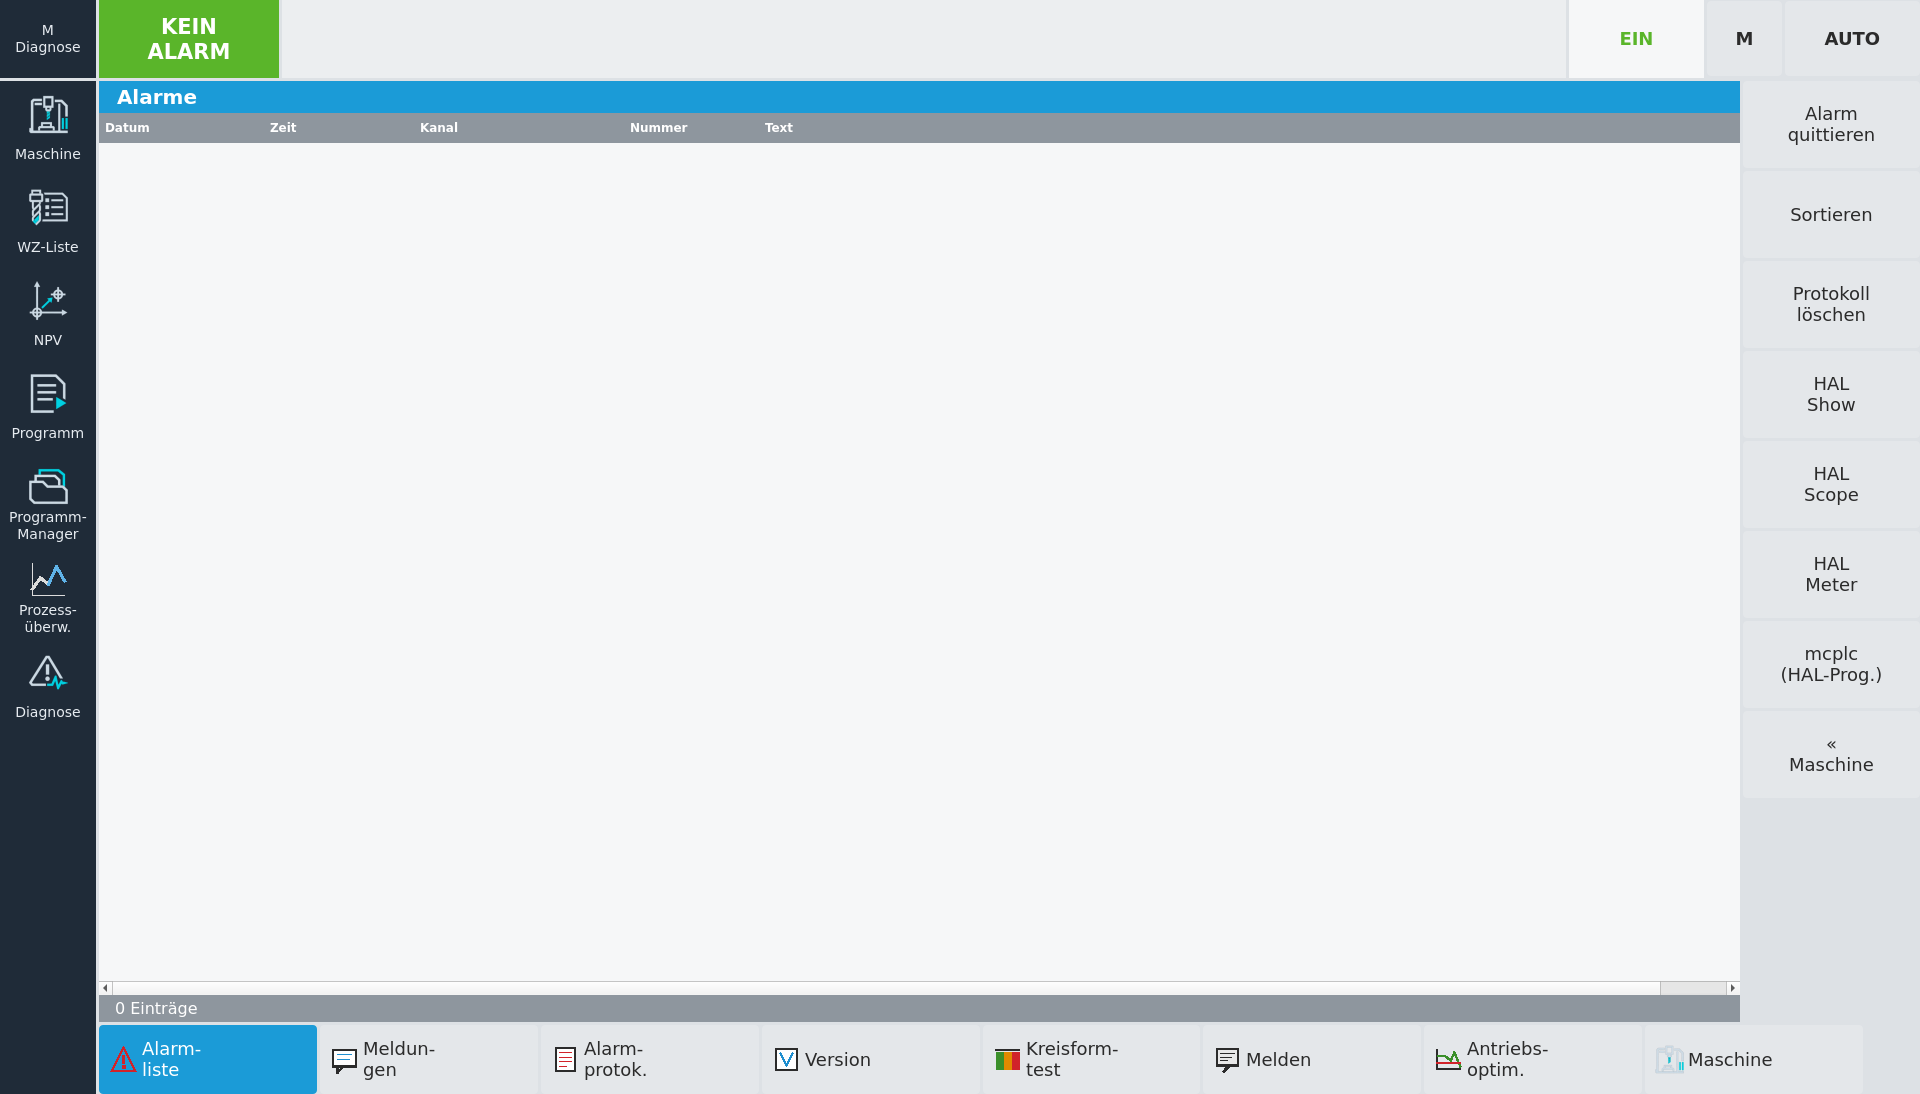 Diagnosis: alarms and log
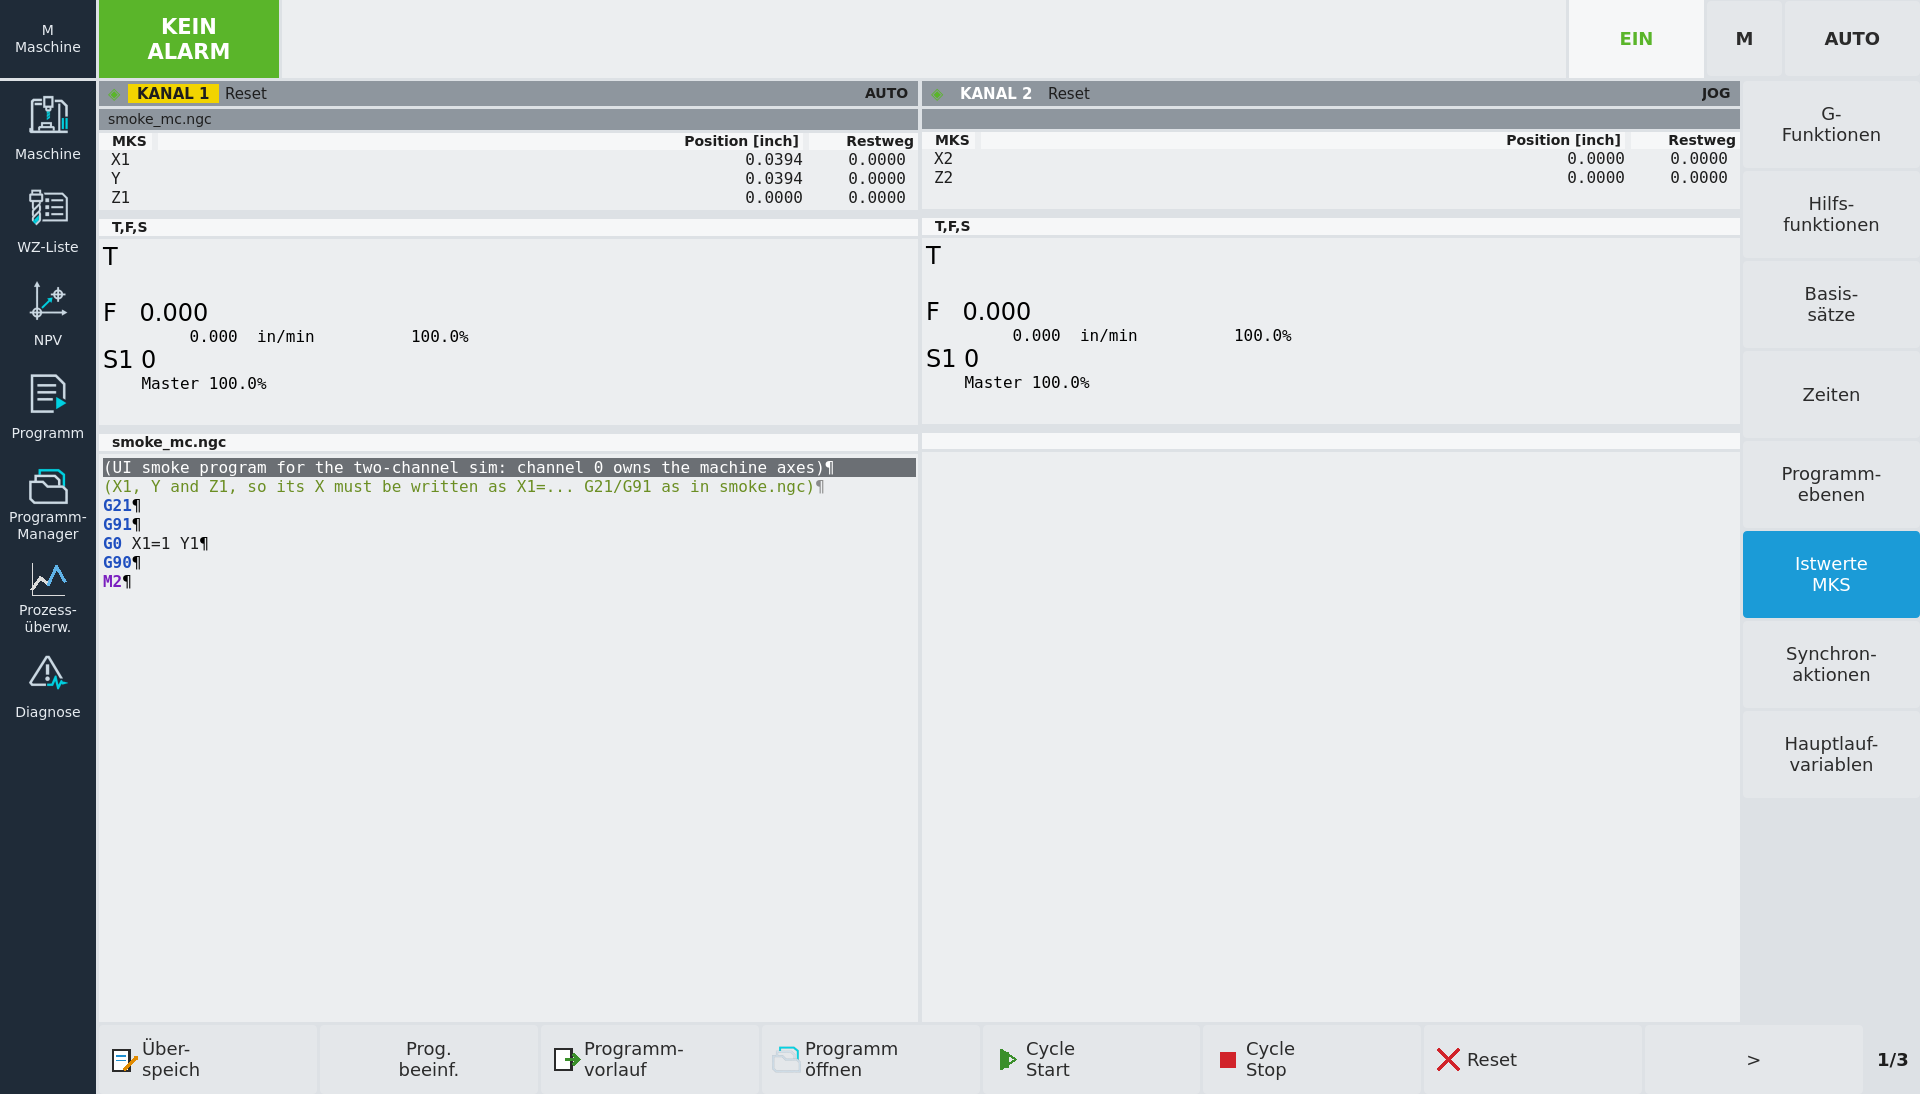 Machine area: channels, positions, program, 3D model
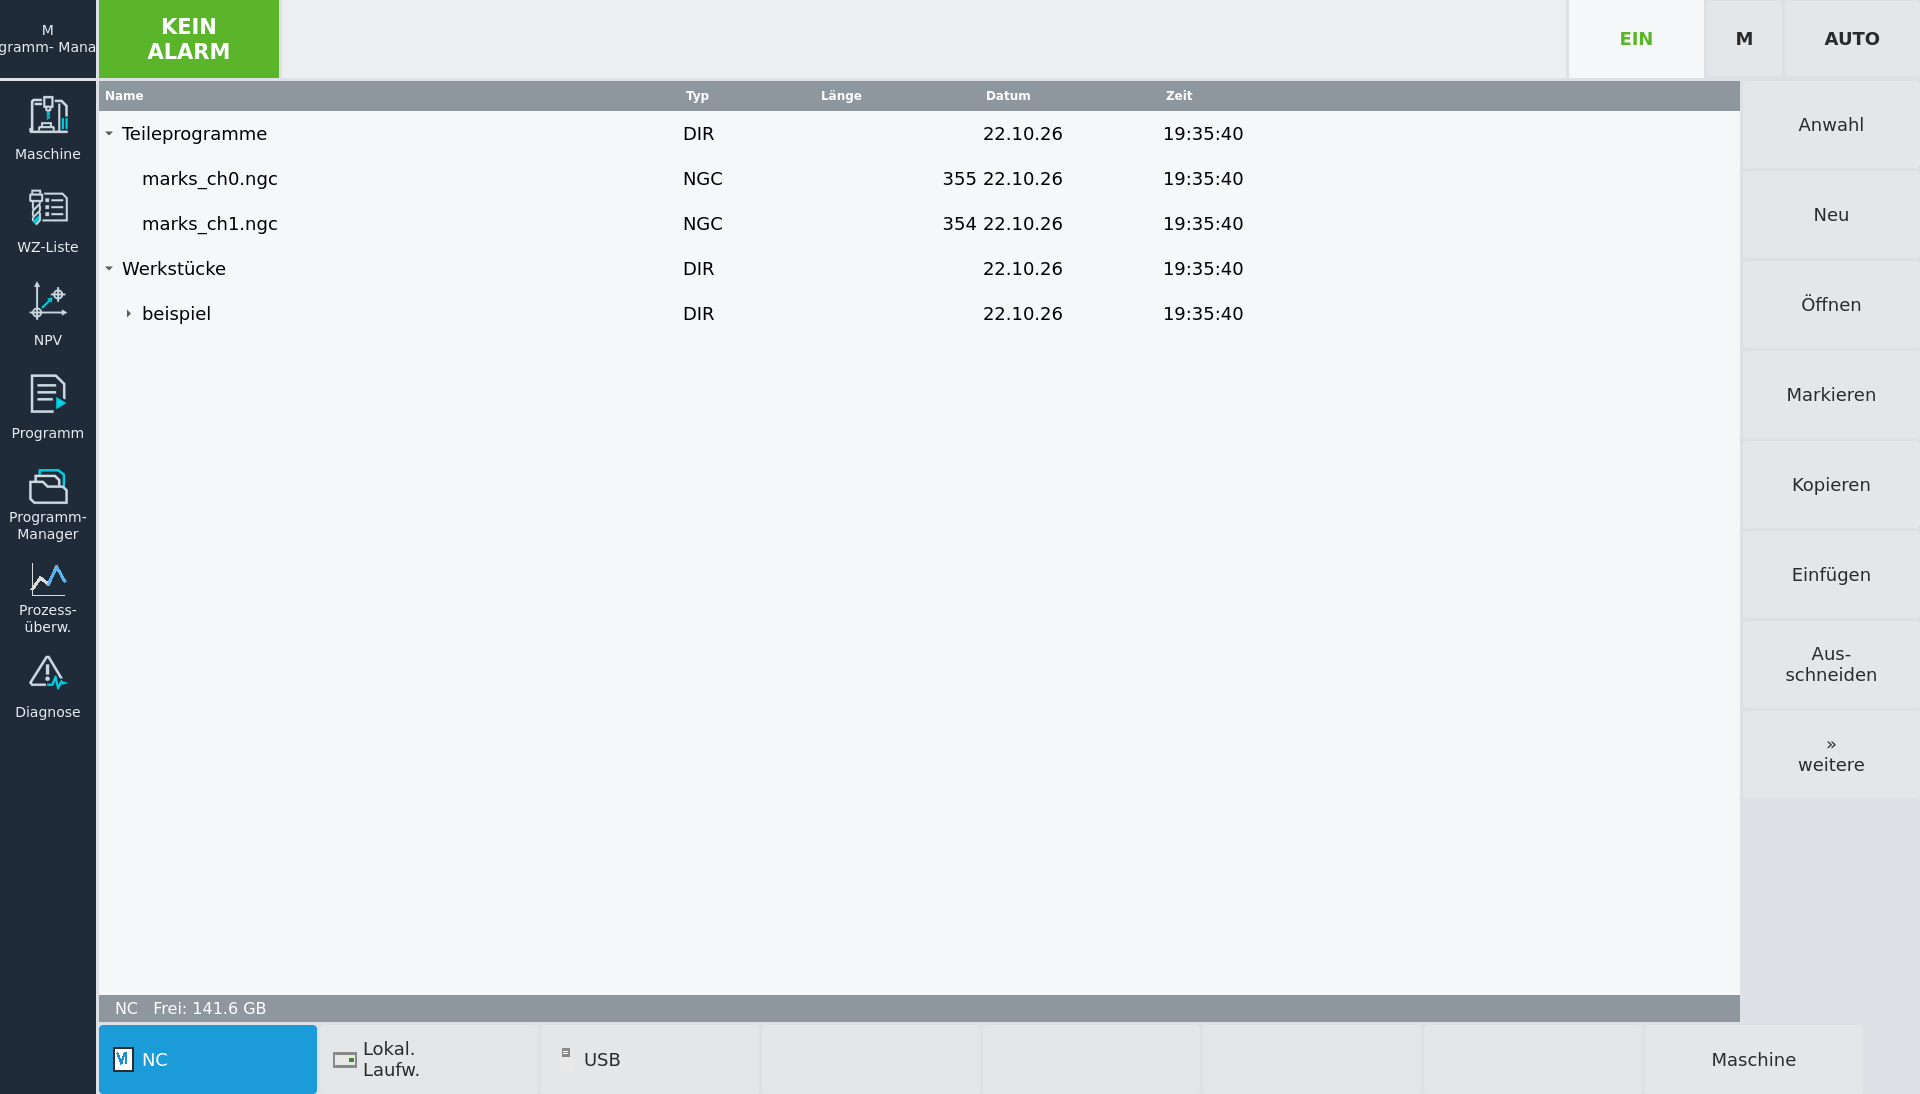 Program manager
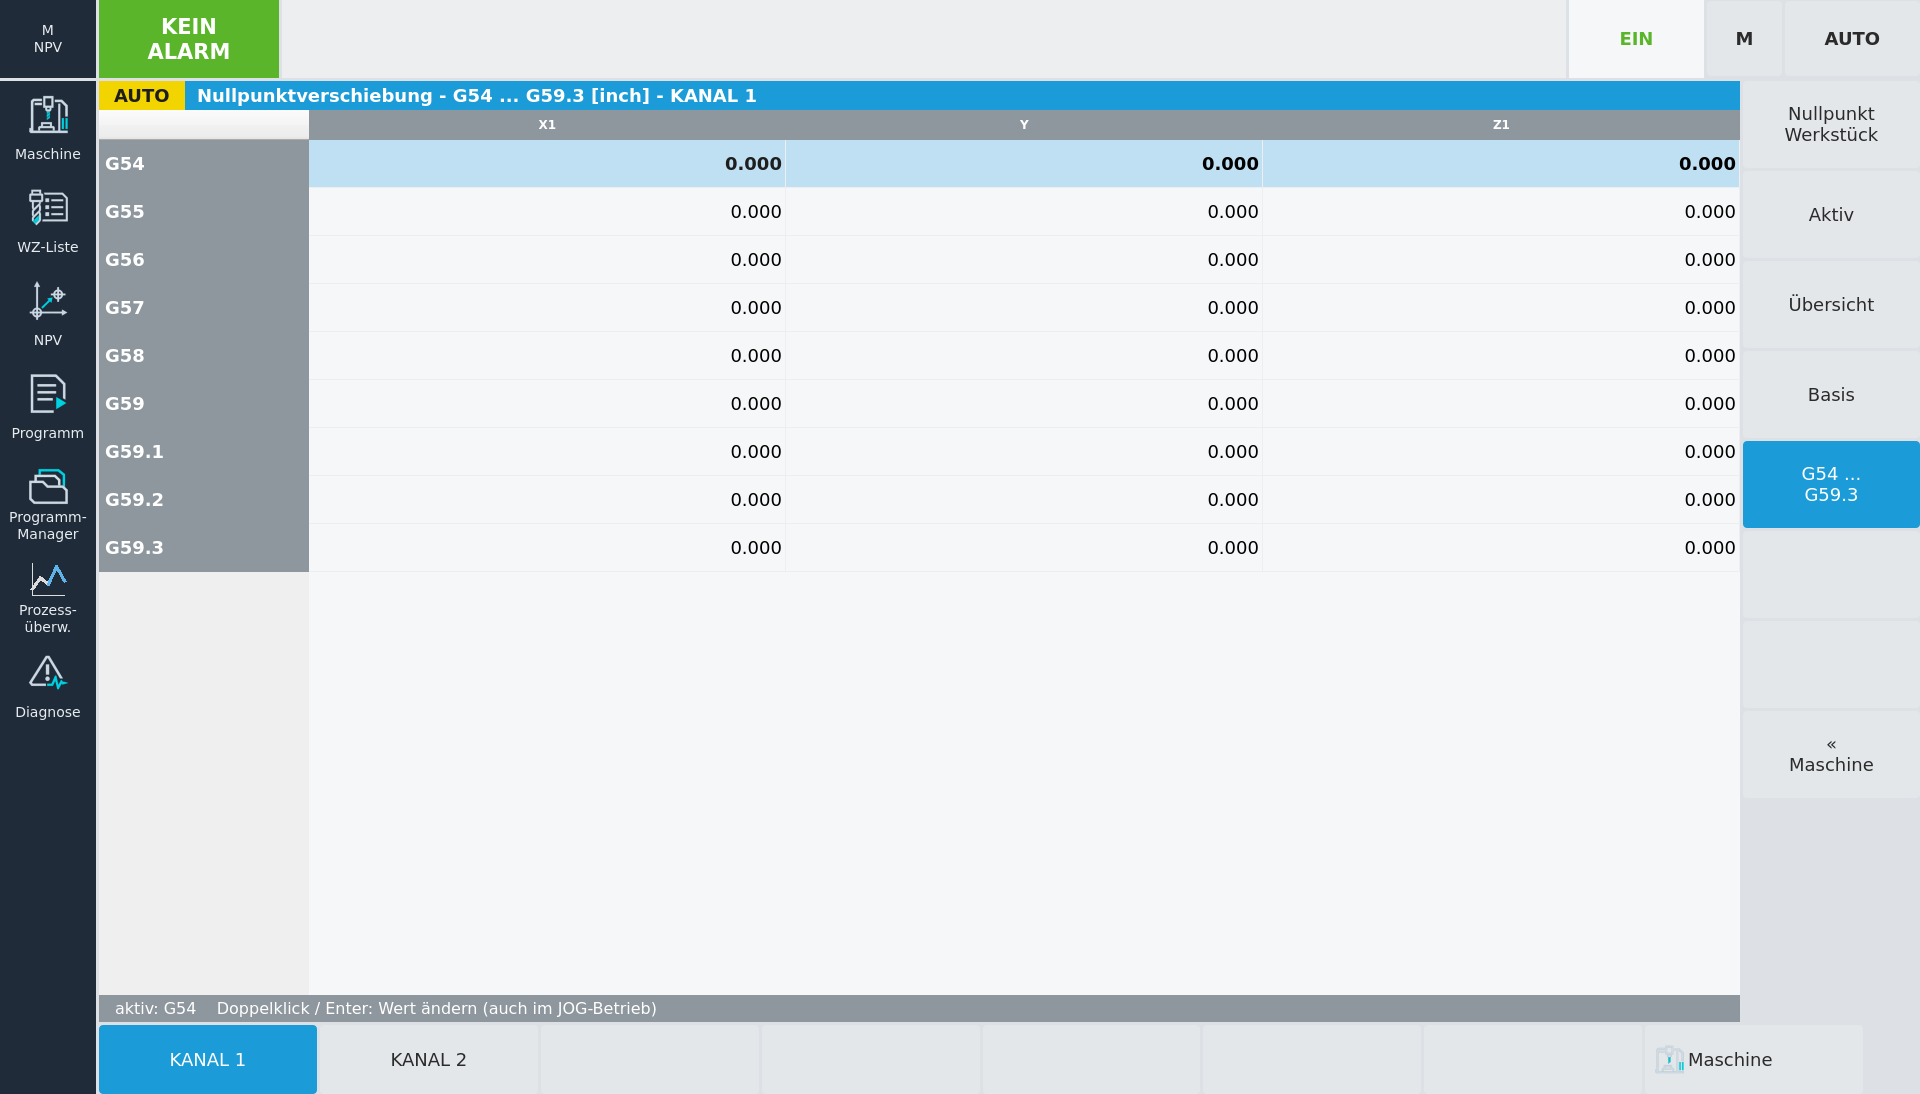 Work offsets
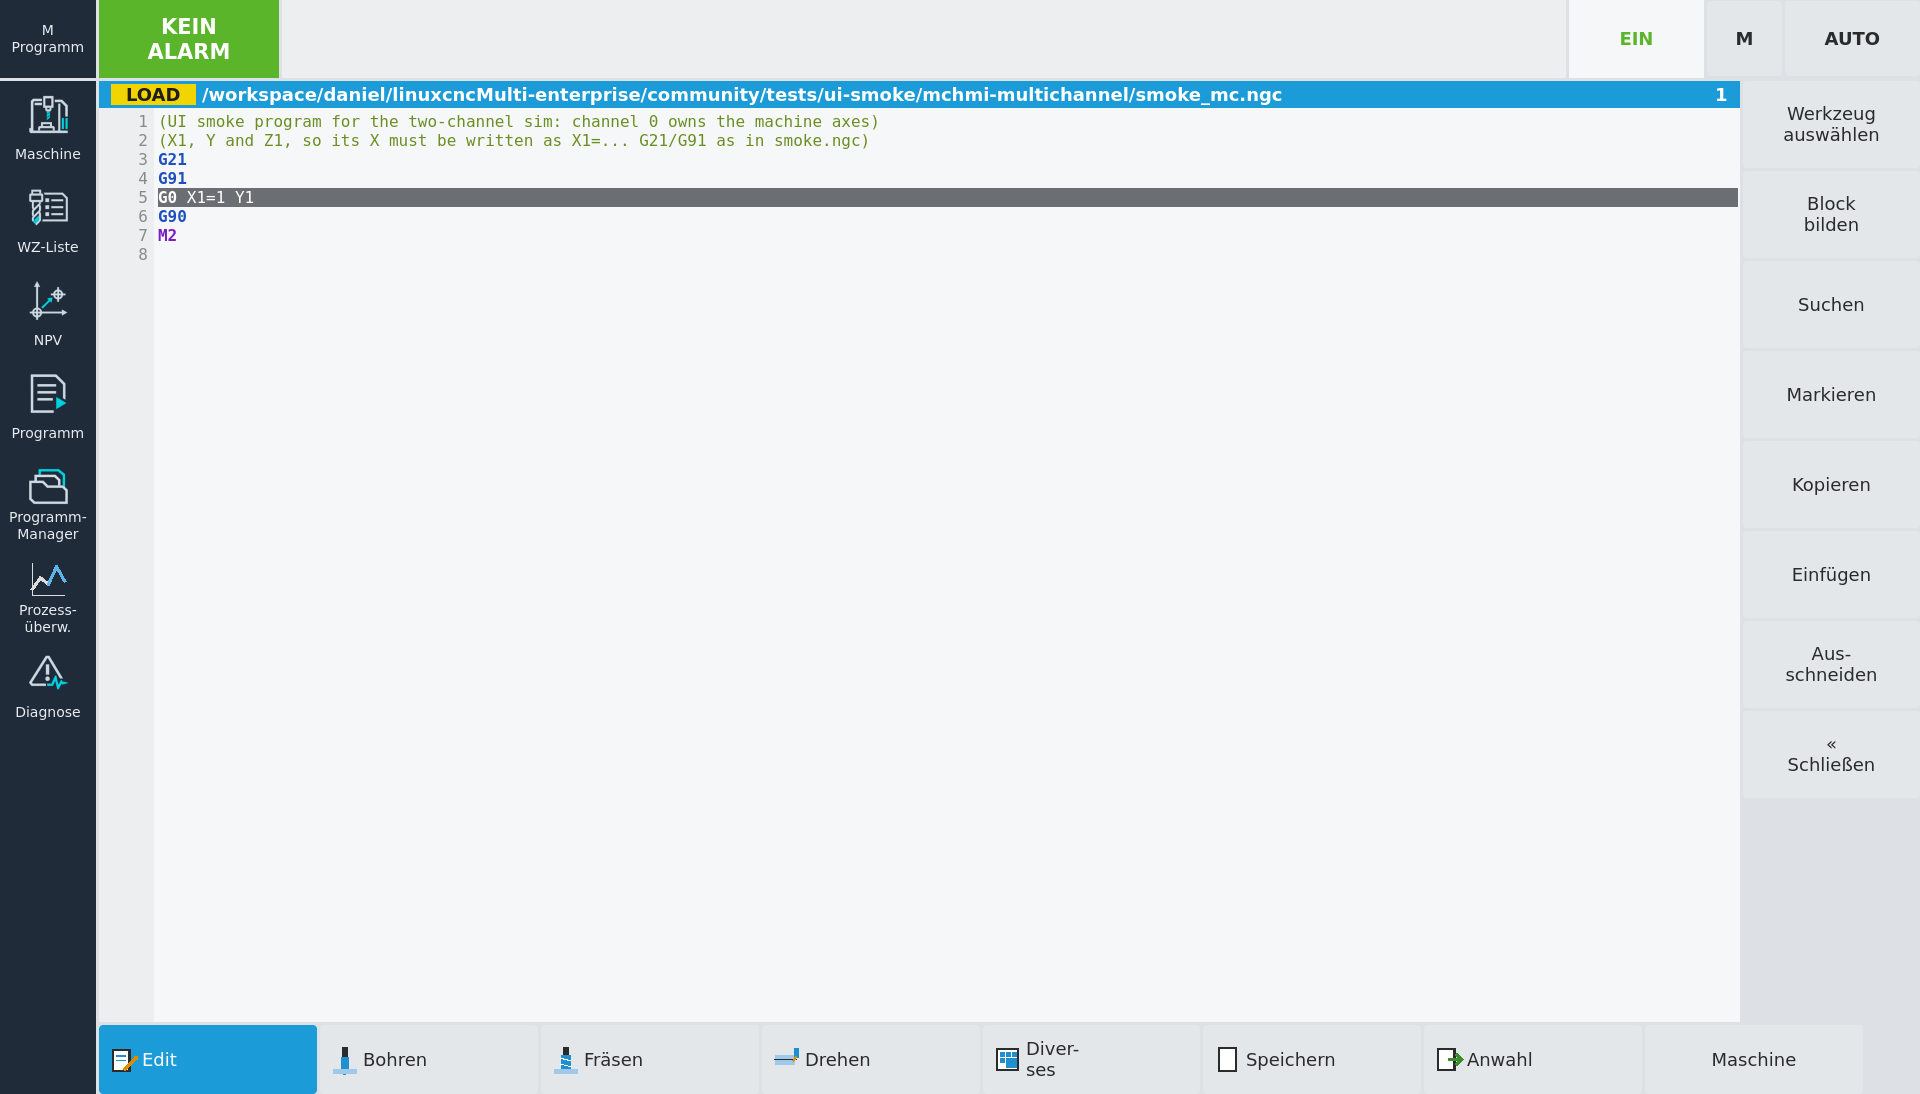 Program editor
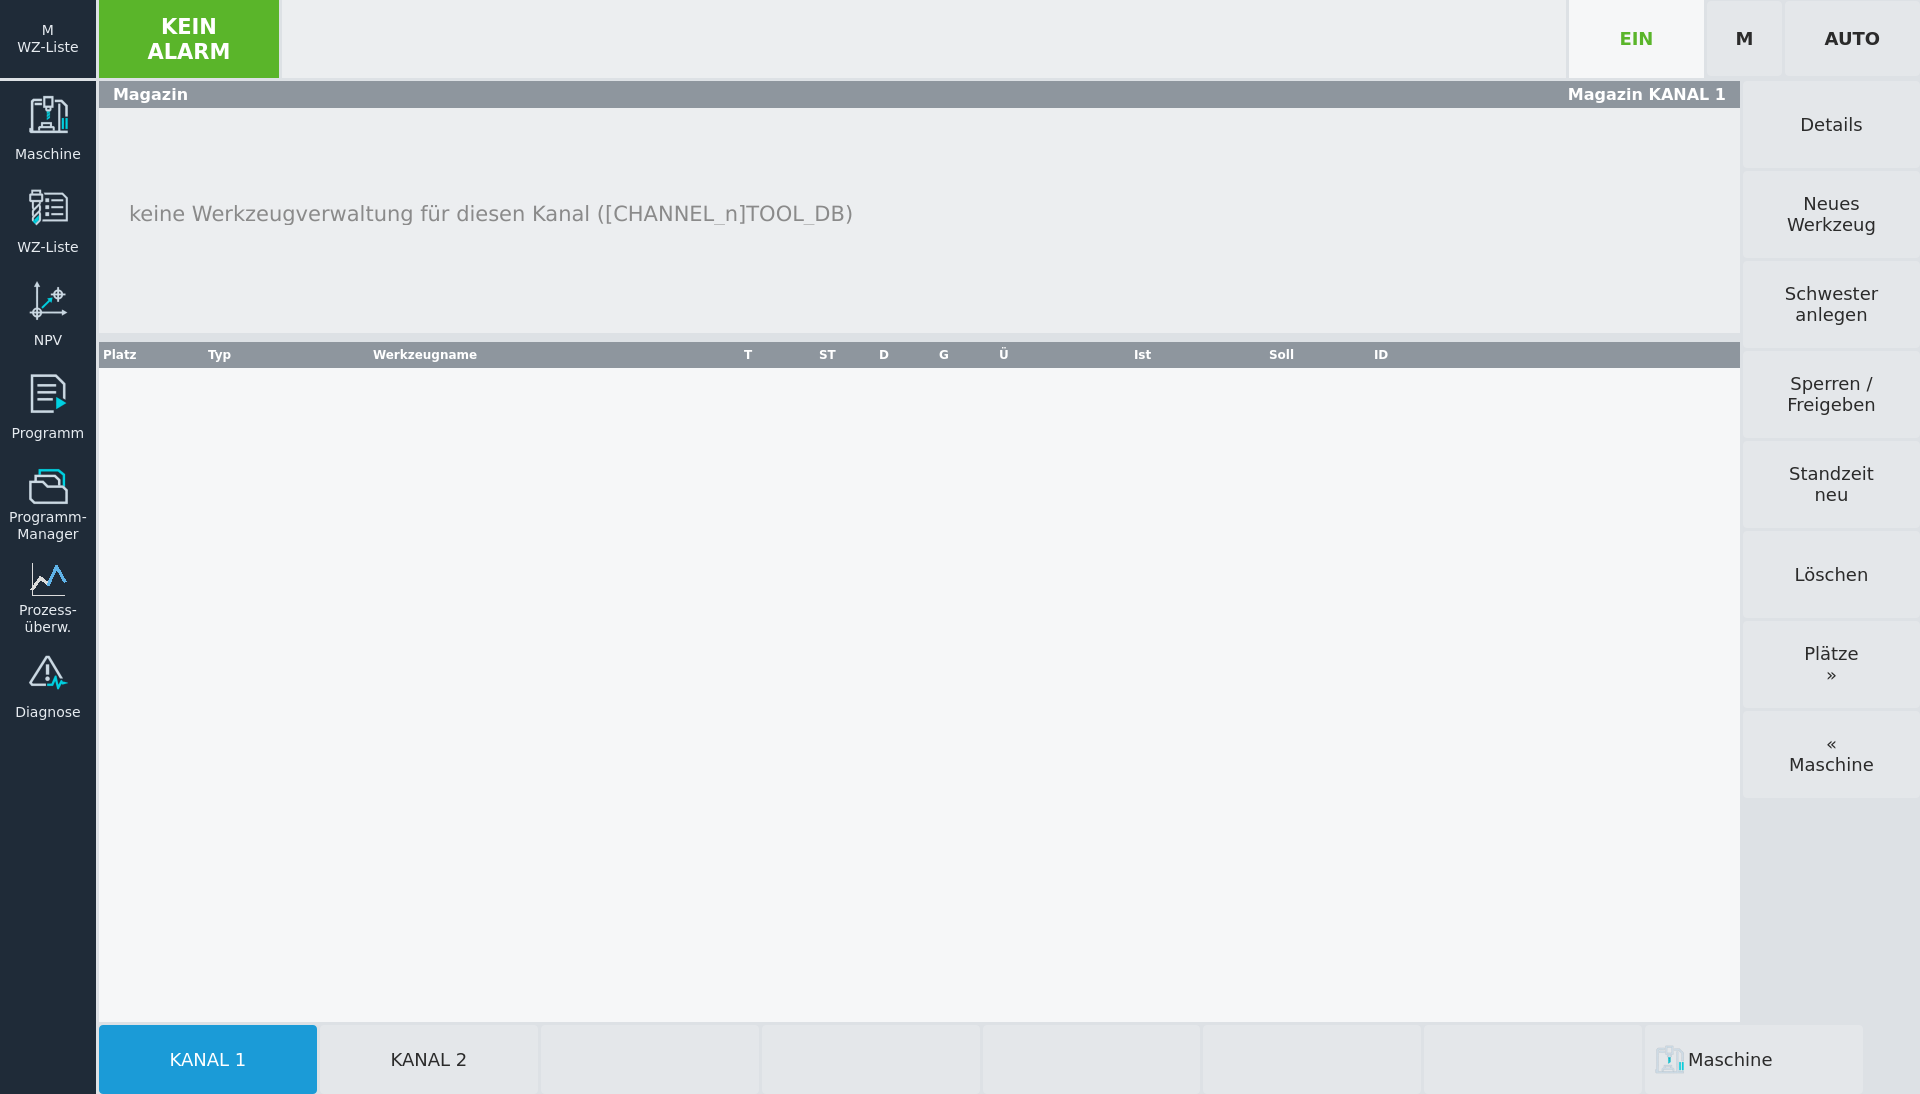 Tool list
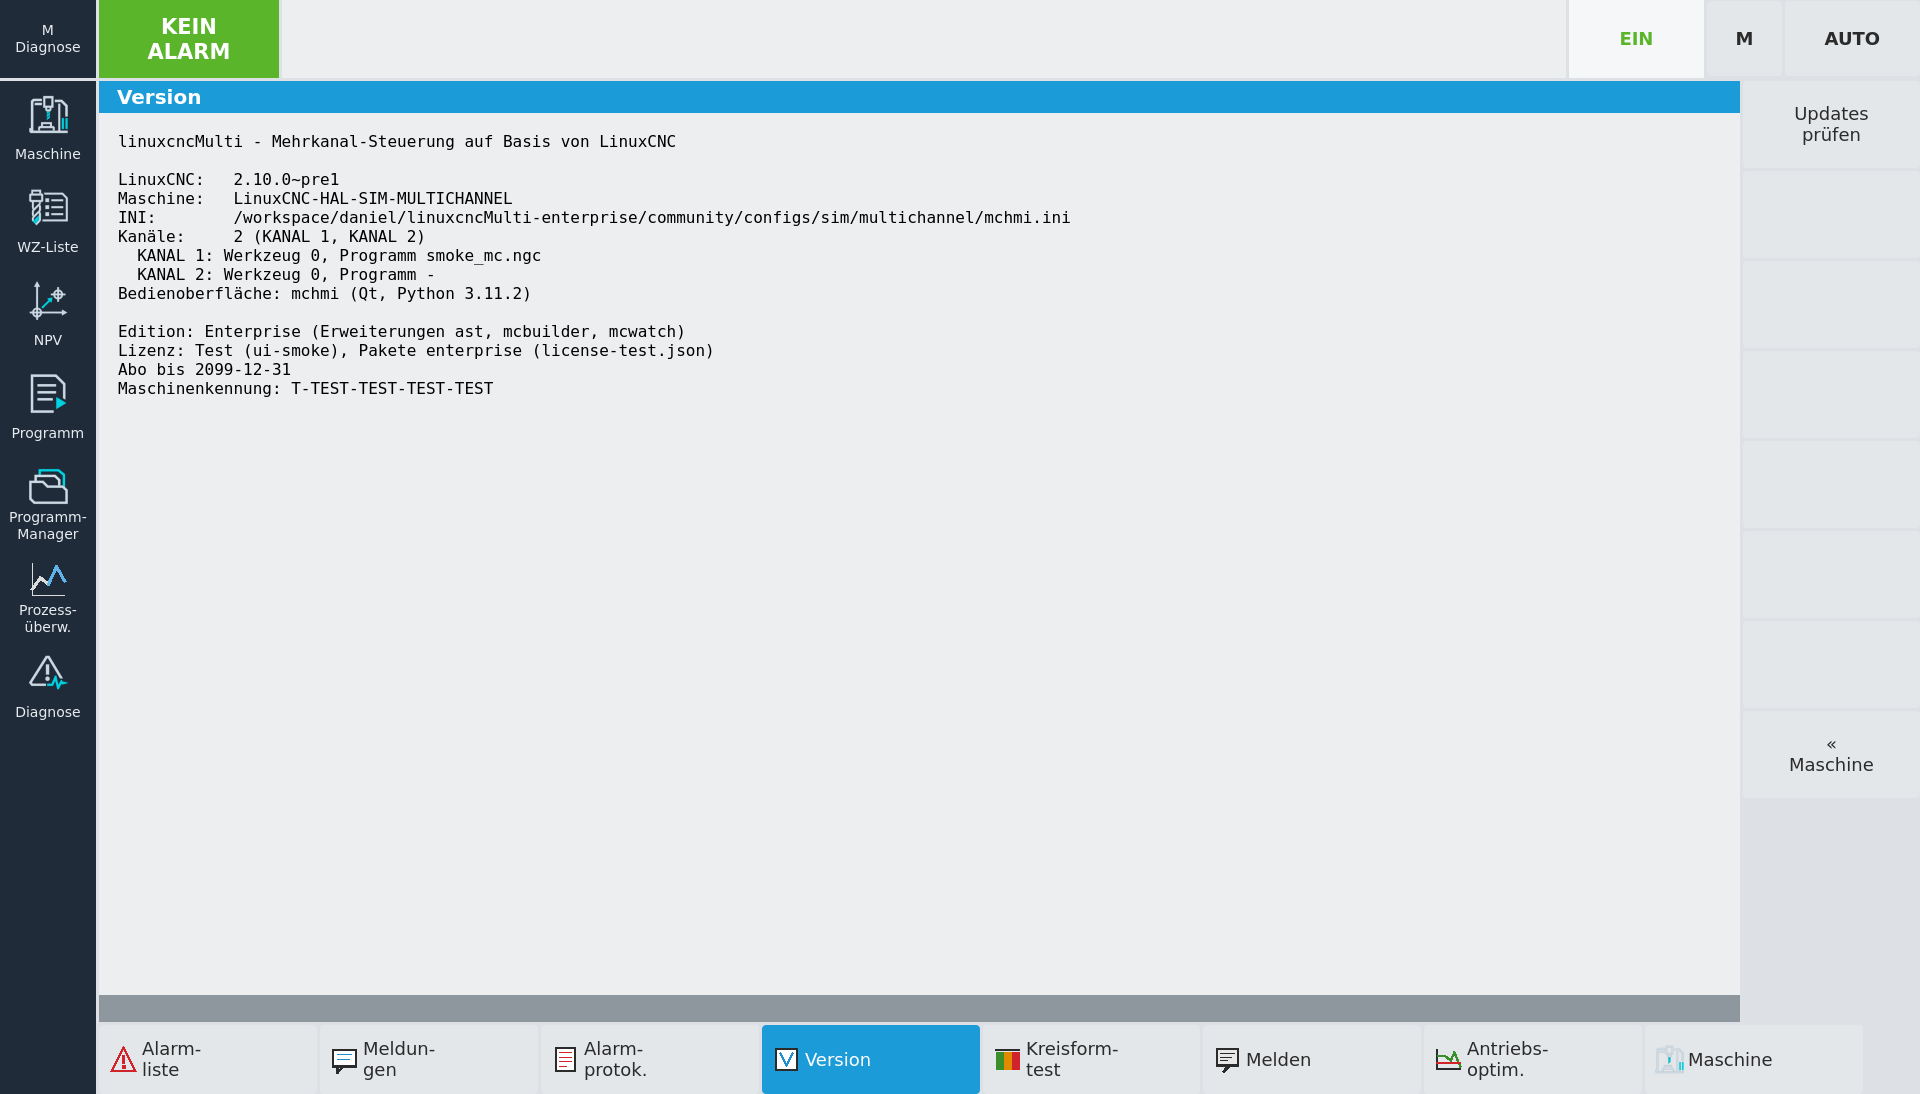 Version page: edition, licence, updates
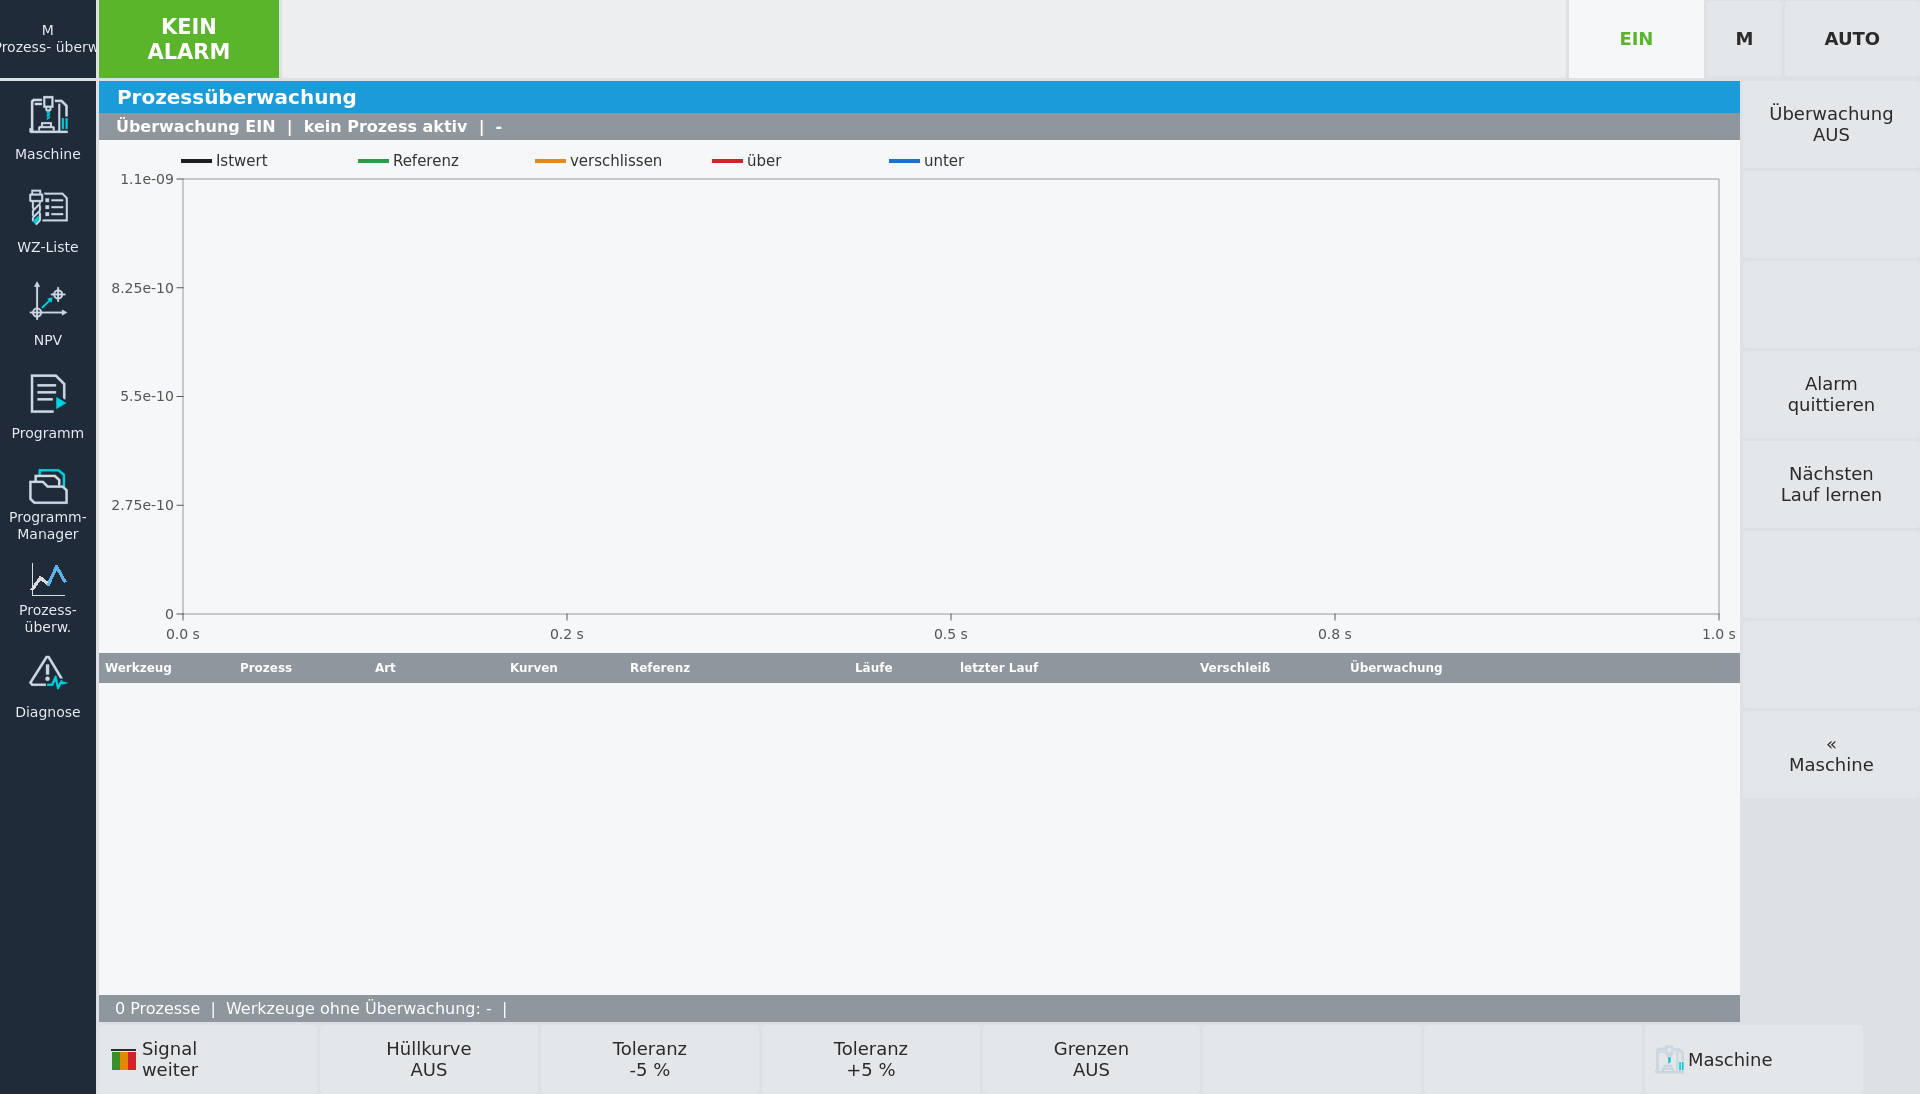 Process monitoring (mcwatch)
Tool management with magazines
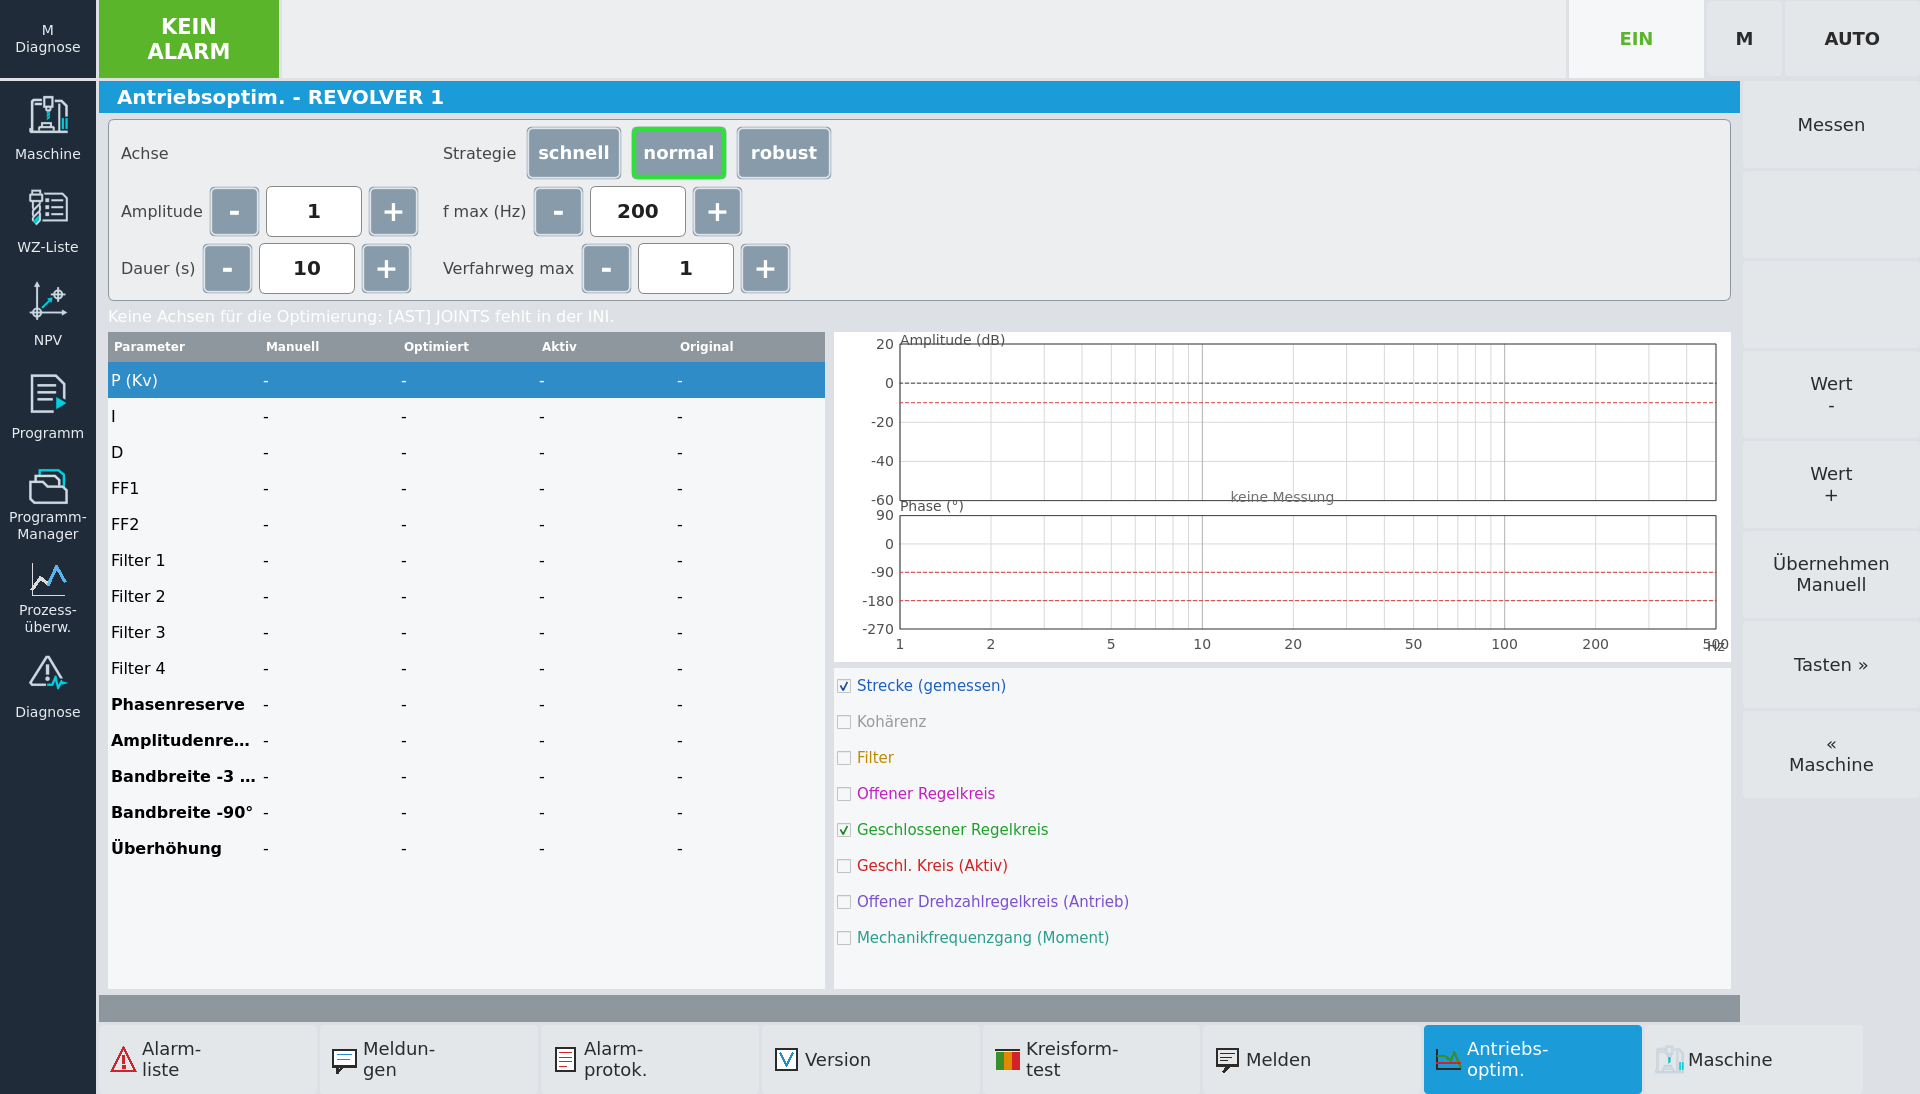 Auto Servo Tuning page
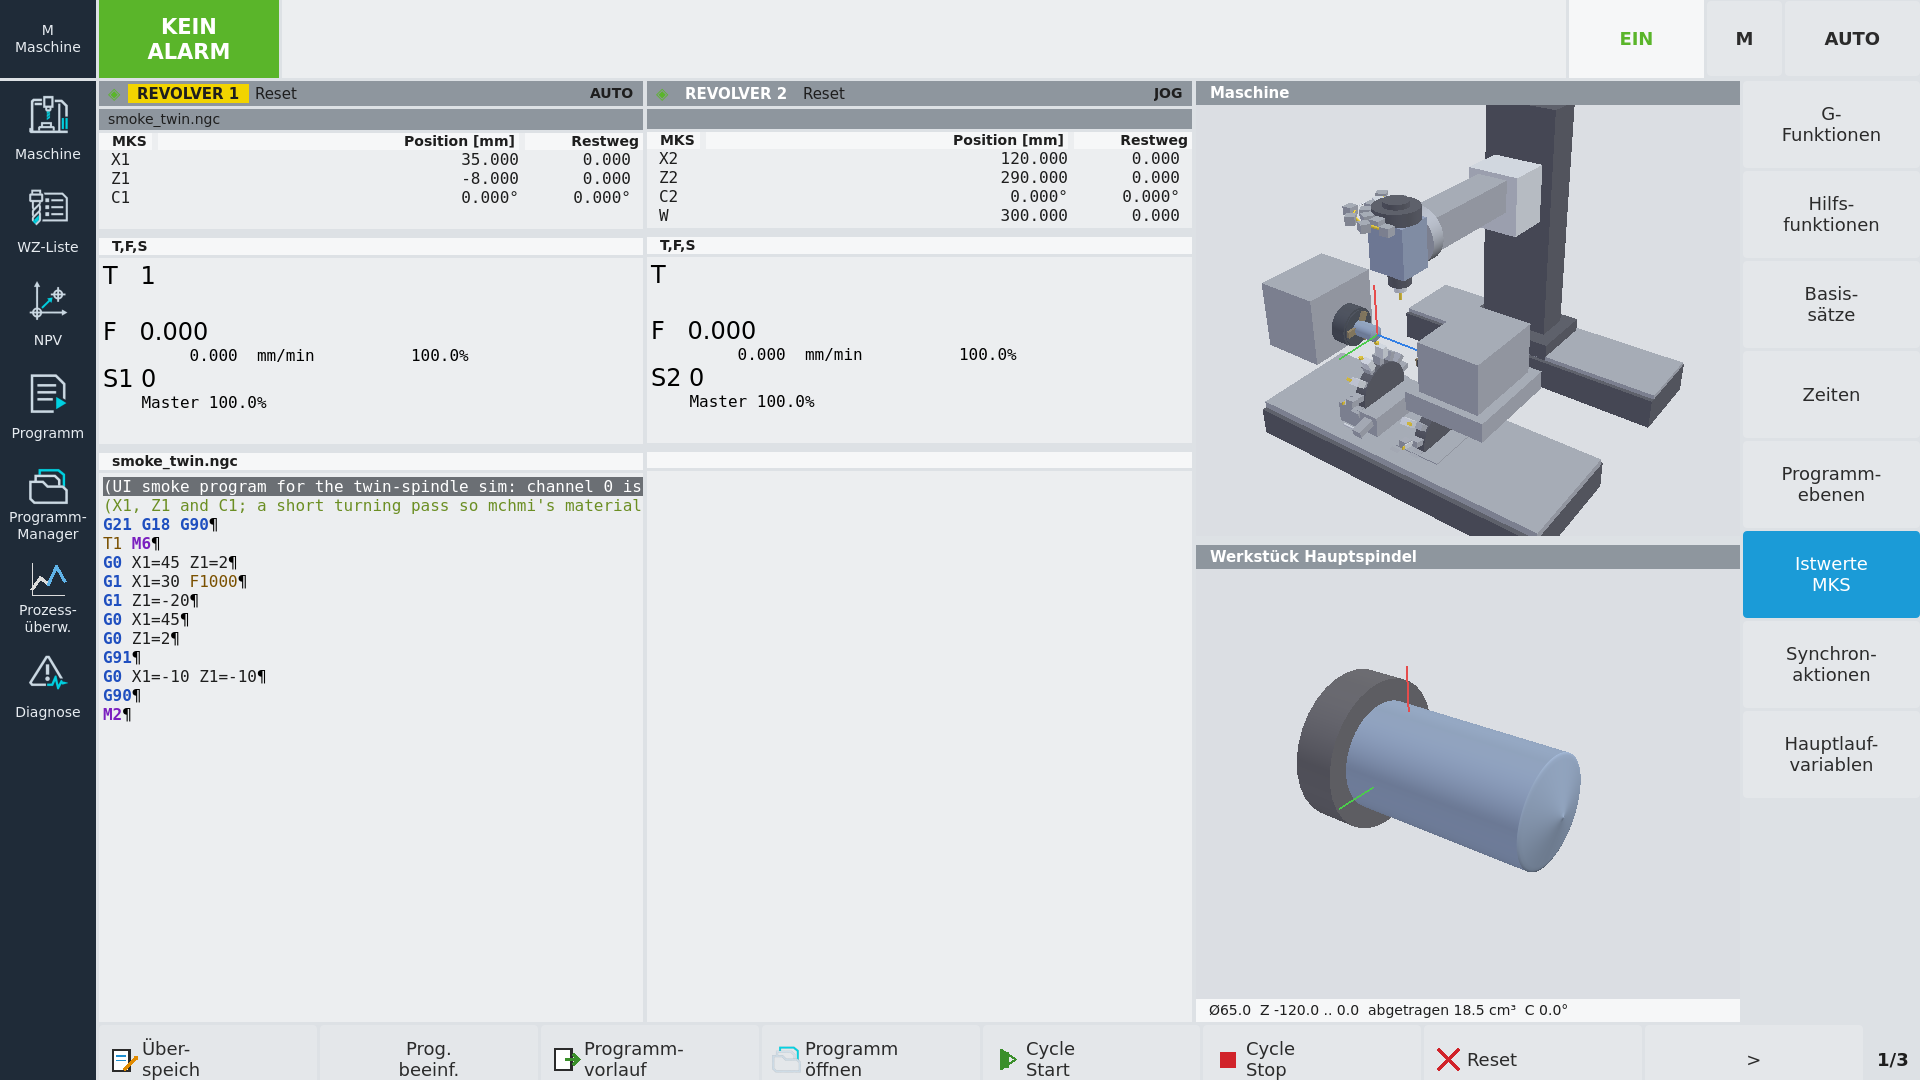 After the smoke program: the result
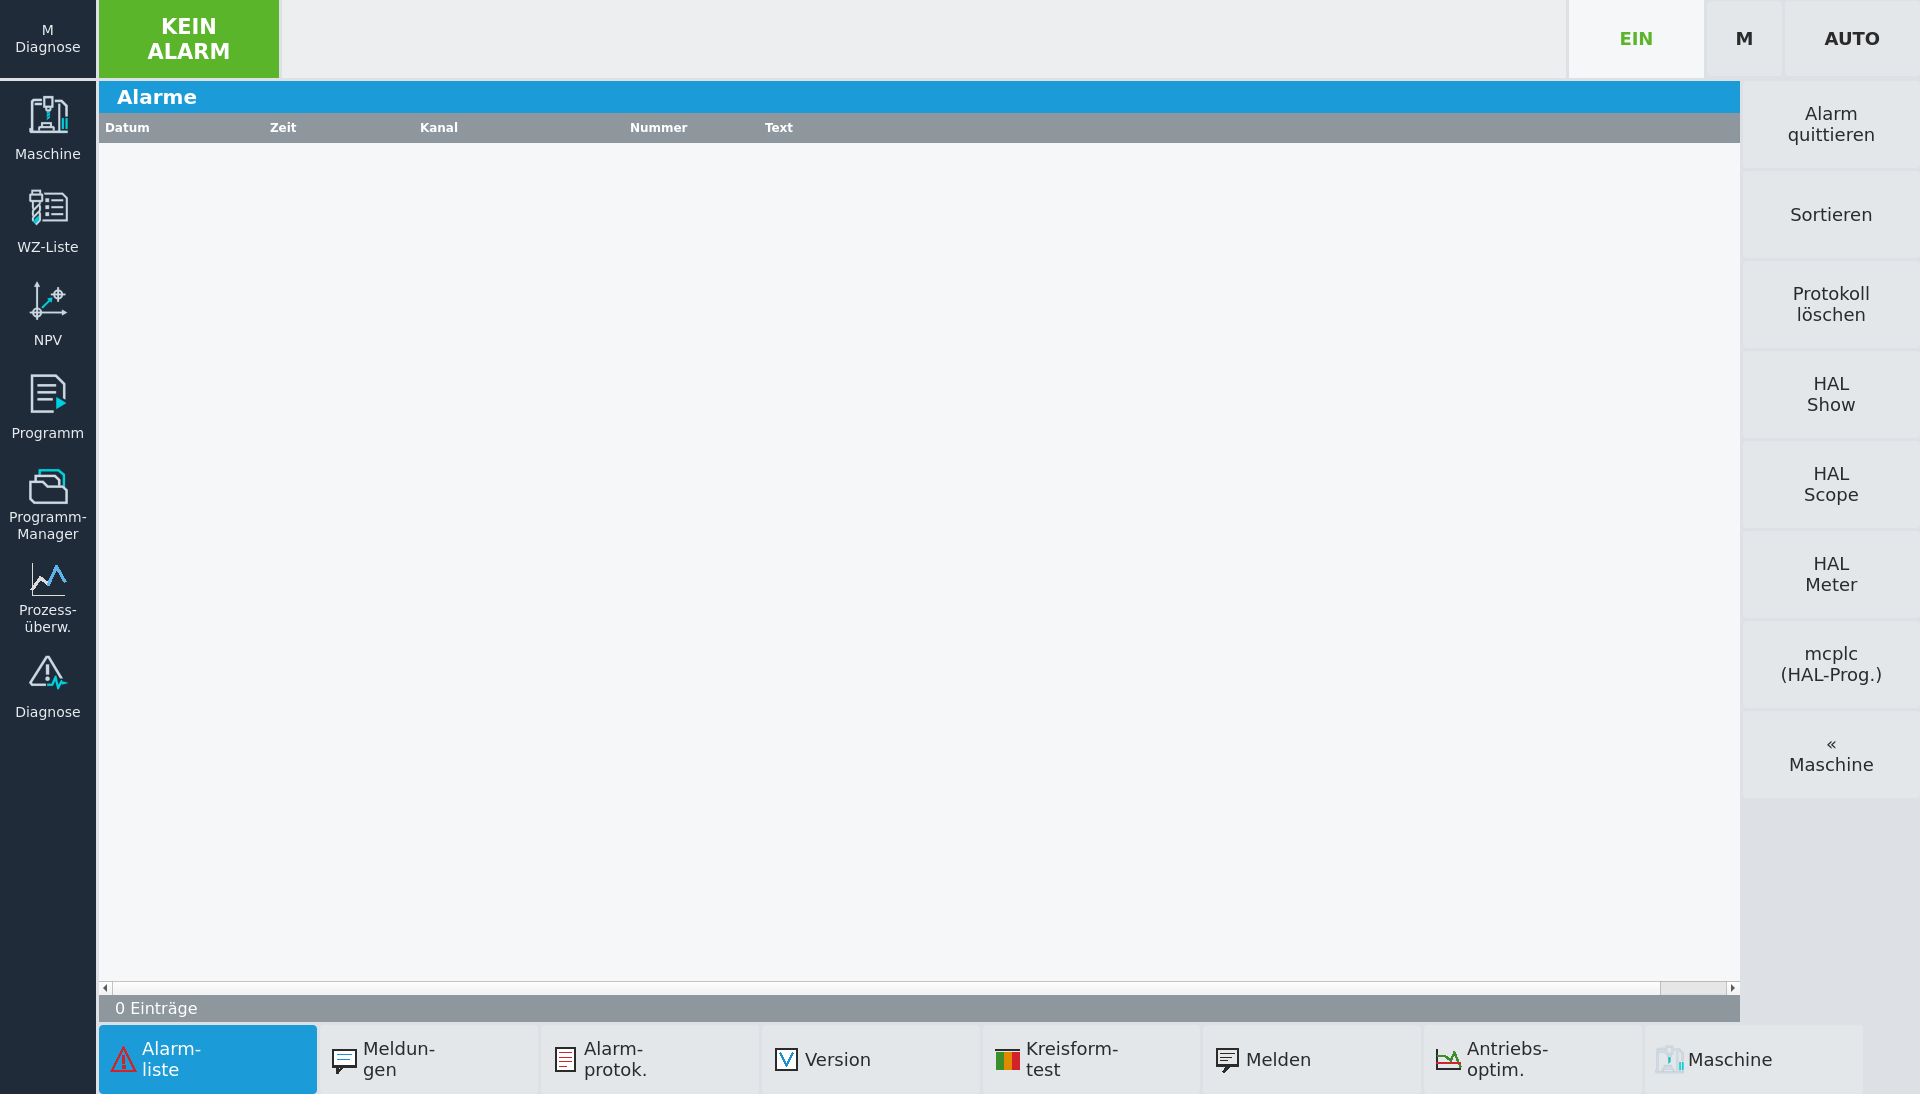 Diagnosis: alarms and log
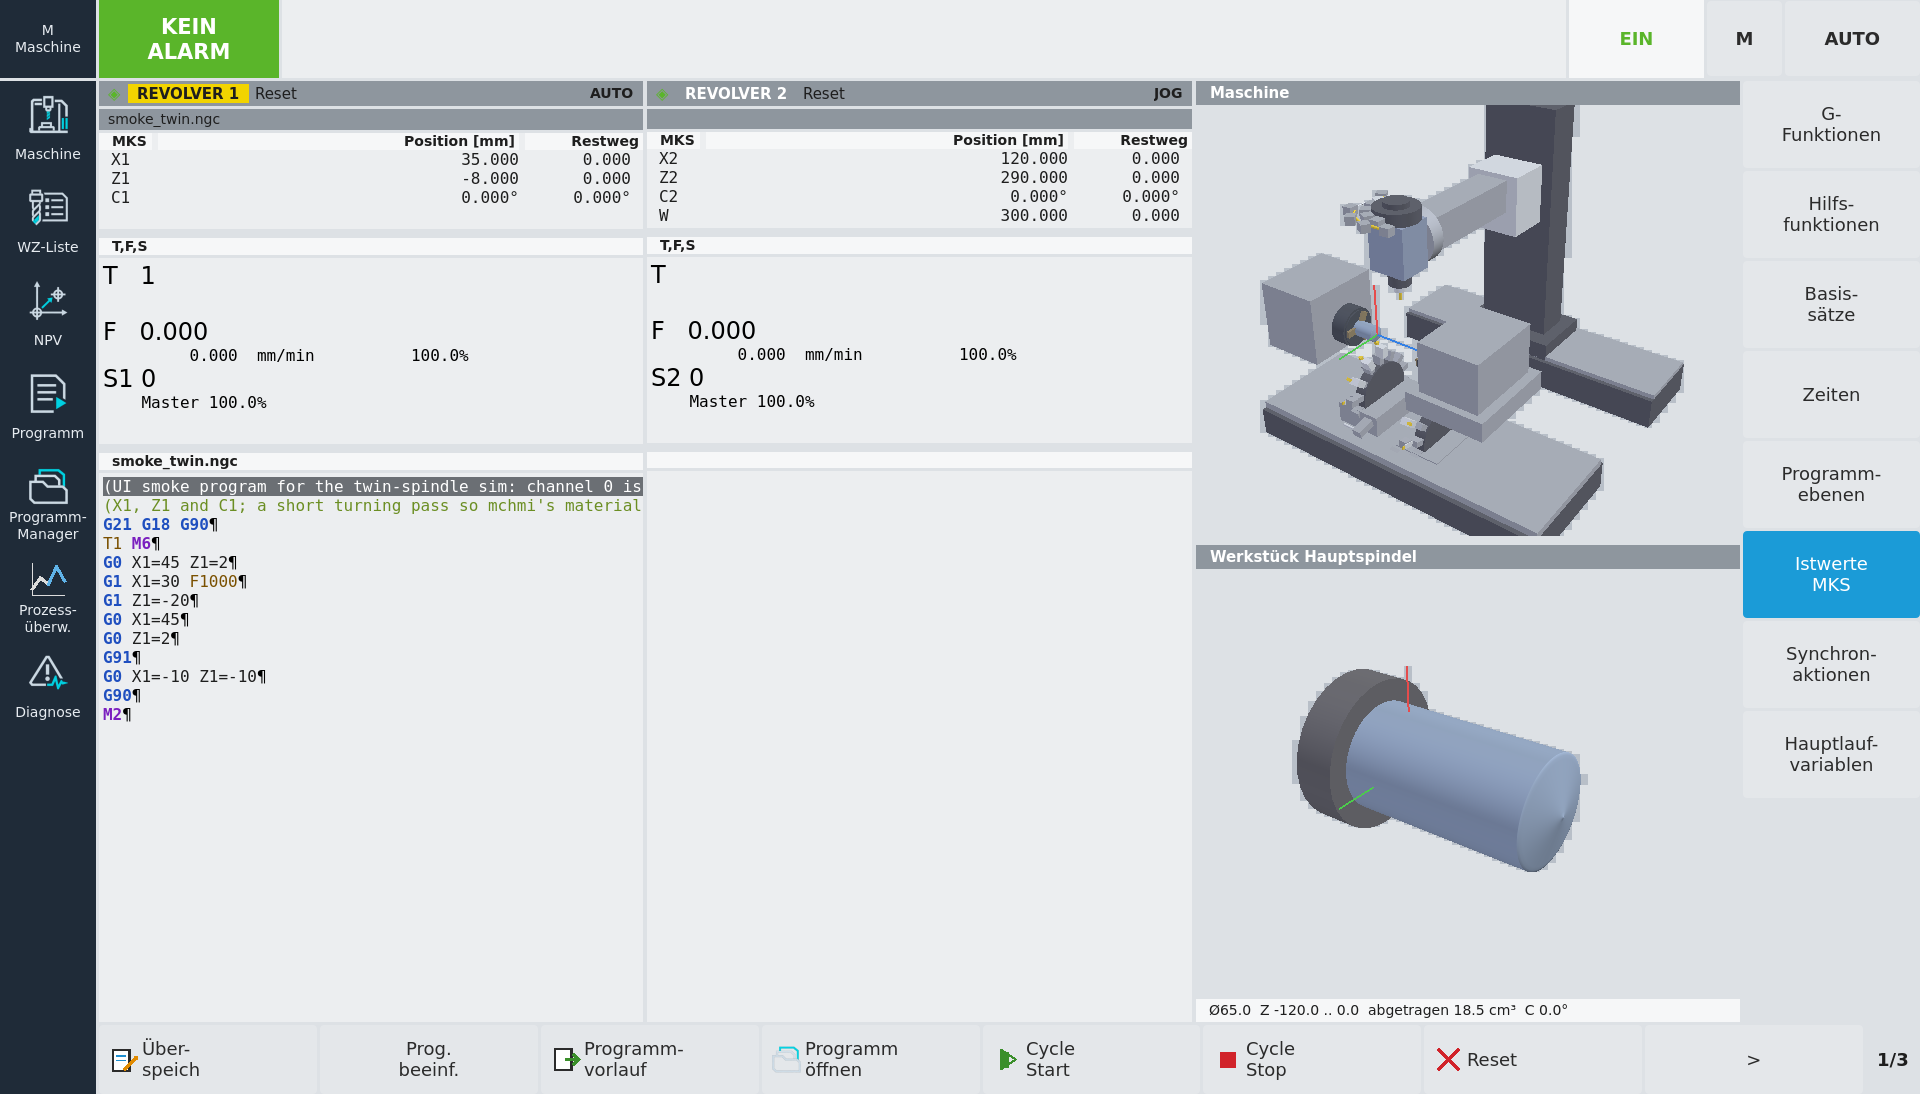 Machine area: channels, positions, program, 3D model
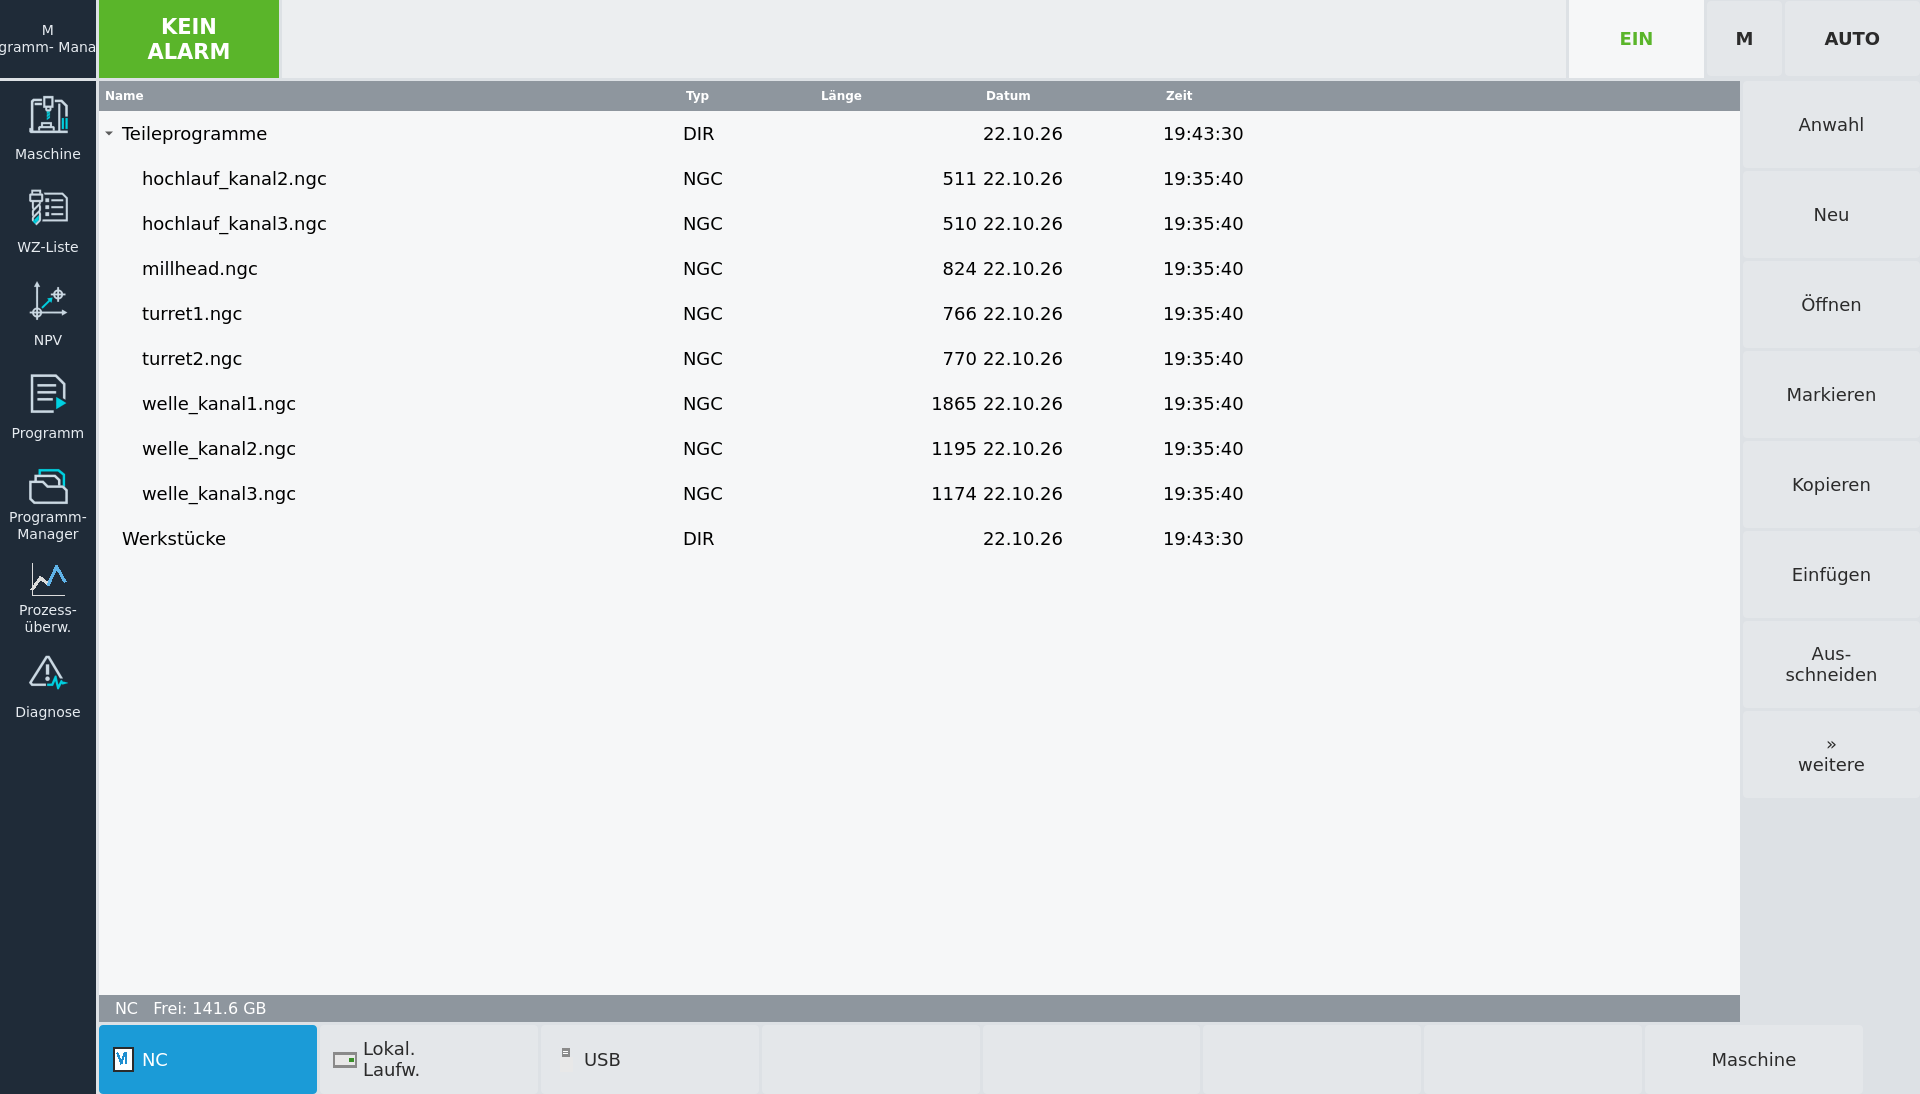 Program manager
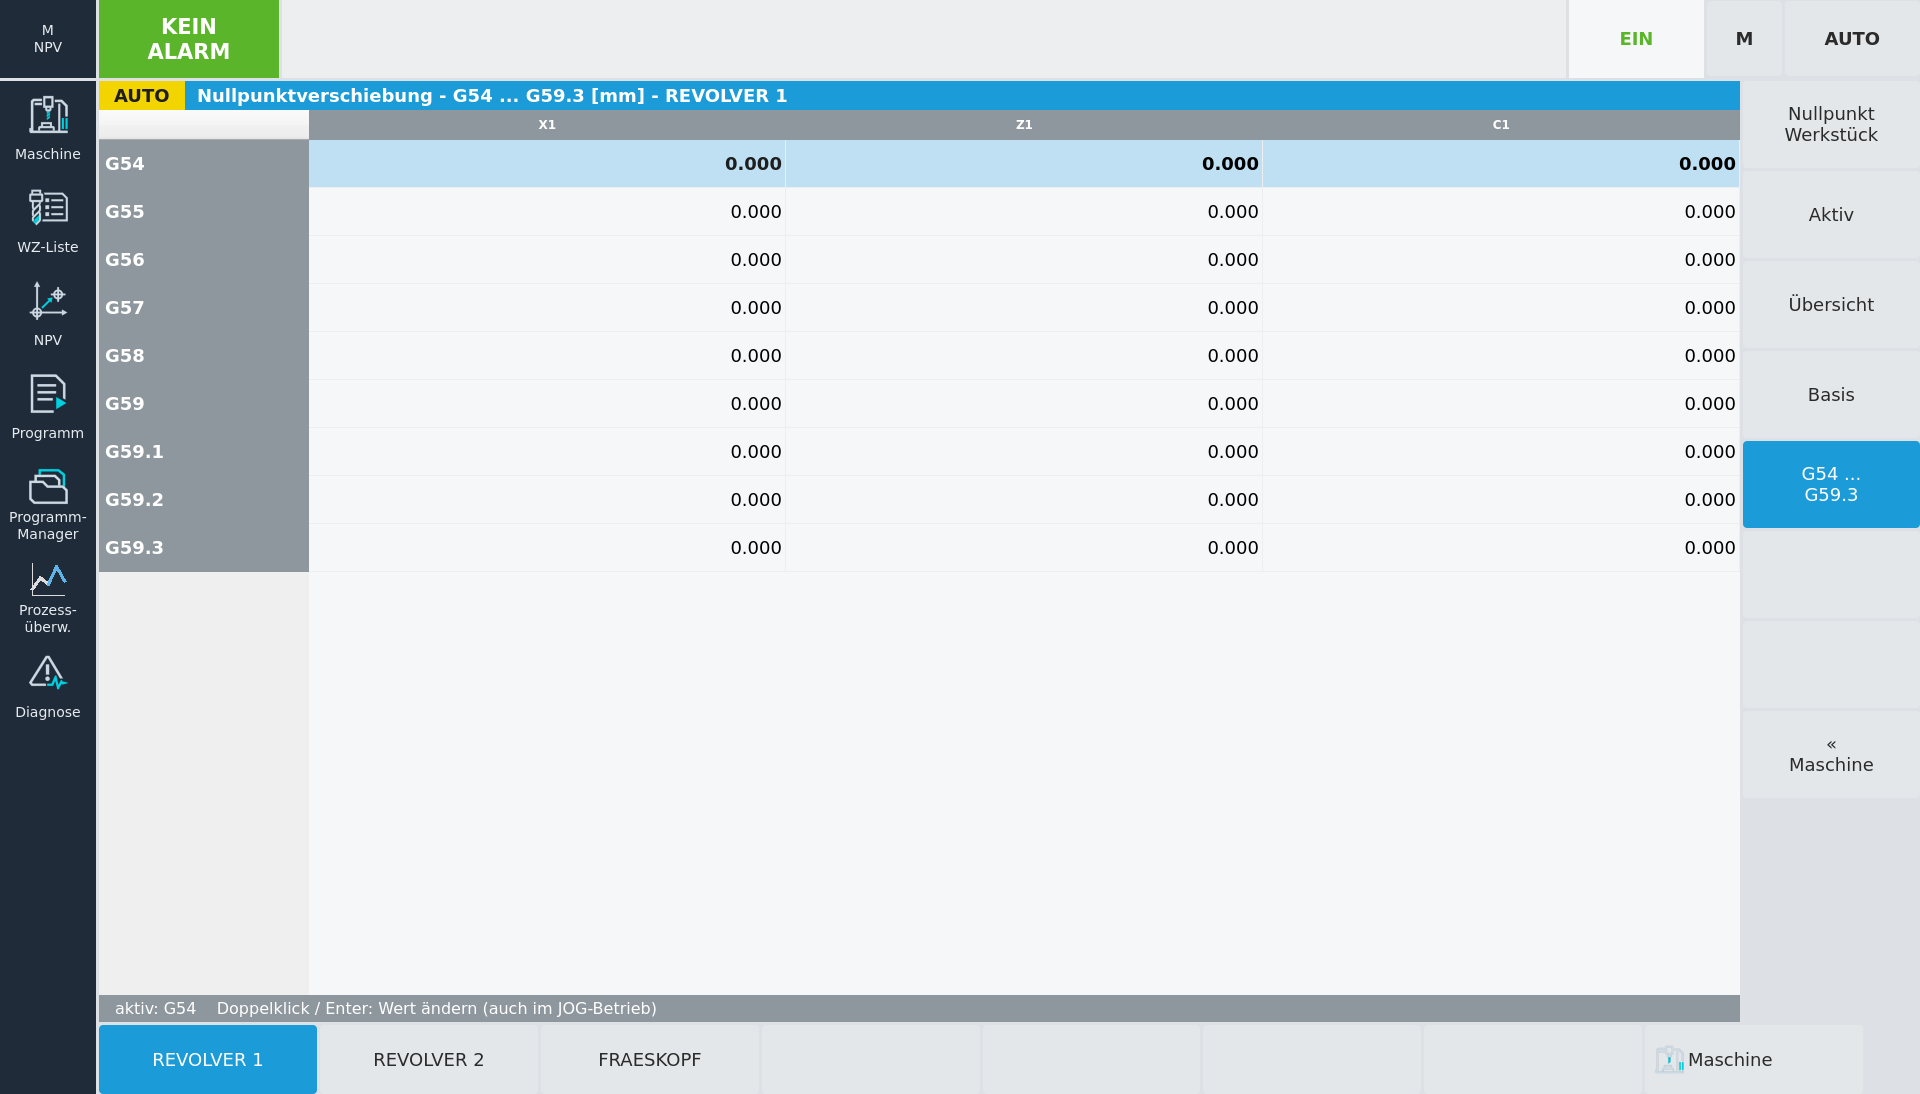 Work offsets
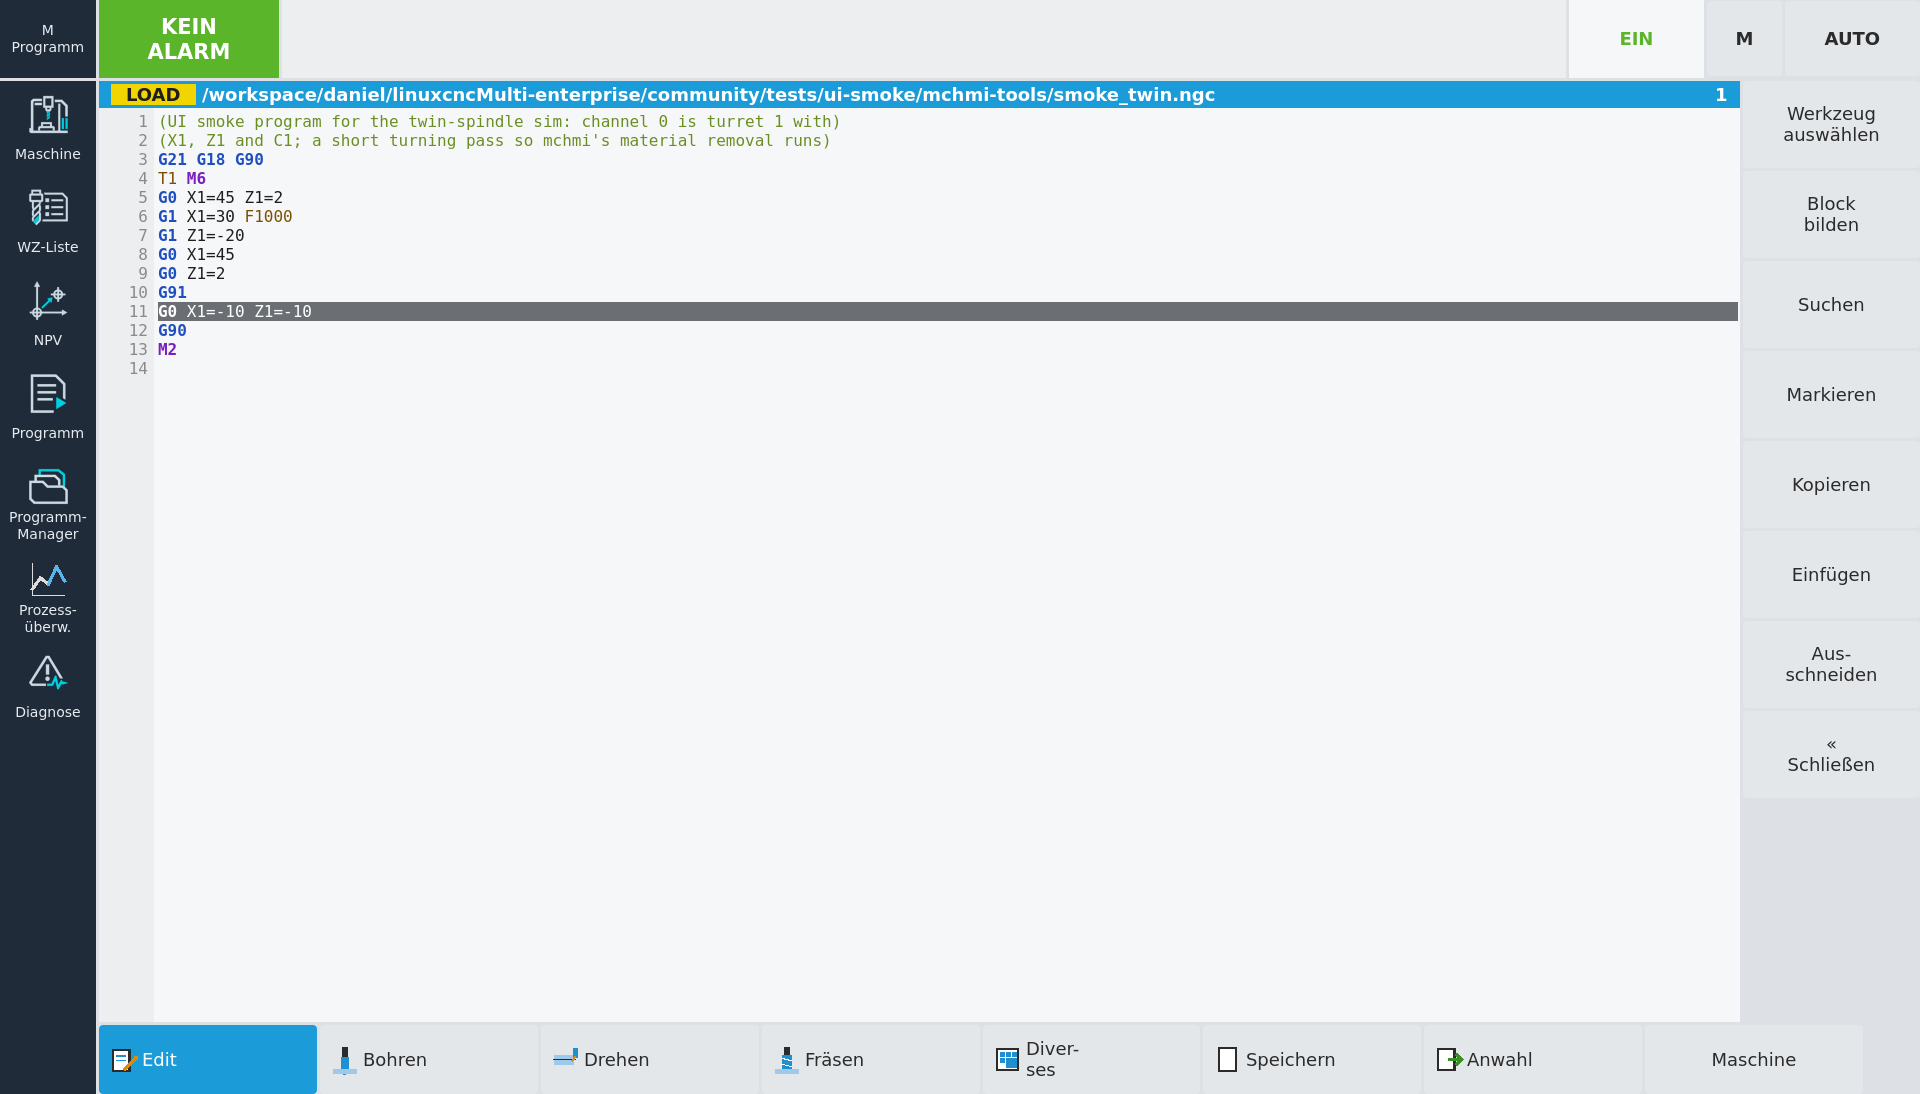 Program editor
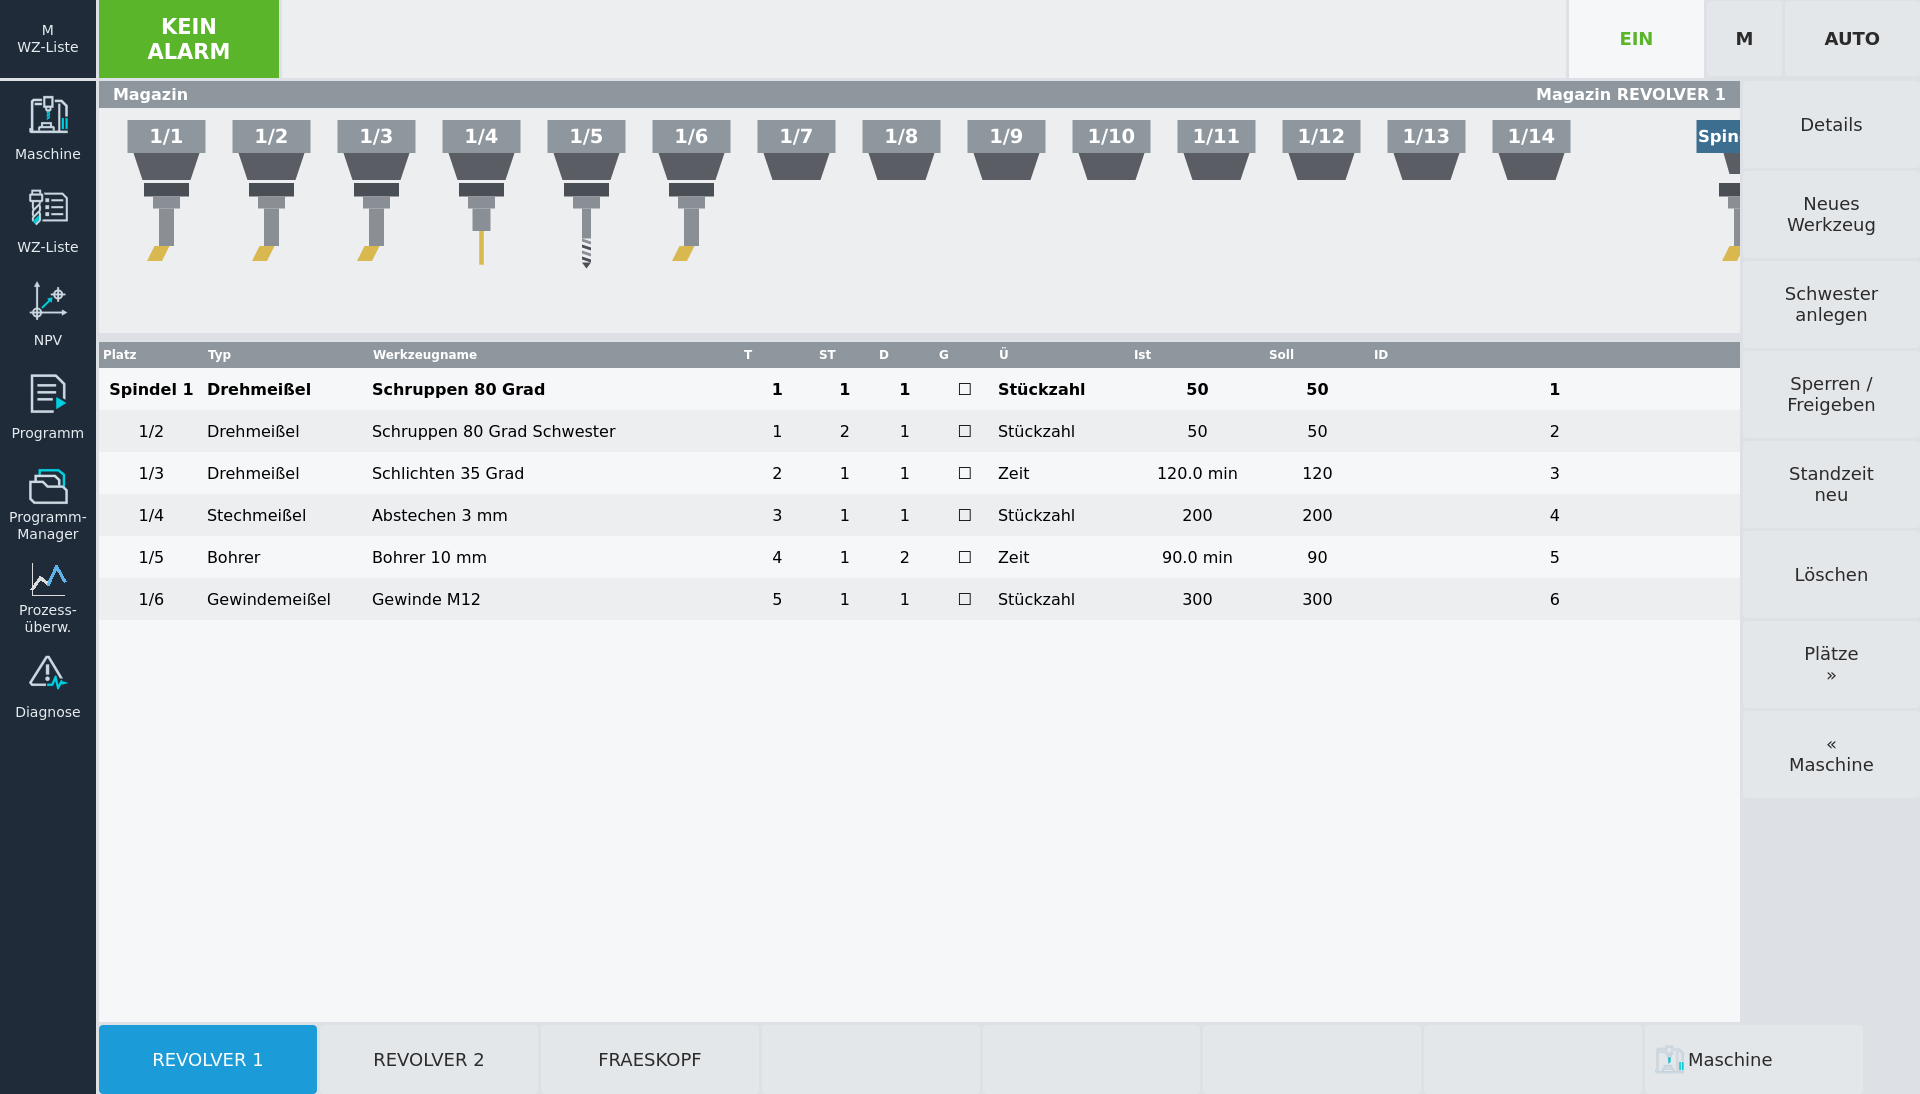 Tool list
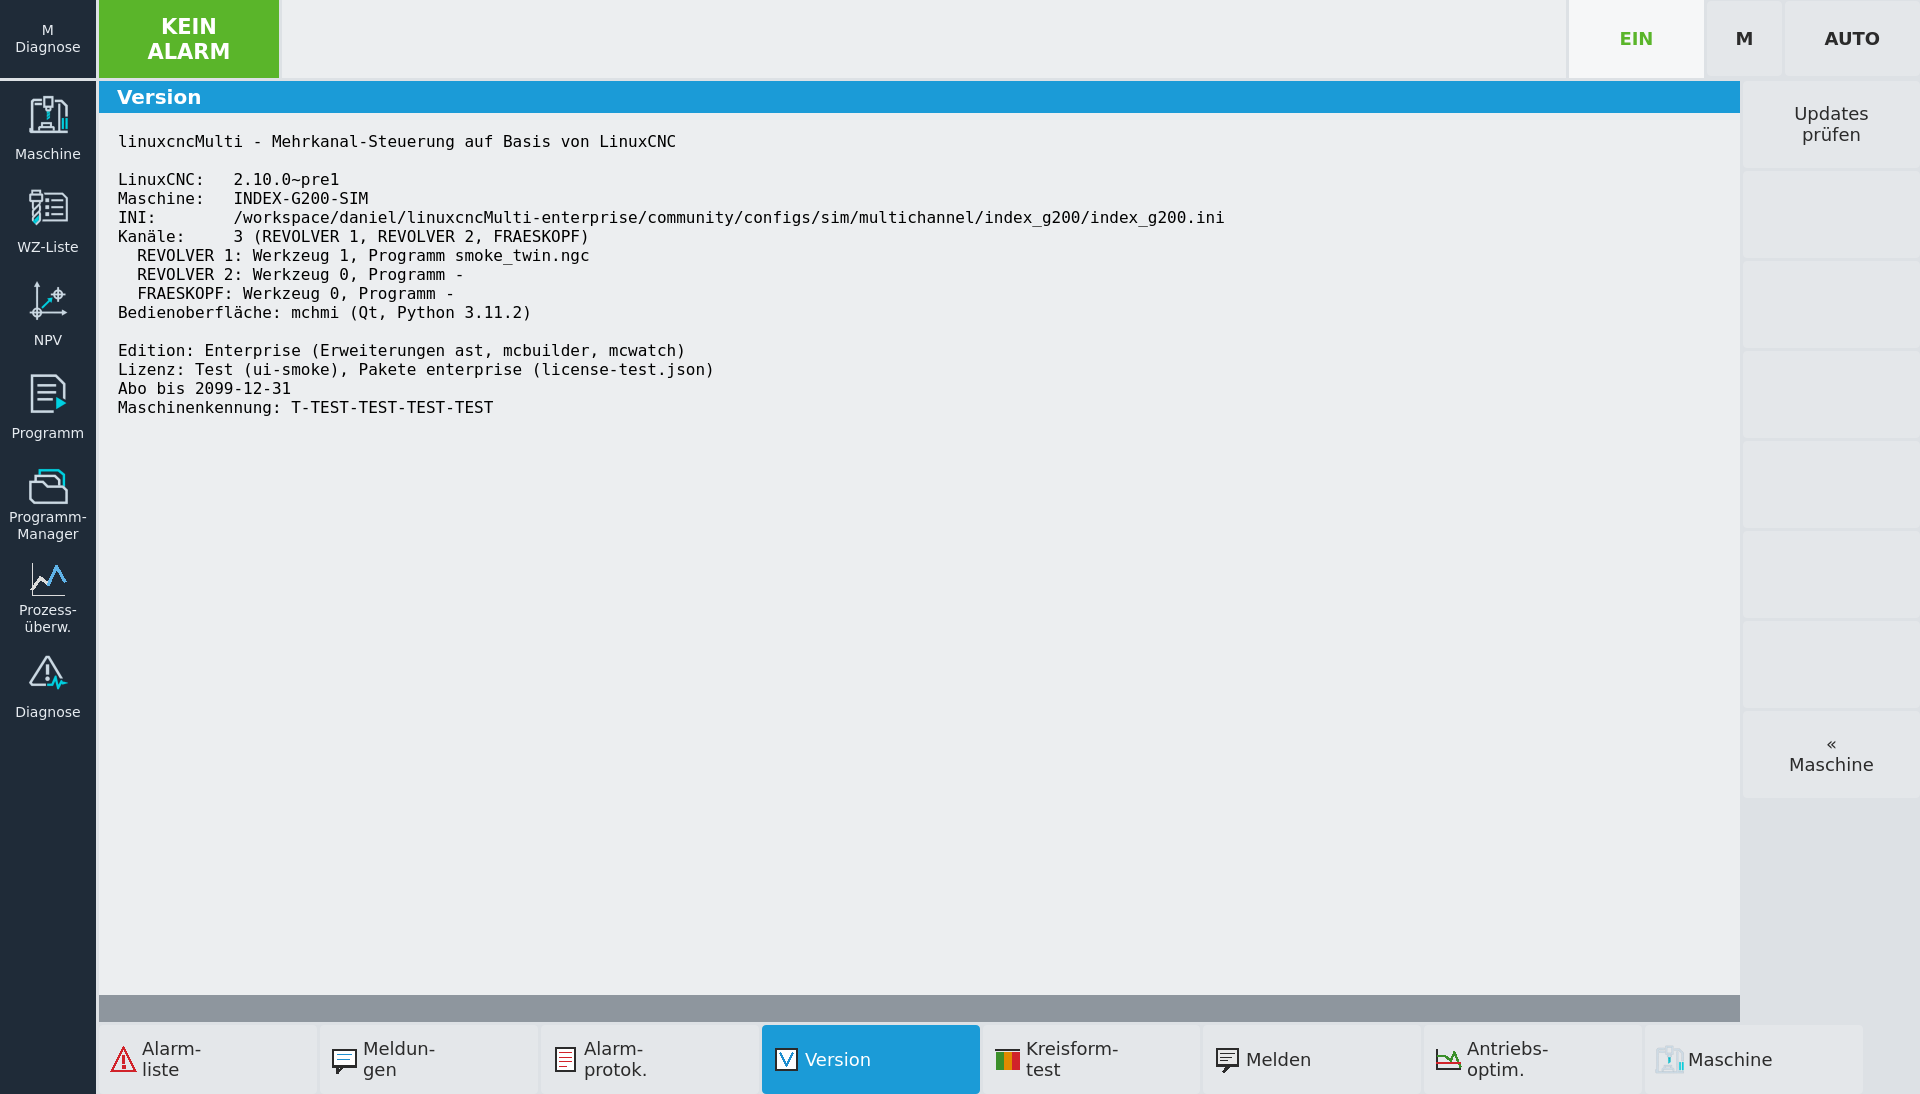 Version page: edition, licence, updates
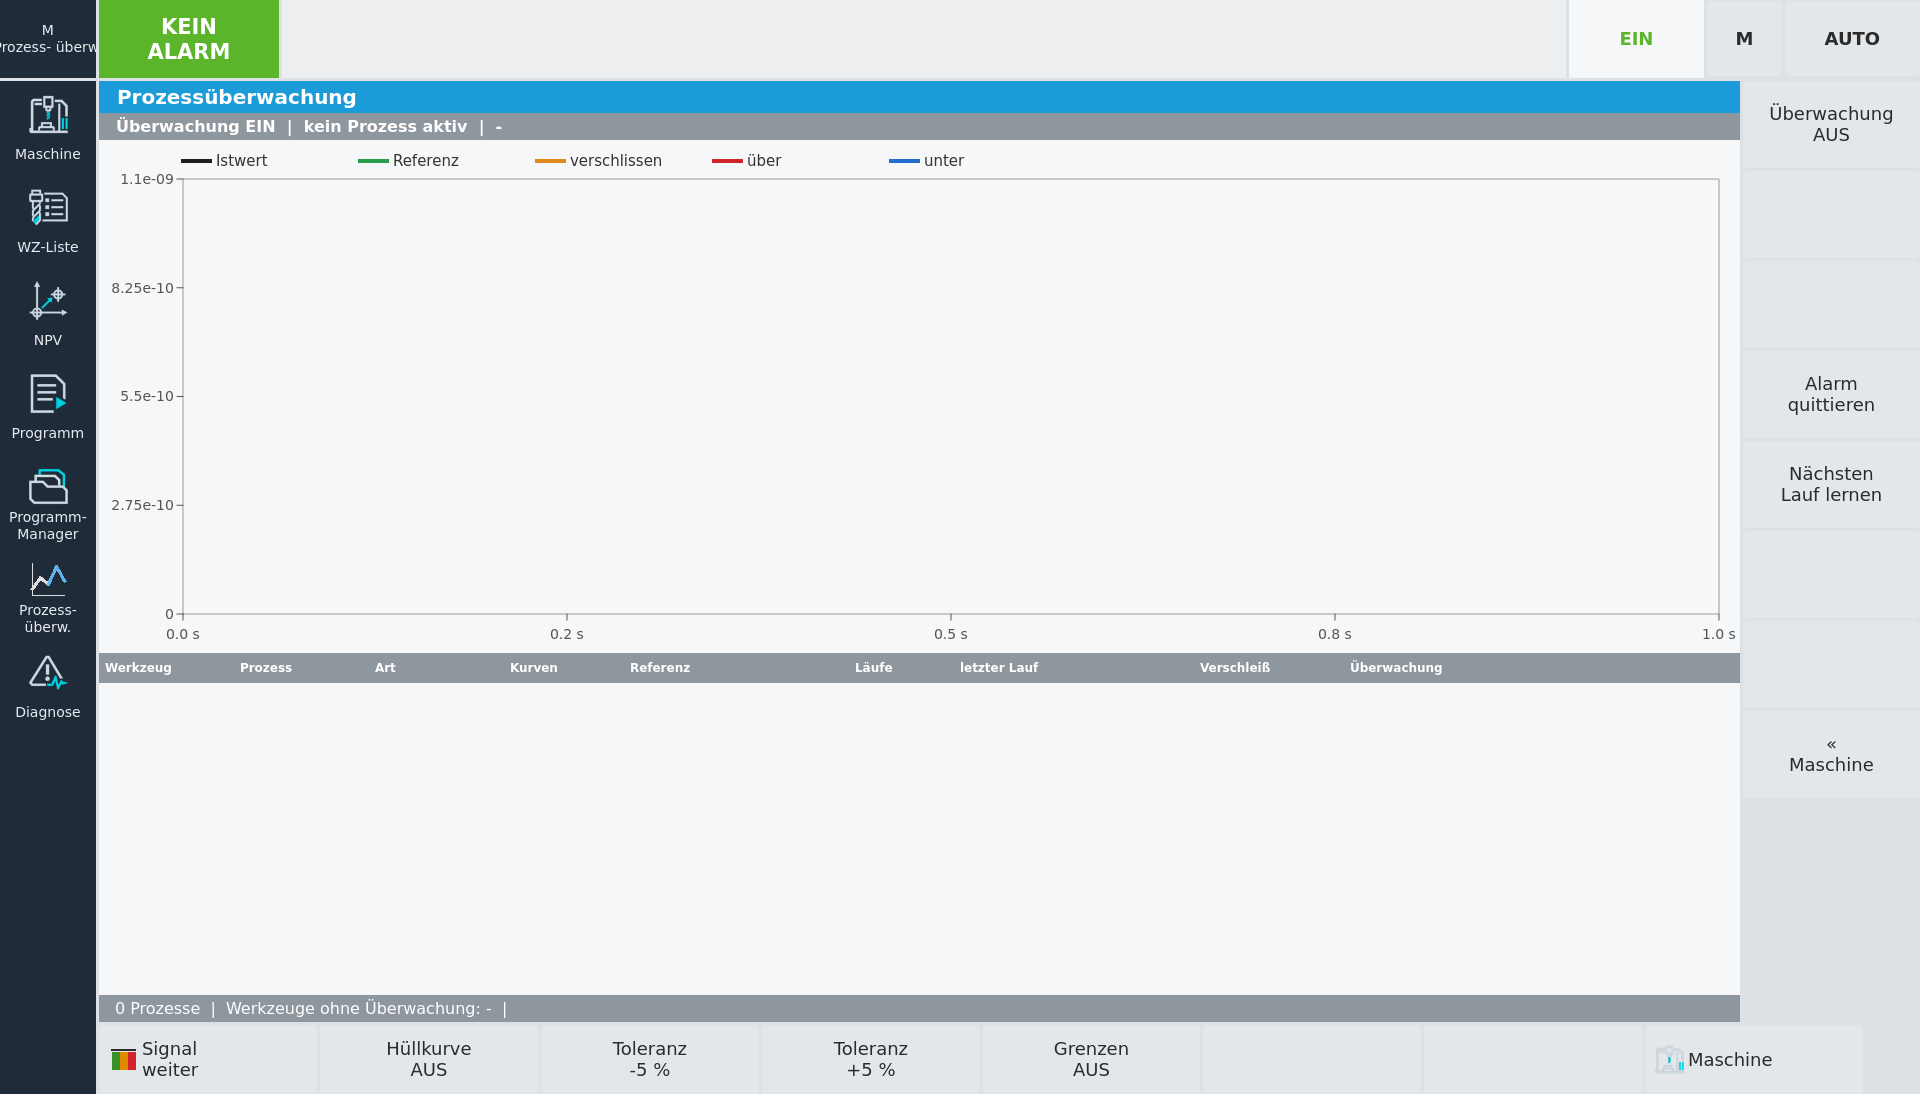 Process monitoring (mcwatch)